FRC Team 971 - Spartan Robotics.
Four years on FRC Team 971 doing a little bit of everything. Autonomous software, power electronics and PCBs, firmware, gearboxes, machining, driving, and match strategy.
The build
For four years I spent more time at the lab than I did at school. When I joined the team I was told I would pick one discipline, mechanical, electrical, or software. I always thought that was BS. Why not every single one?
So I did all of them. I wrote the autonomous. I designed most of our power electronics and coprocessor PCBs, wrote the firmware that ran on them, and built the superstructure collision avoidance software so the robot could not tear itself apart. I designed gearboxes and mechanical linkages. I wired the robot and manufactured parts on the lathe and mill, and CAMed parts for the CNC routers. I drove the robot in matches and worked out our match strategy. I wanted to do everything because I was interested in everything.
My trick was asking the mentors the dumb questions early, actually listening, and then coming back with the hard questions once I had some idea of what was going on. Eventually I learned to love all of it.
Some favorites from those years. We wrote the first 3 piece plus balance autonomous in the world. I designed a suite of 11 connector boards that basically ended our unplugged-sensor problem, and other teams started buying them from us at competitions. And when we could not trust the published field layout, I threw 4 Raspberry Pis and 4 cameras in a box and mapped every AprilTag on the field myself.
Evidence
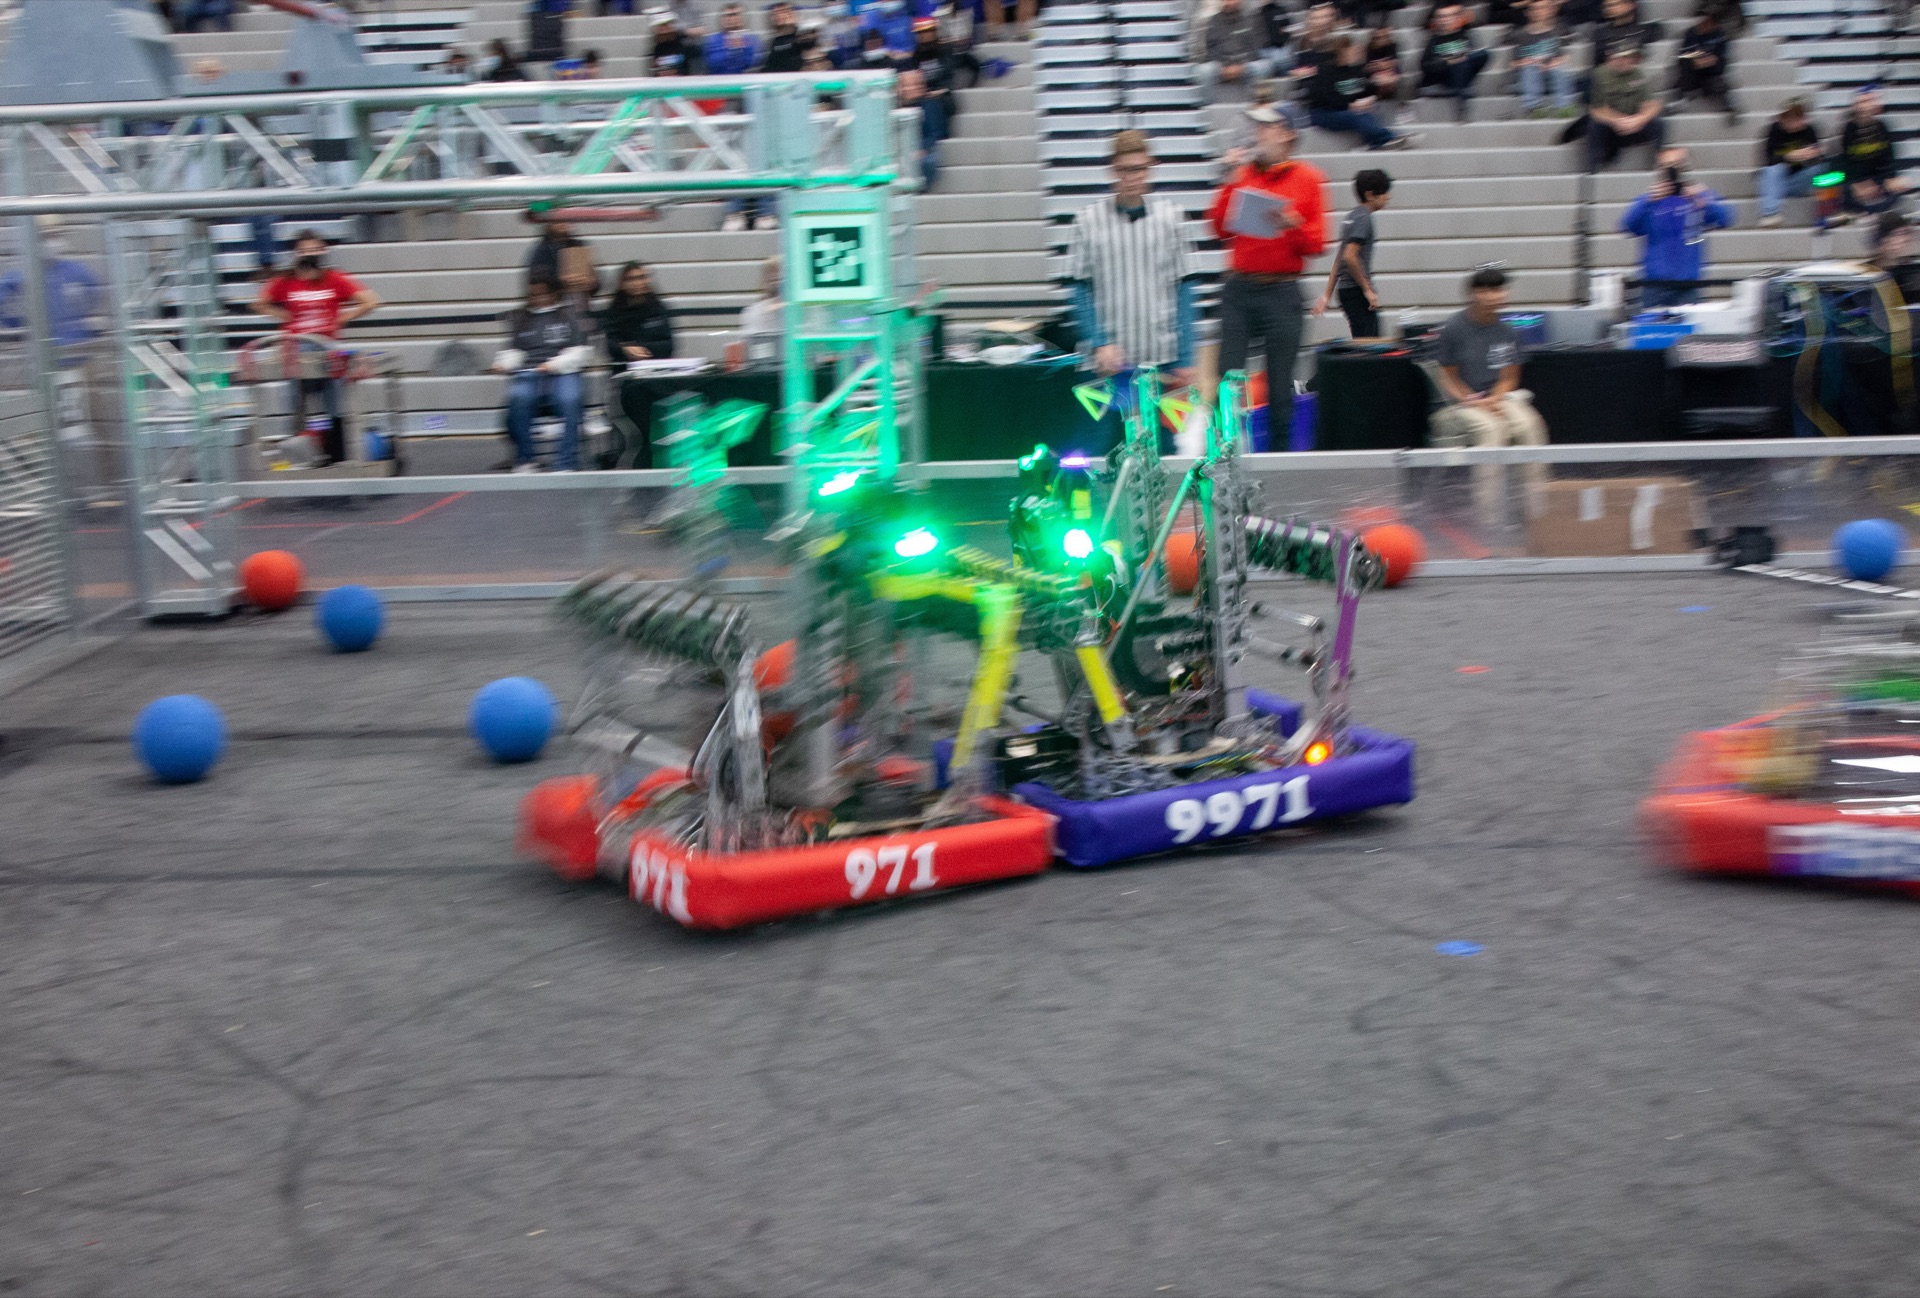
Two of our robots smashing into each other mid-match, motion blur and all.
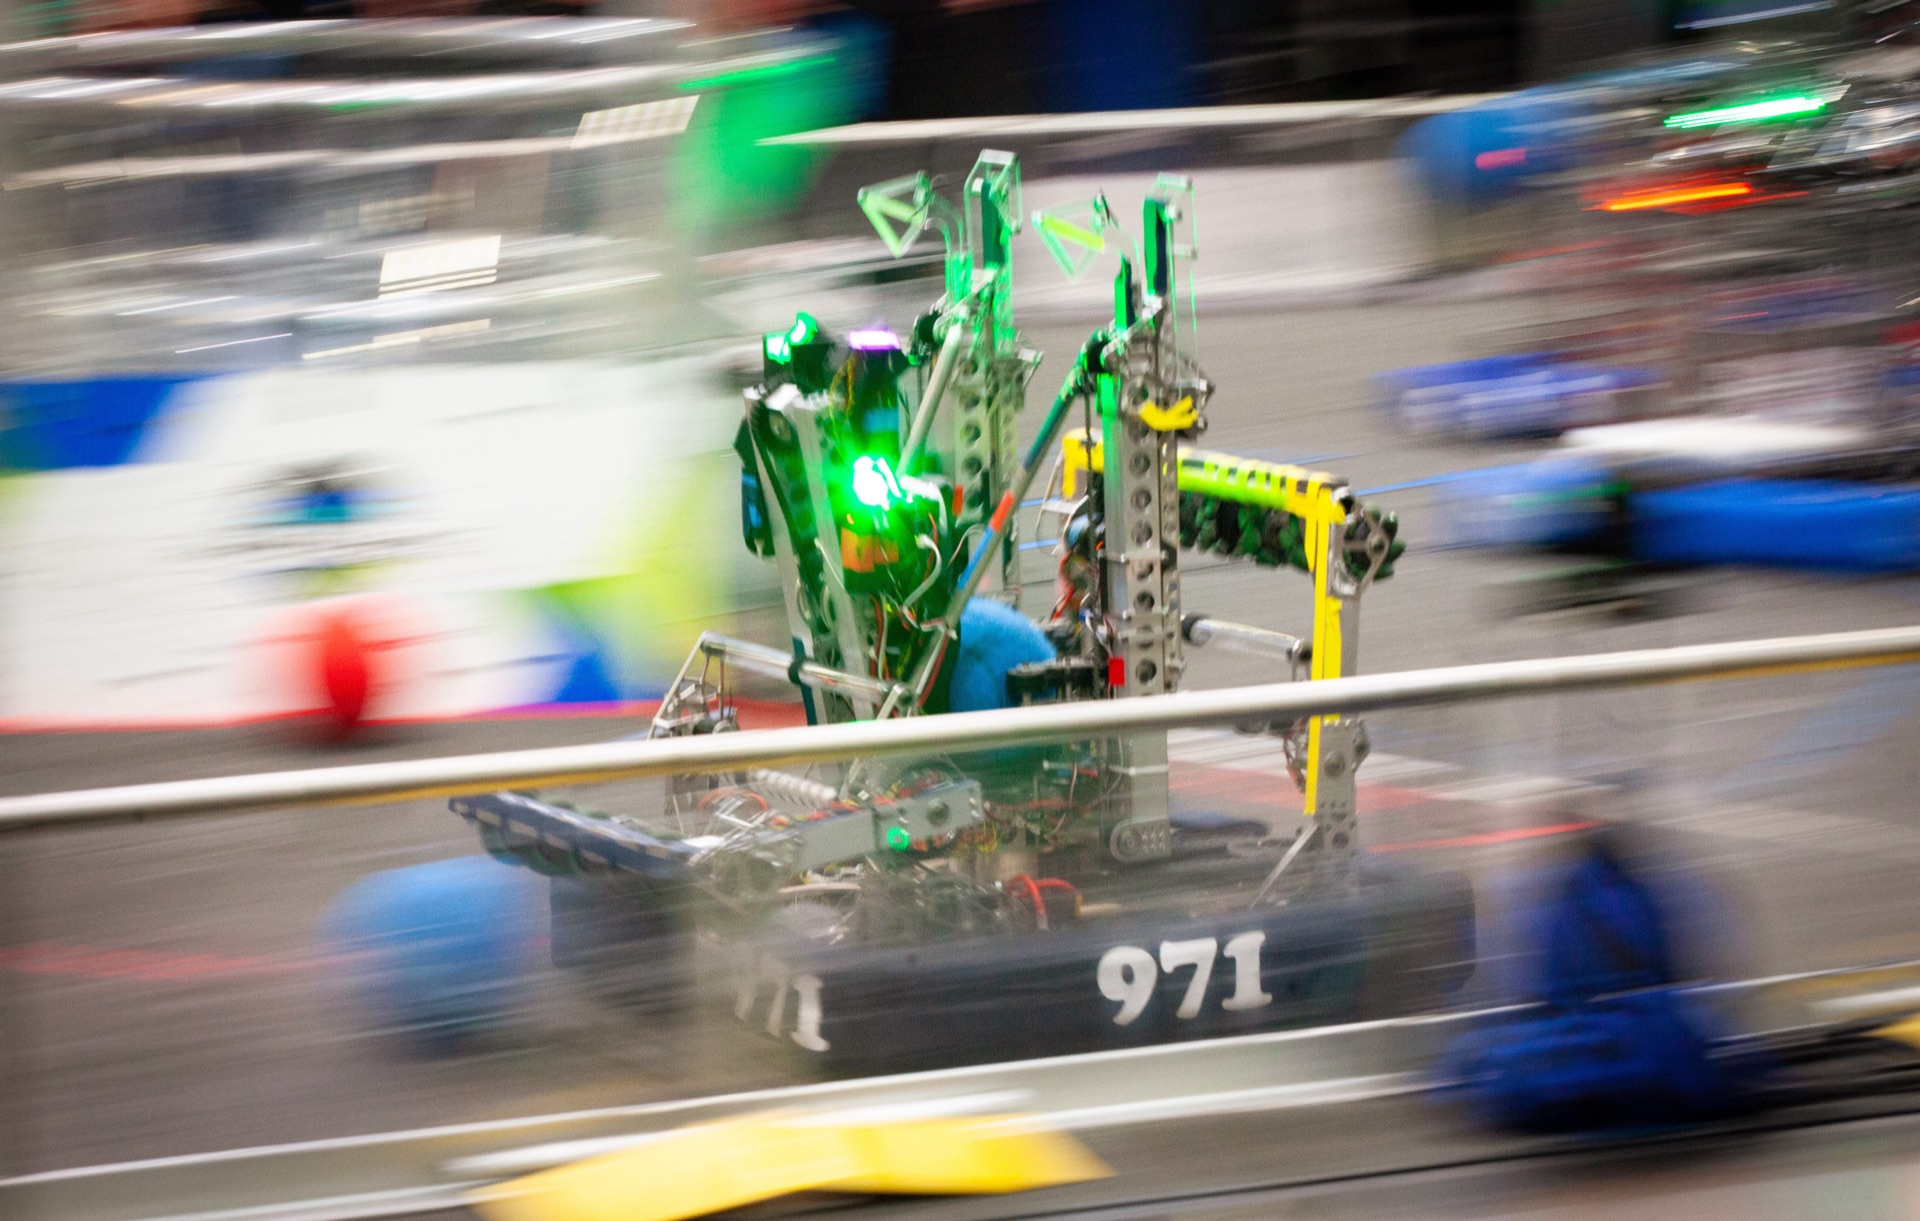
Full sprint across the field with the intake down.
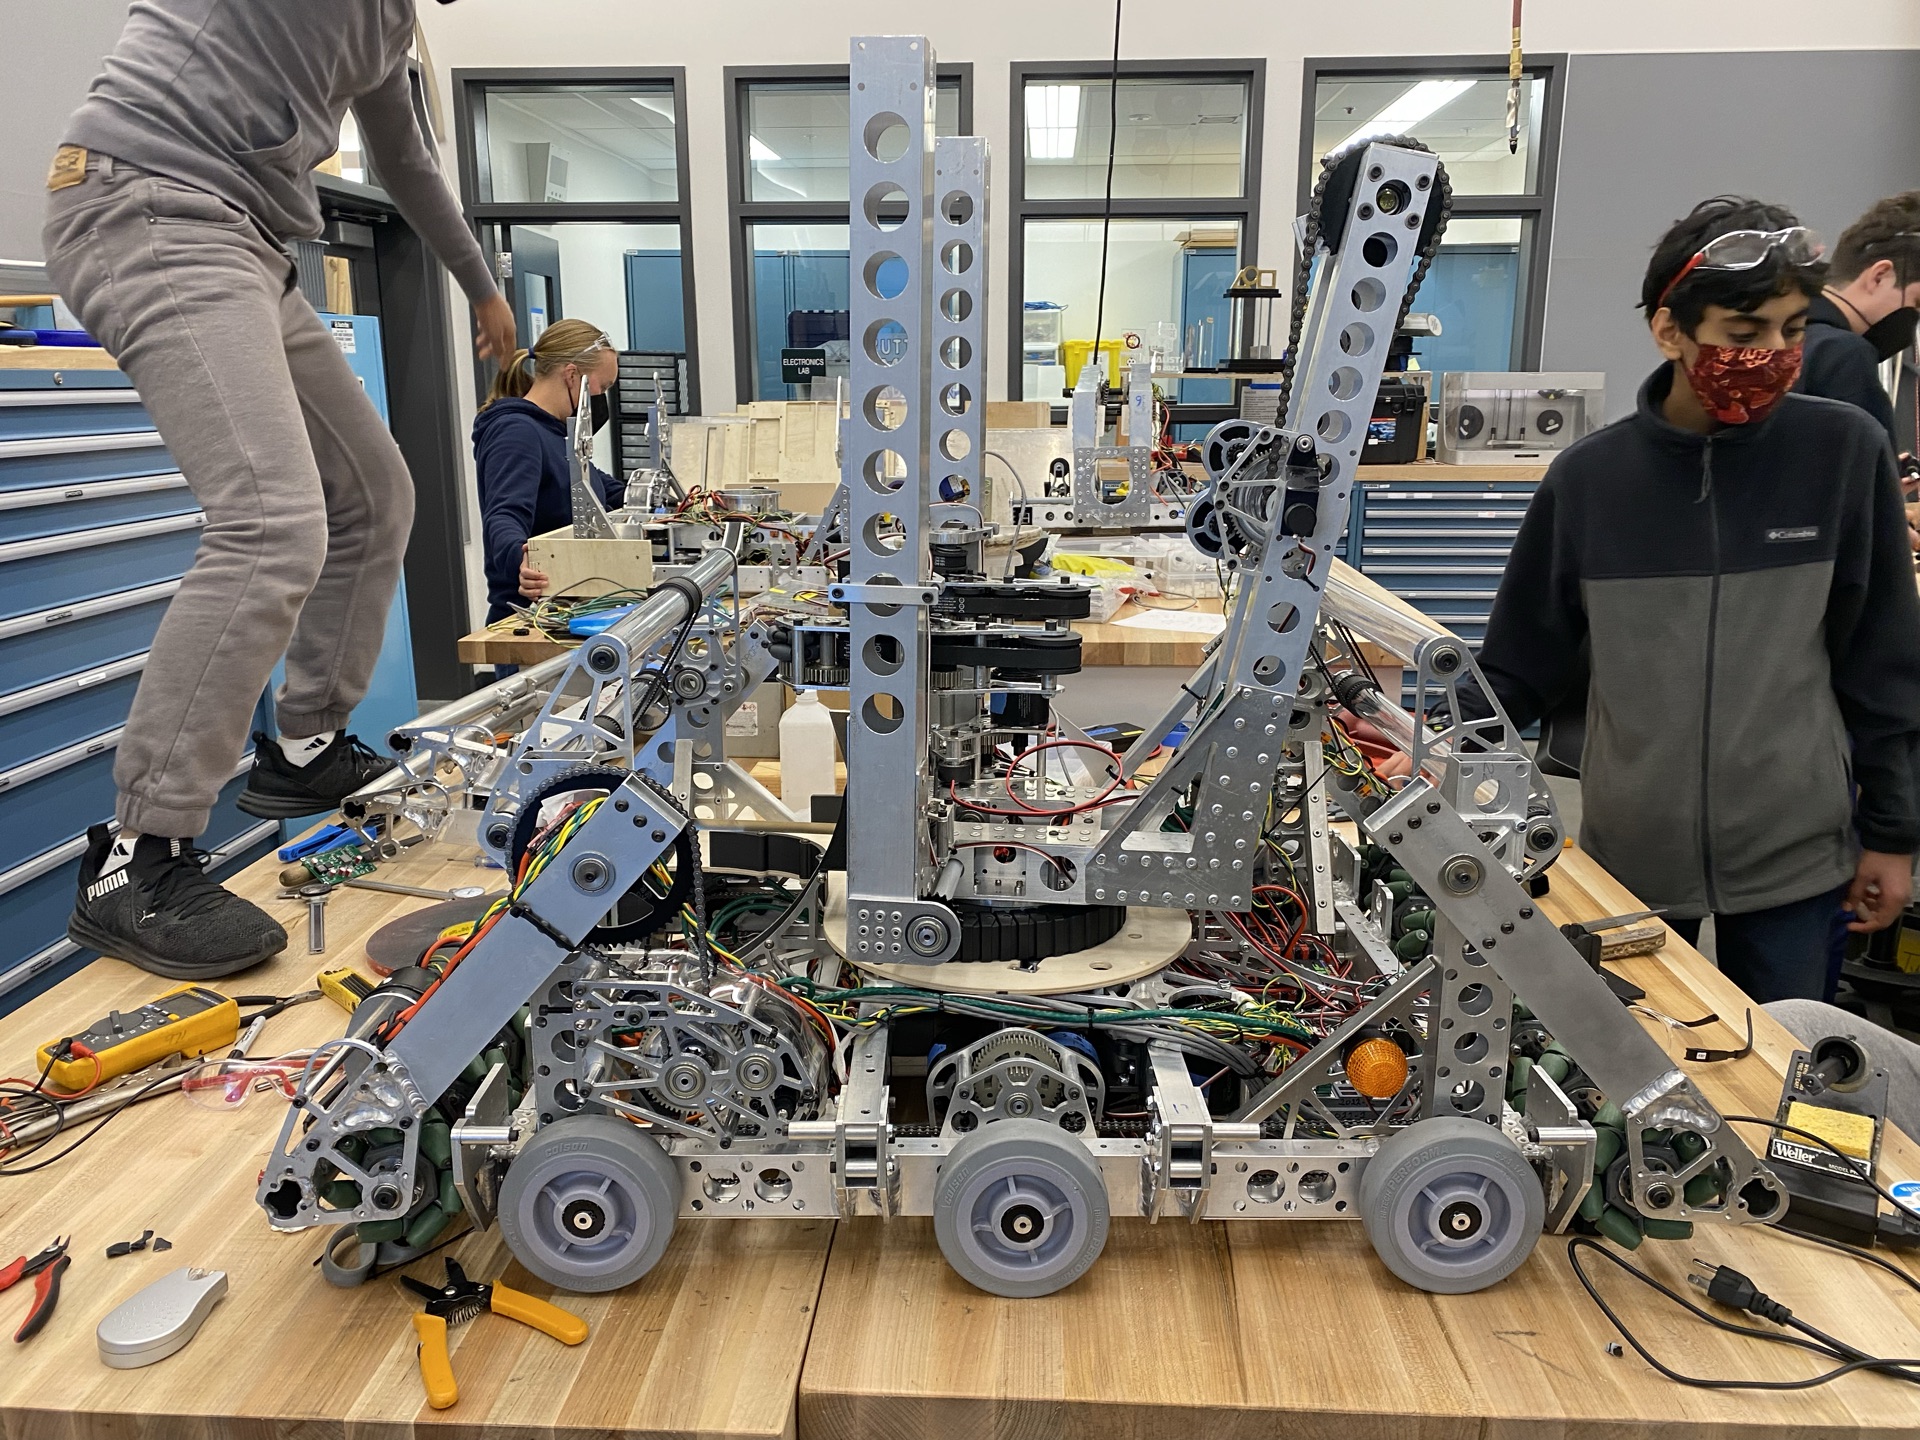
The 2022 robot half assembled on the shop table.
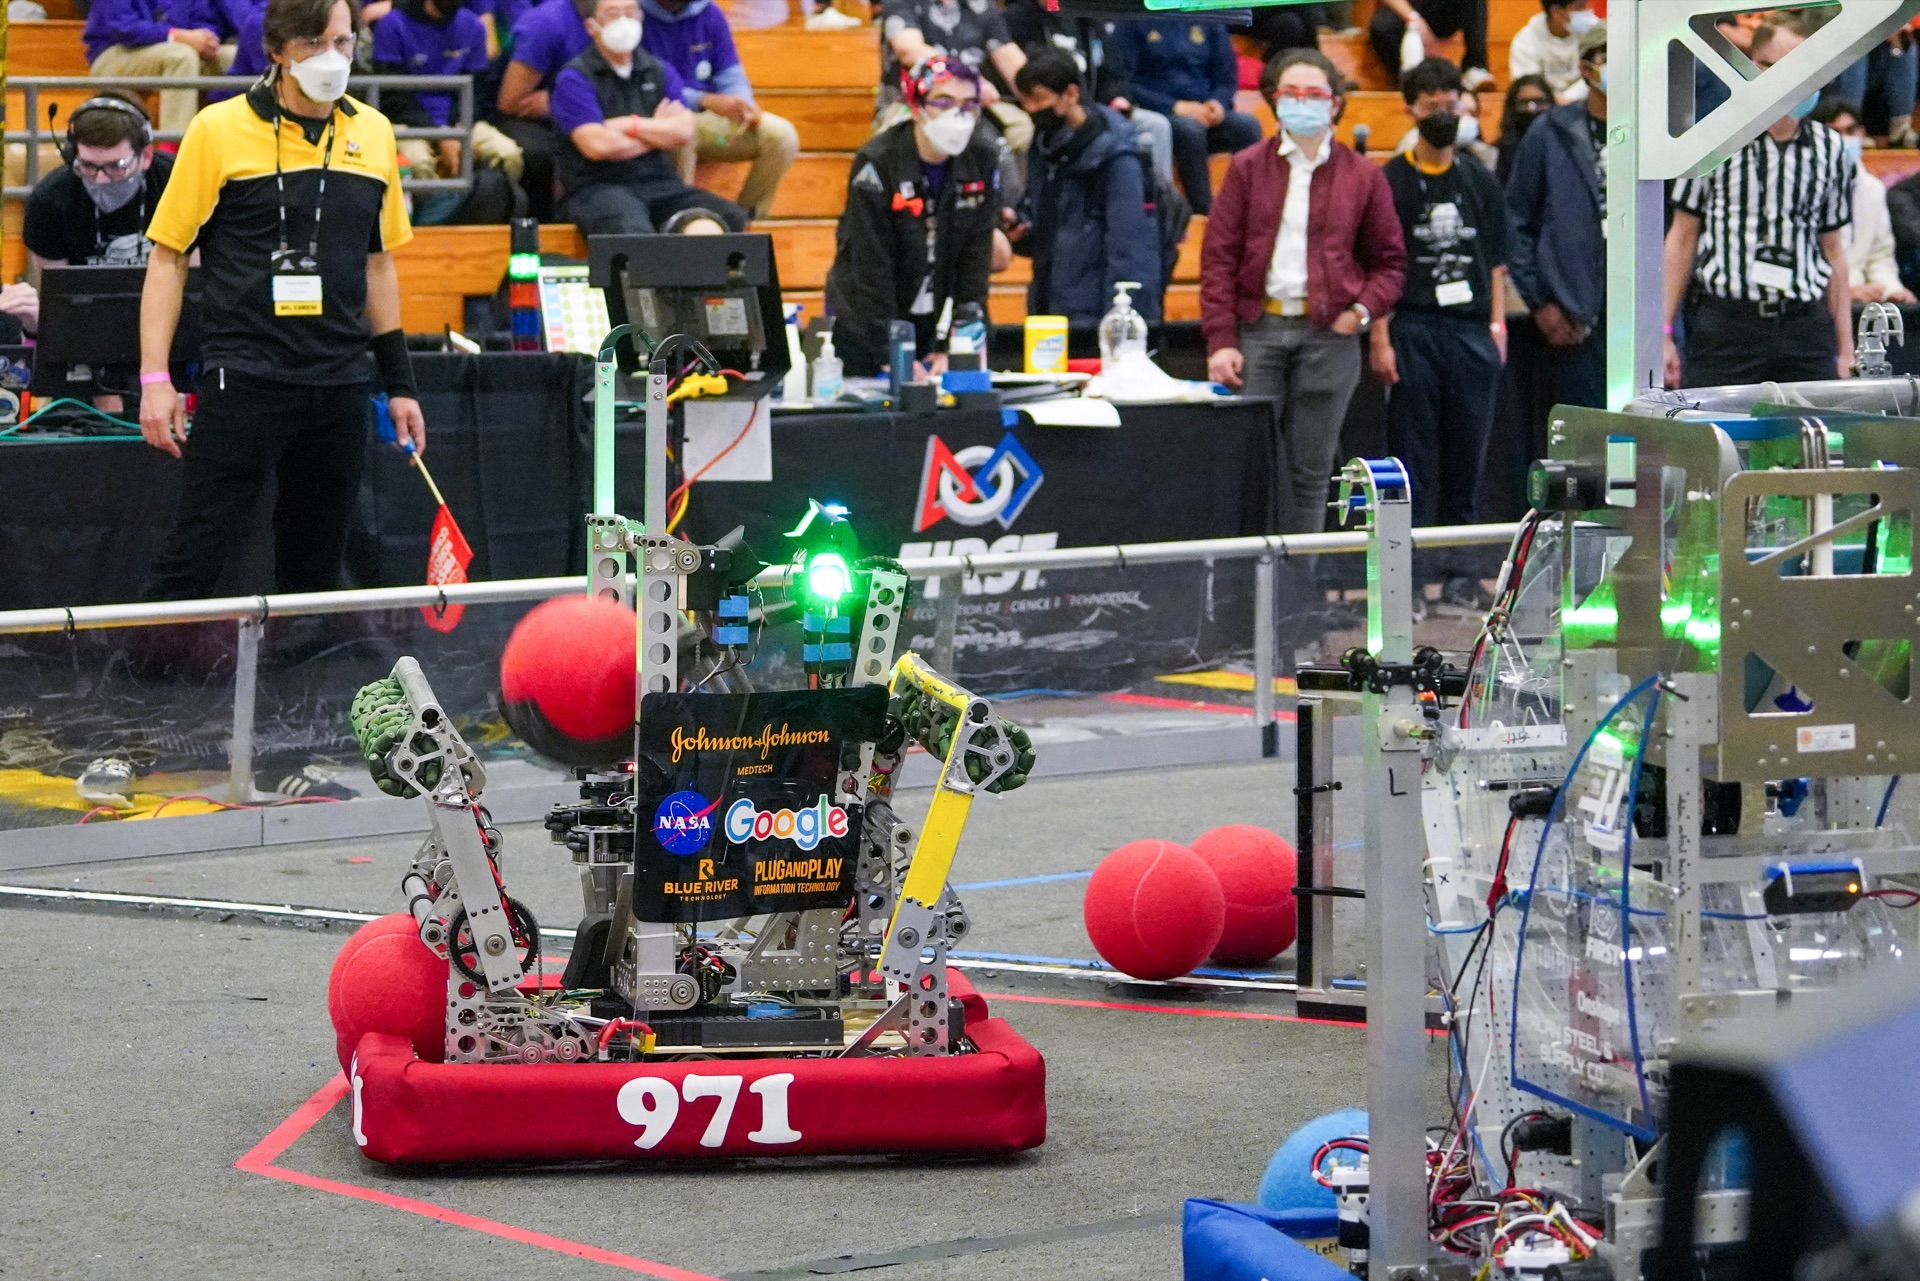
The 2022 catapult robot out on the field.
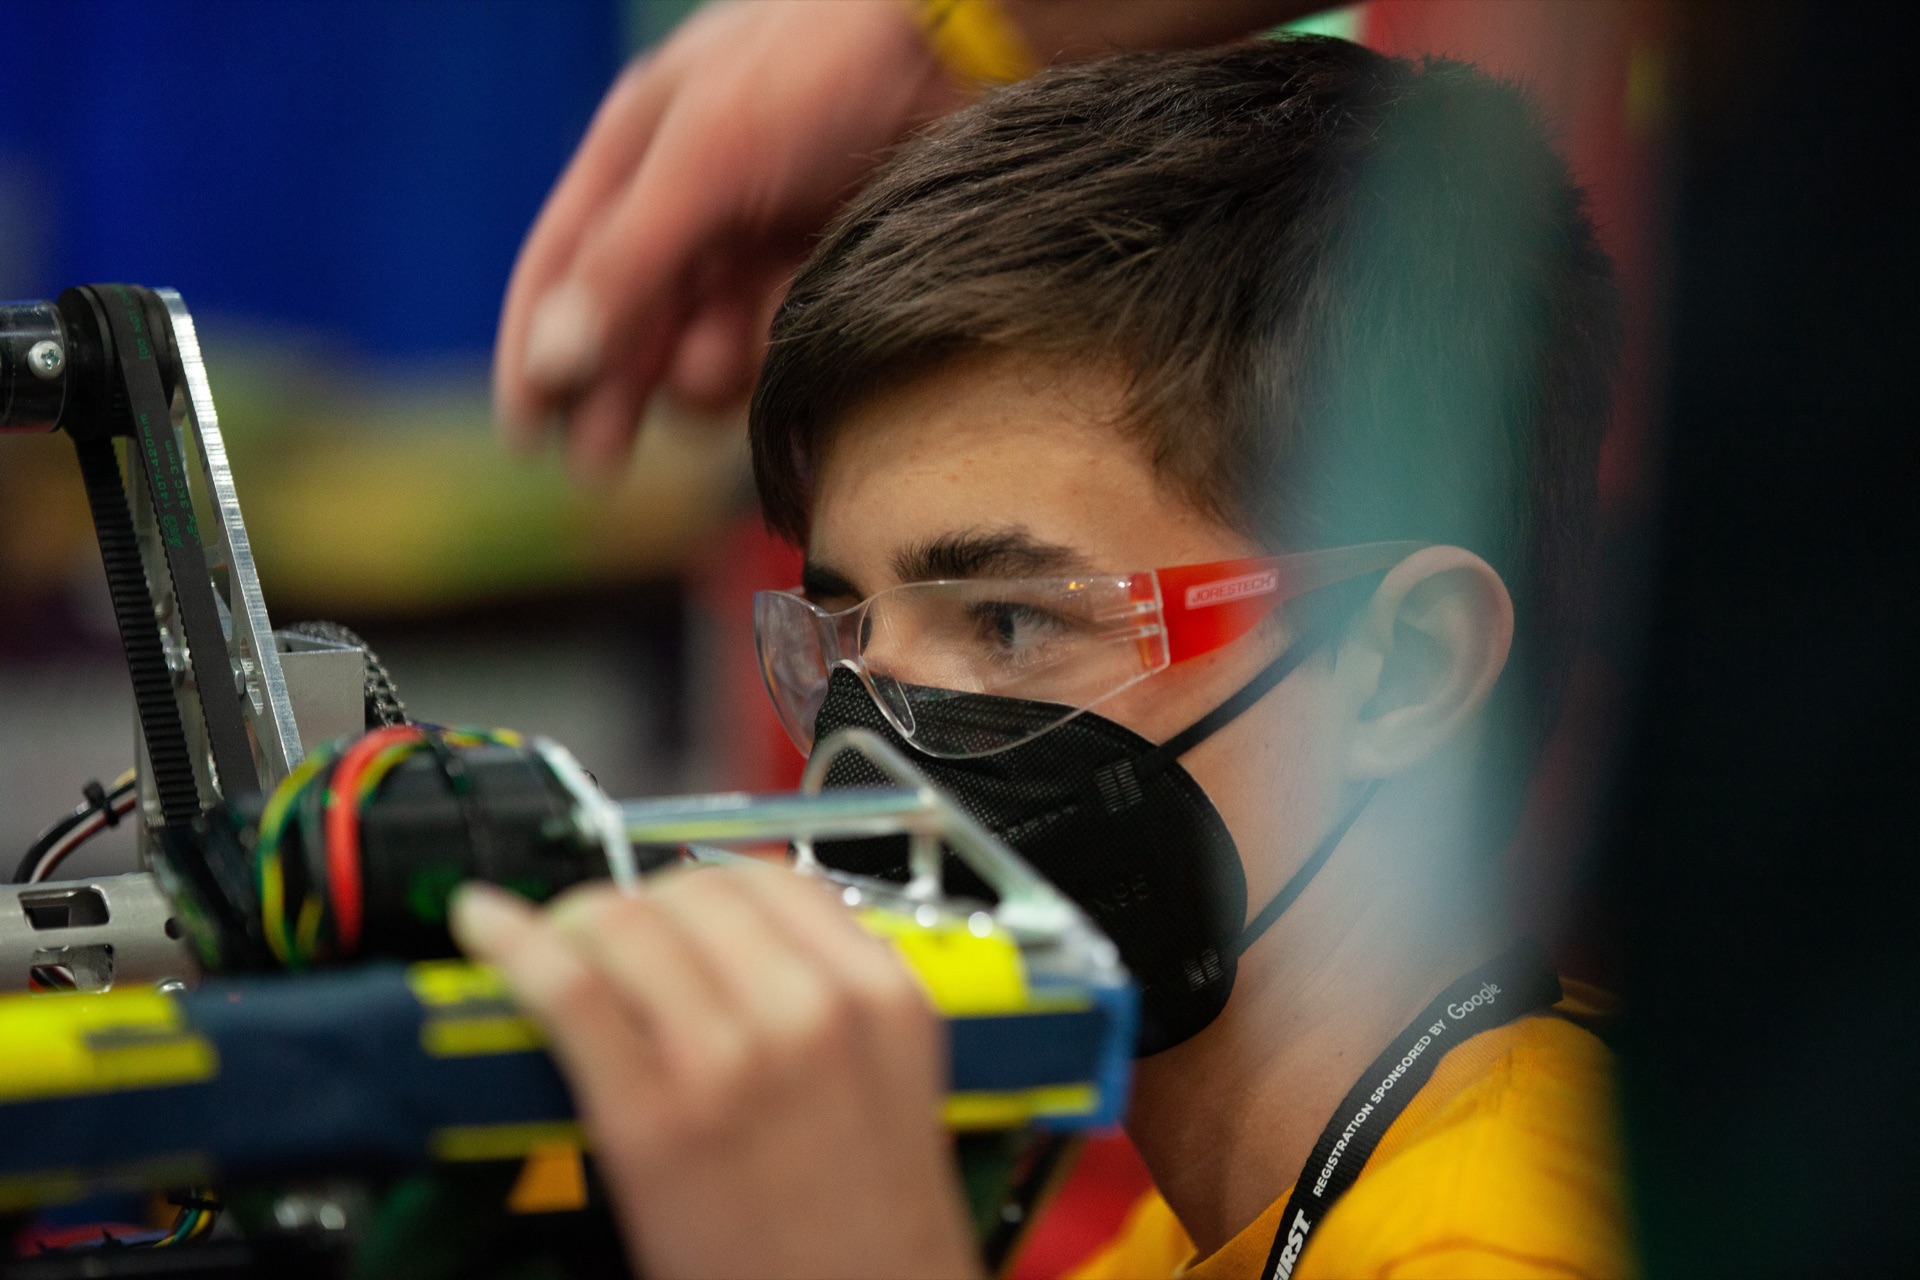
Zeroing the intake potentiometer at competition. Get this wrong and the intake is wrong everywhere.
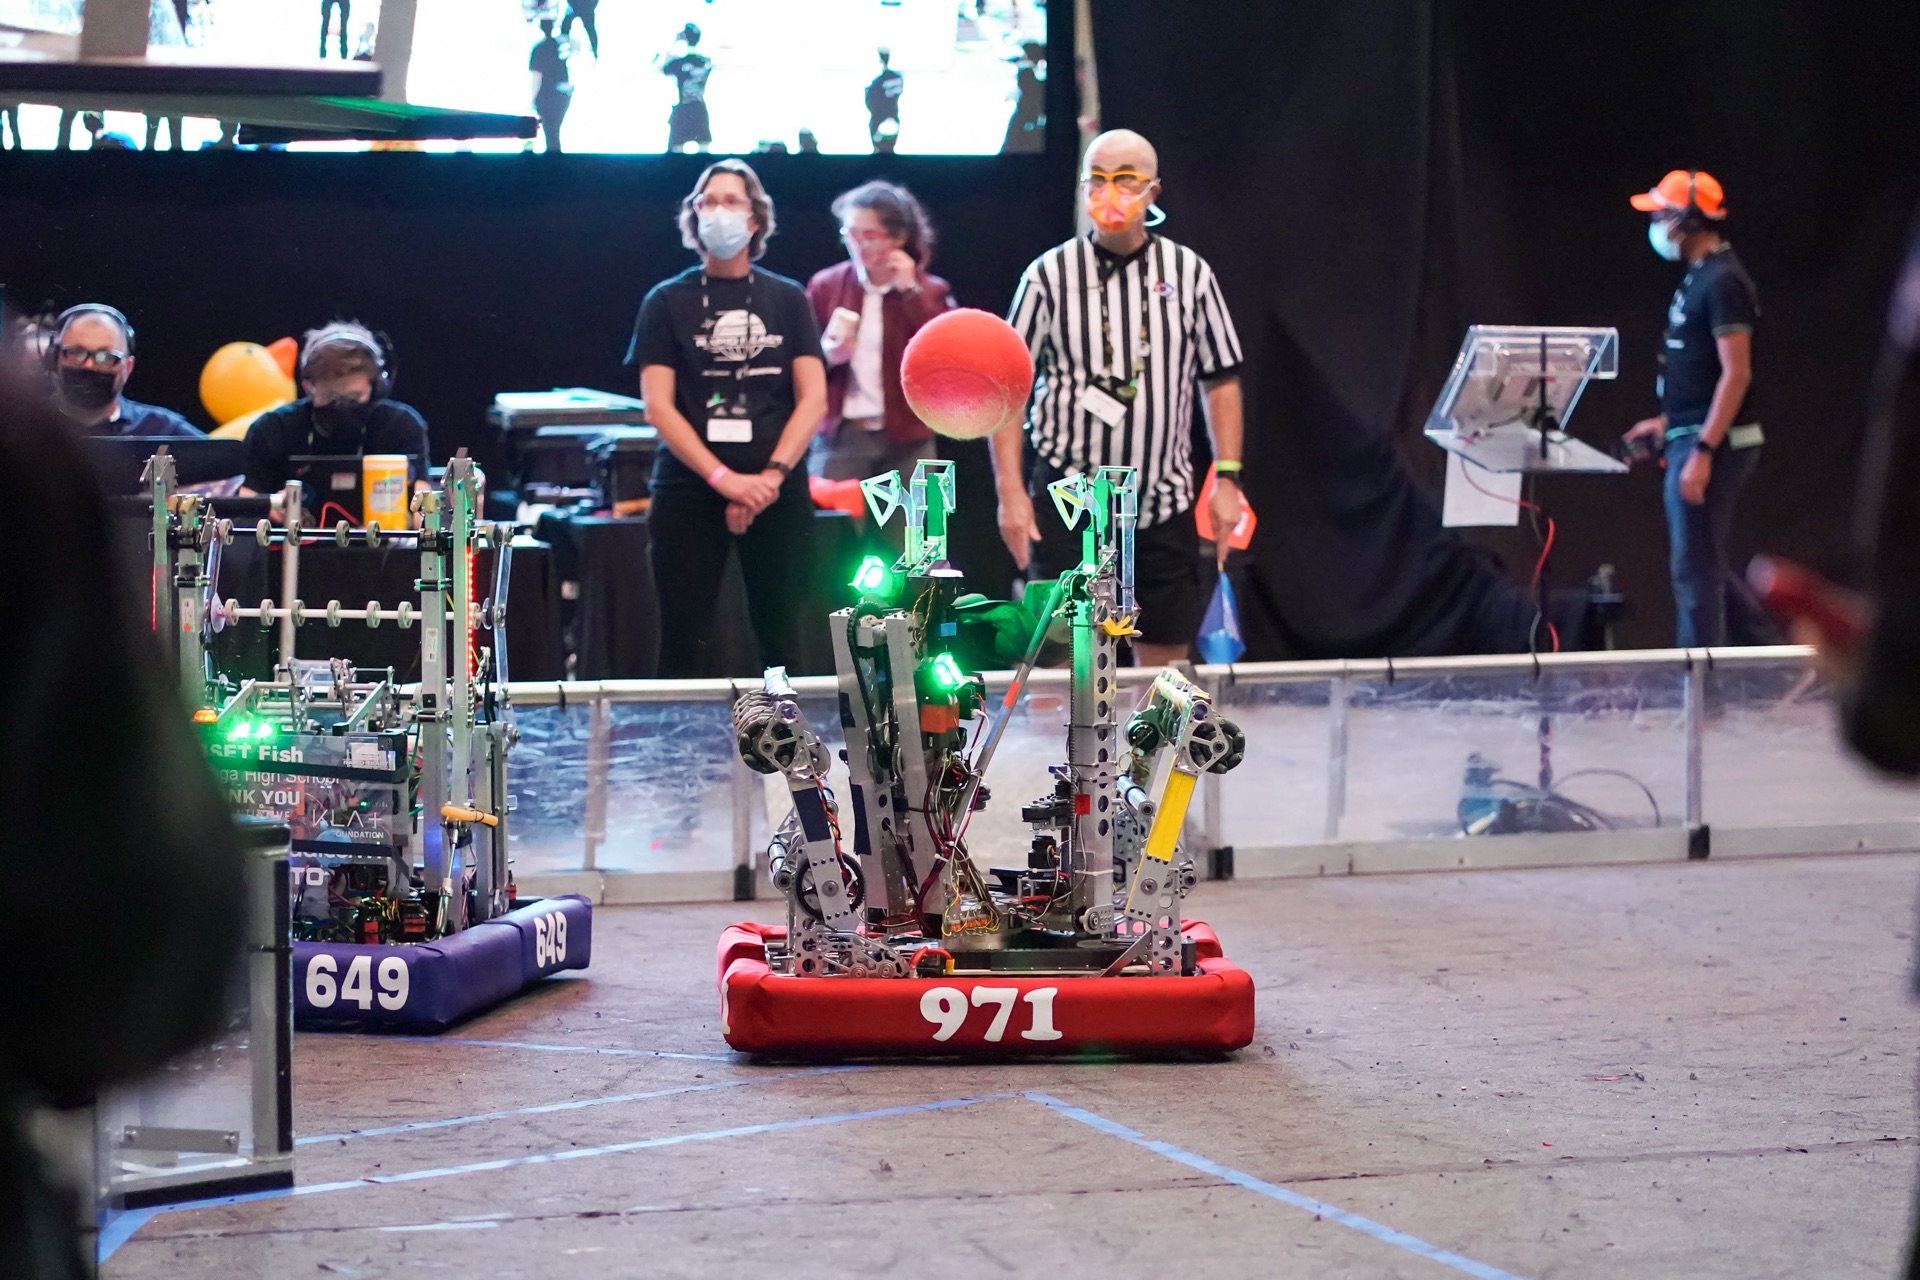
Catapult firing mid-drive, ball still in the air.
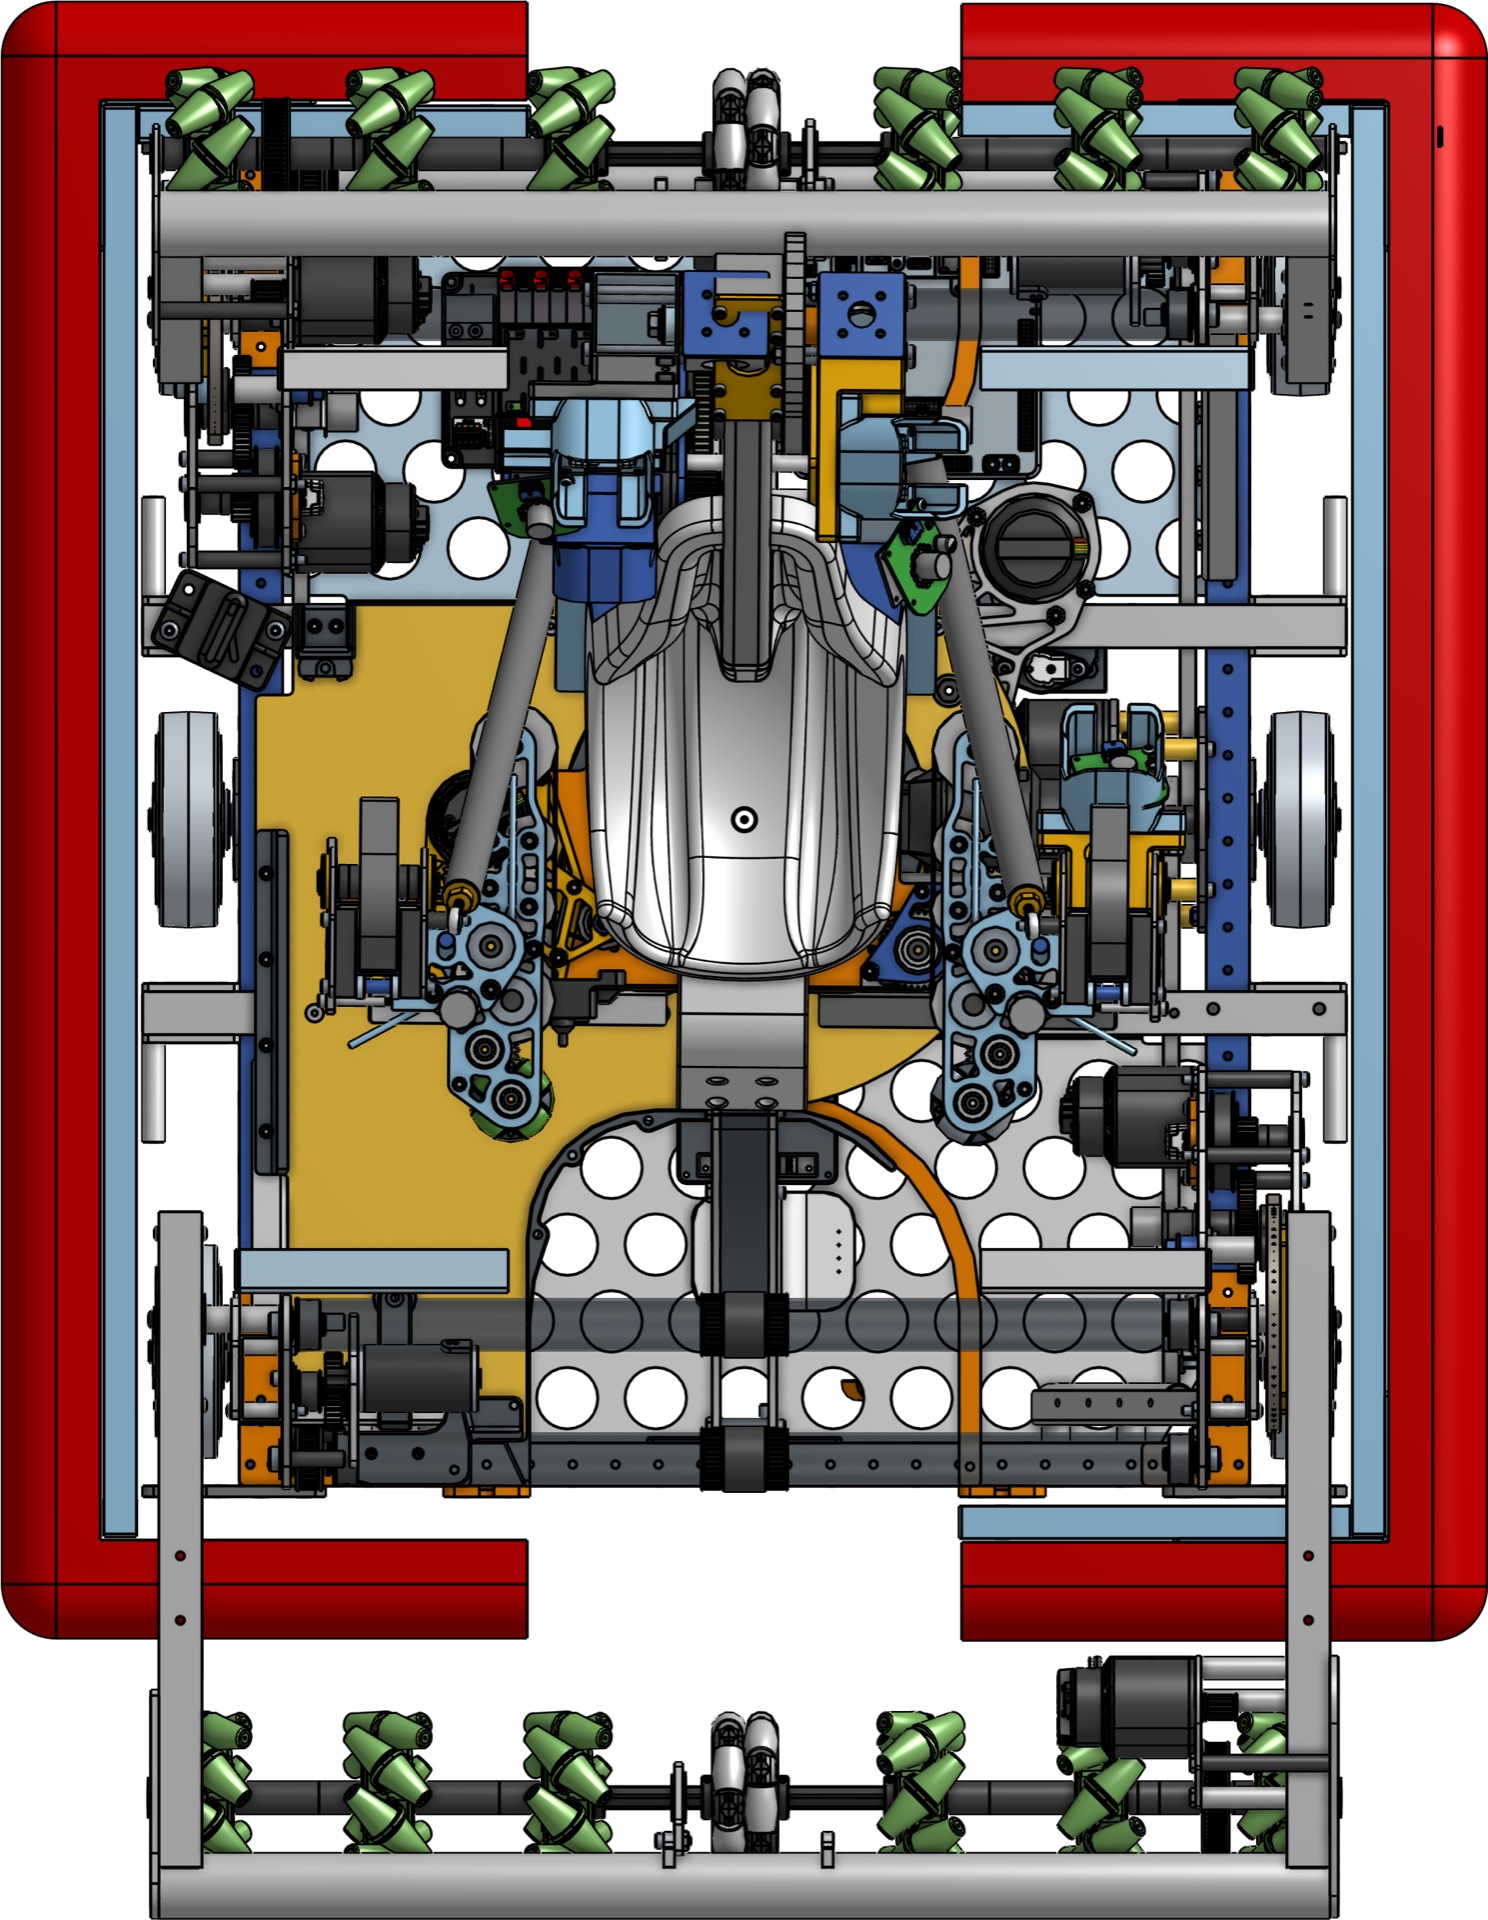
Top down CAD of the full 2022 robot. Everything packed into one frame.
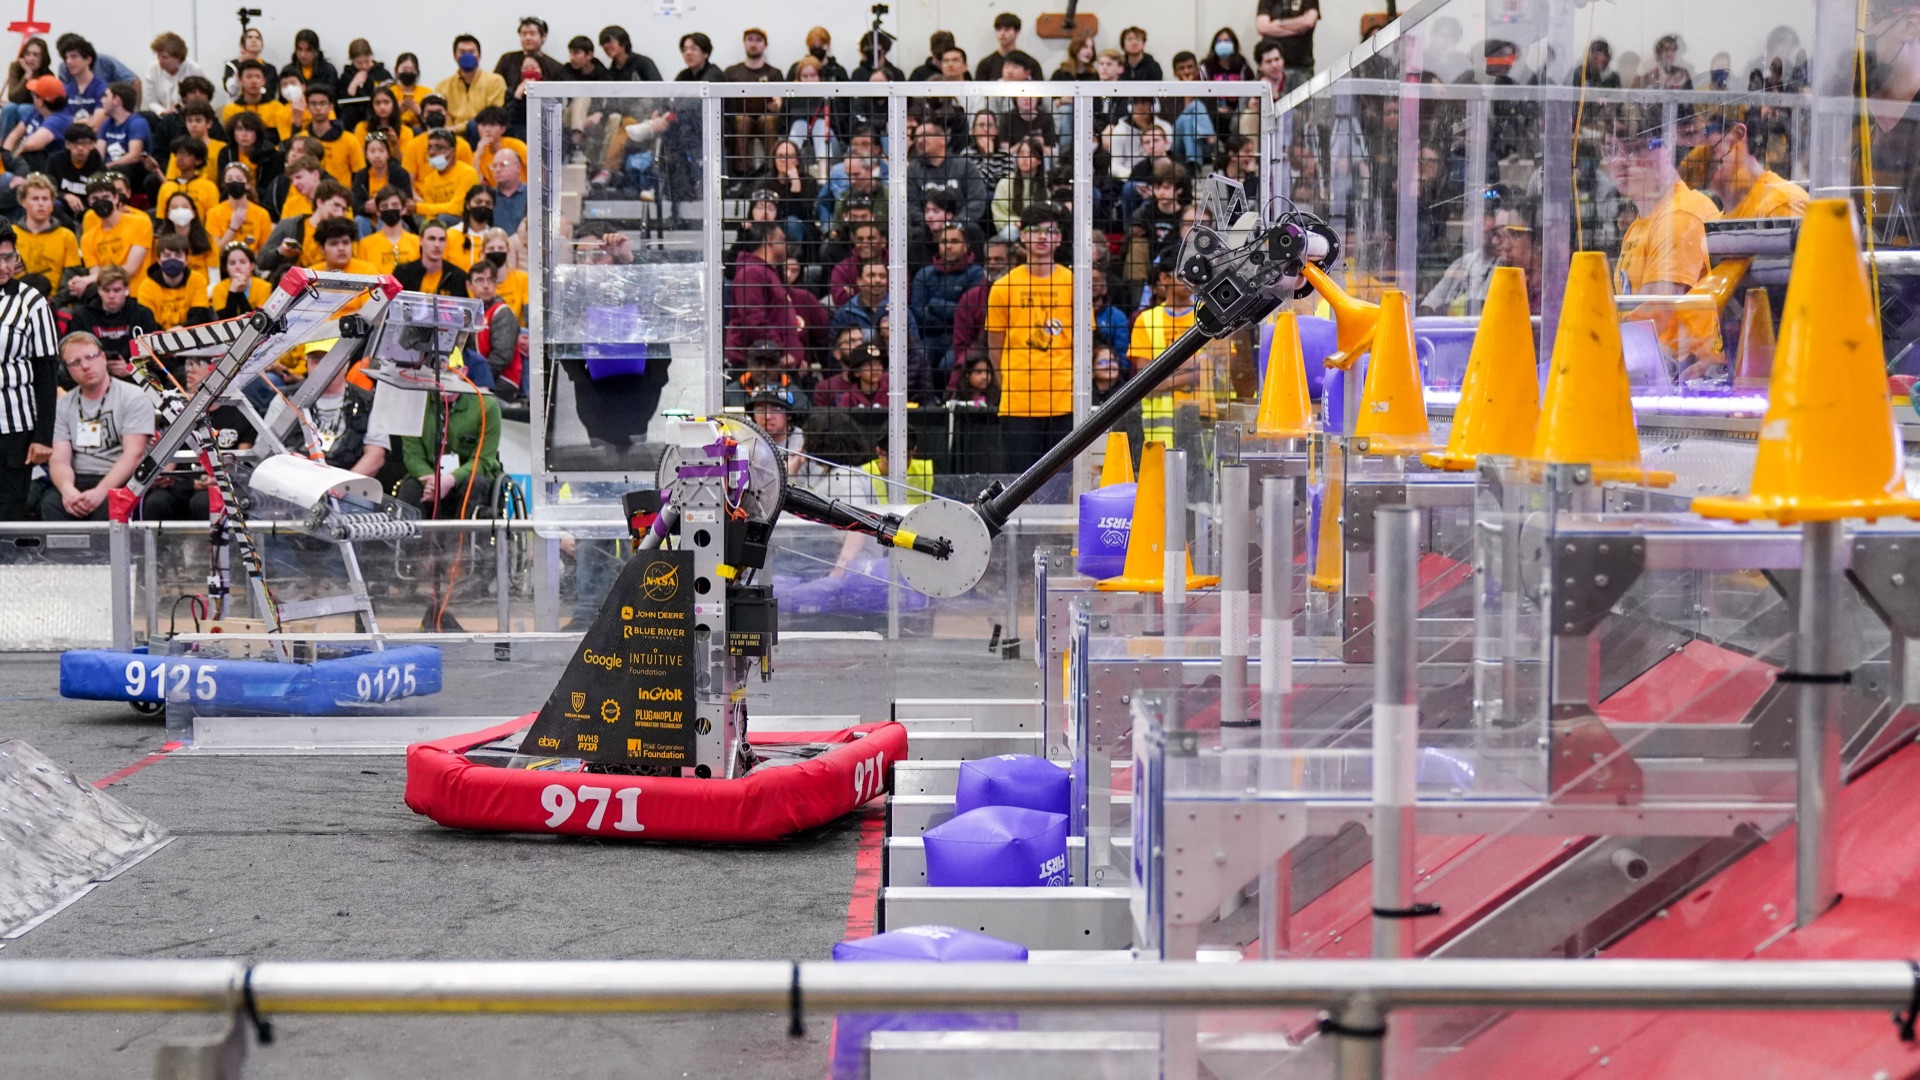
The 2023 arm at full stretch dropping a cone on the top level.
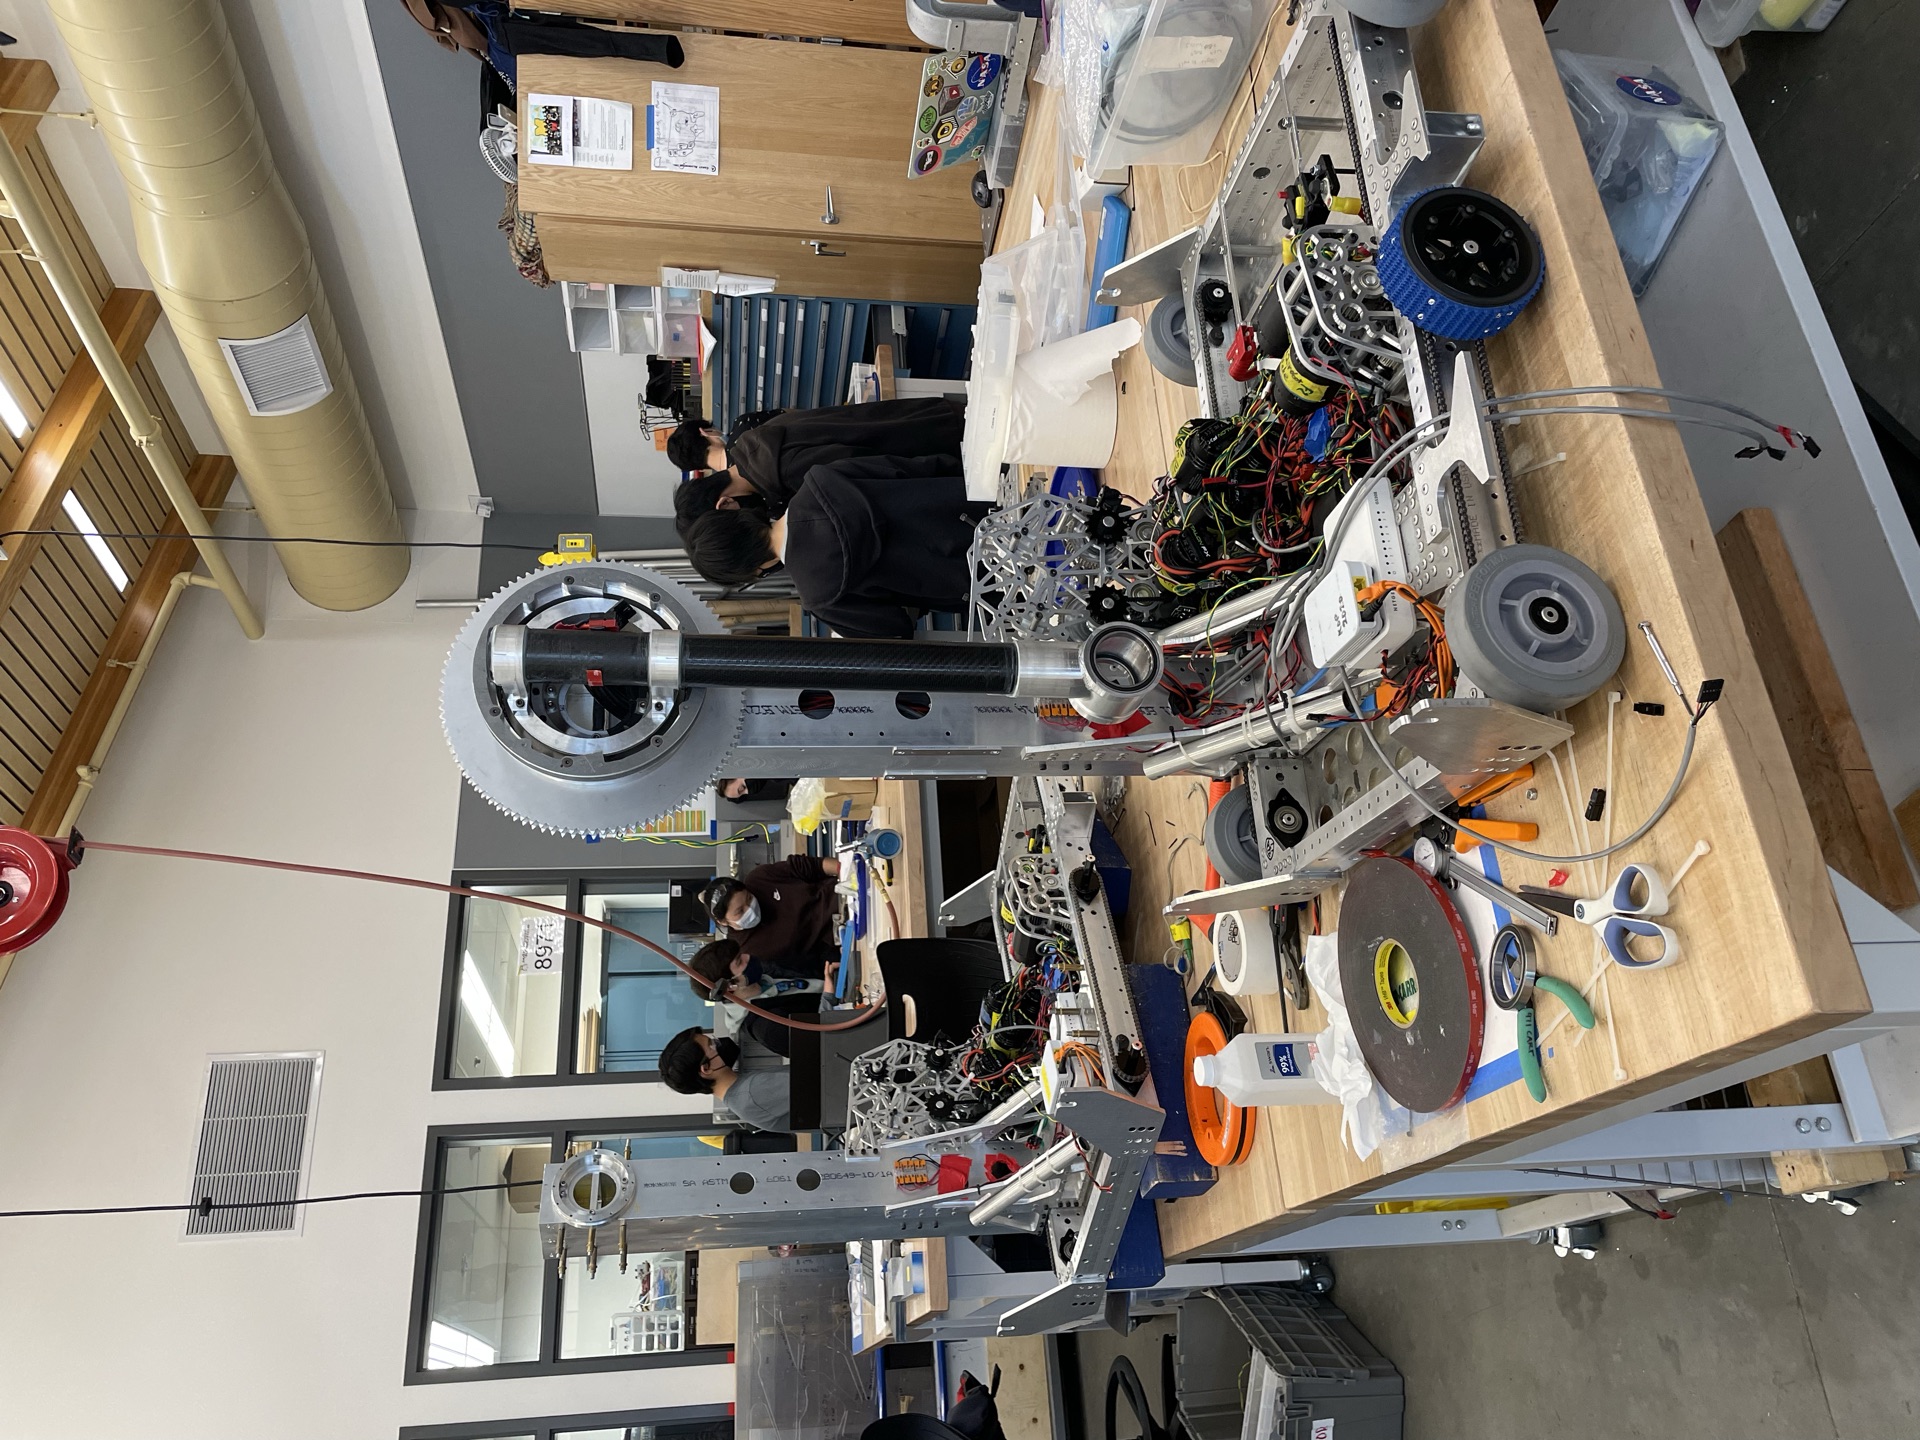
The 2023 robot coming together in the shop.
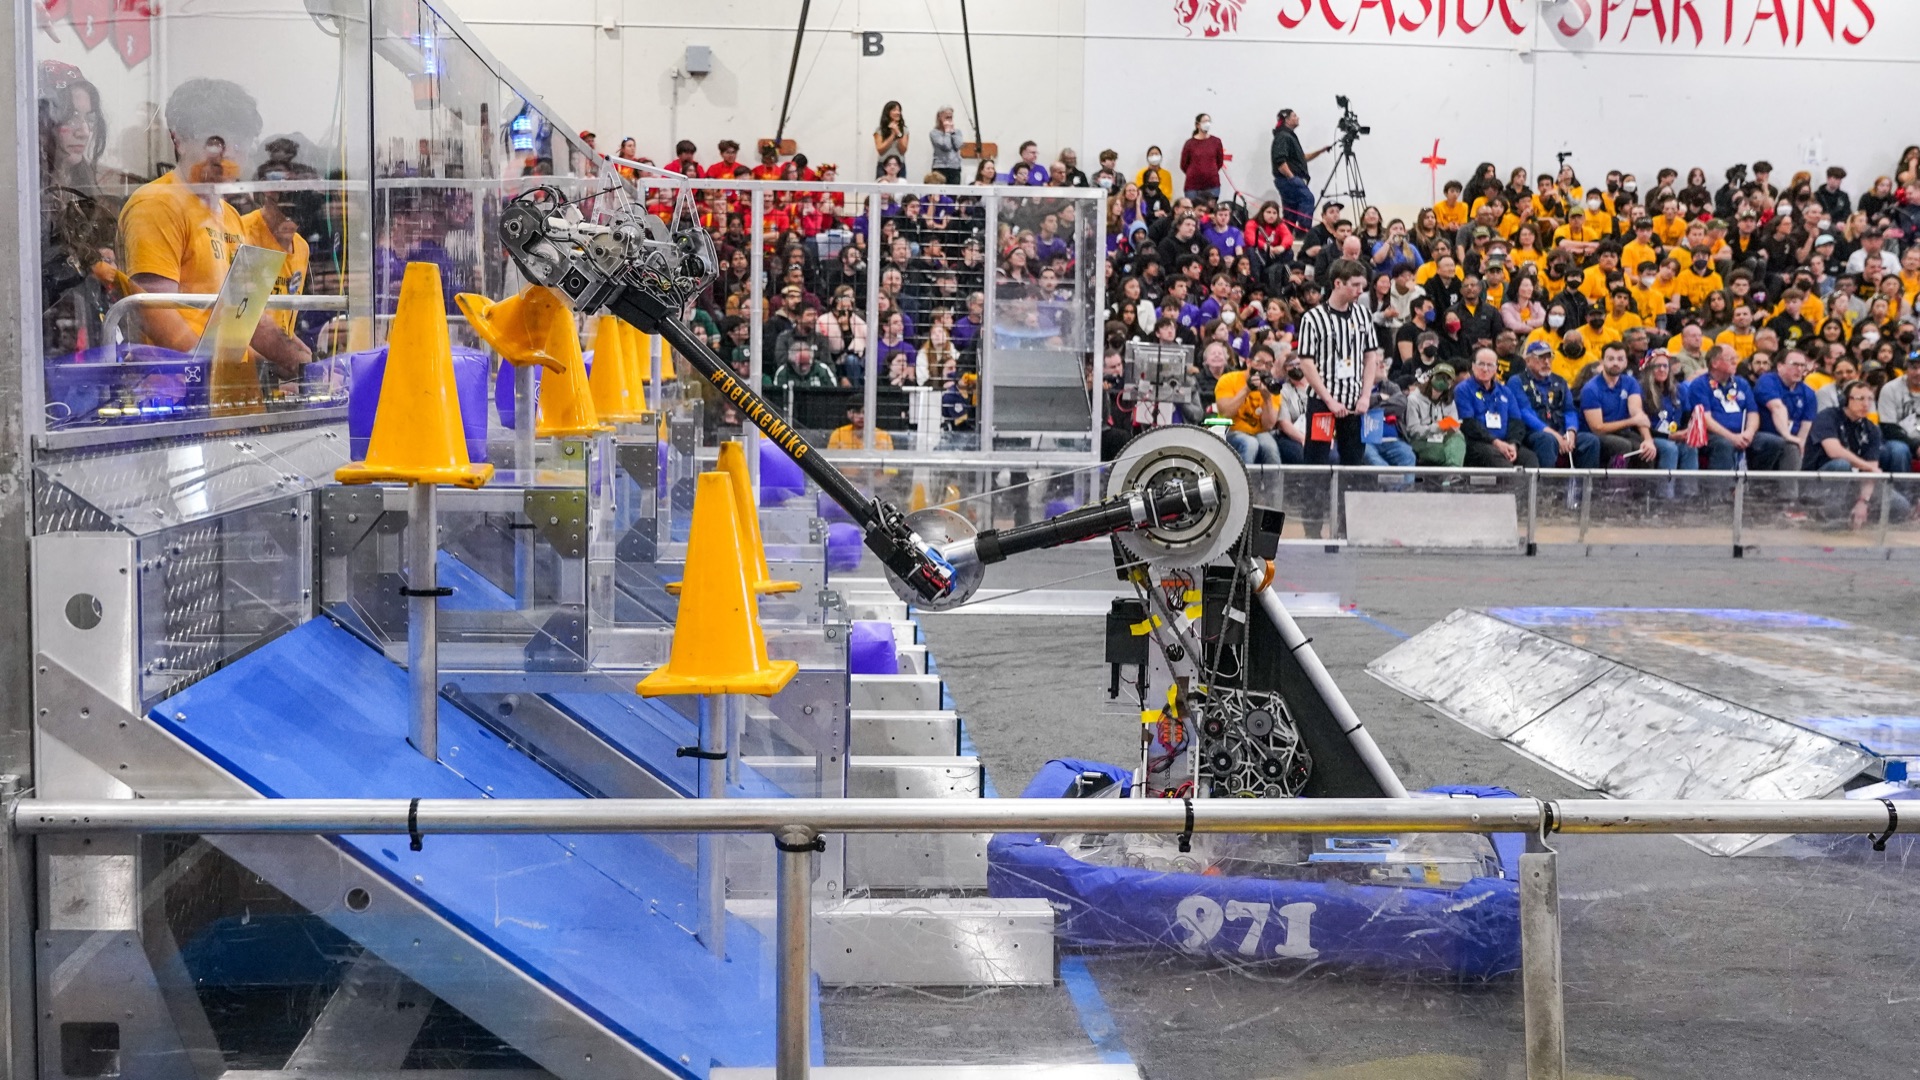
Placing a cone from another angle.
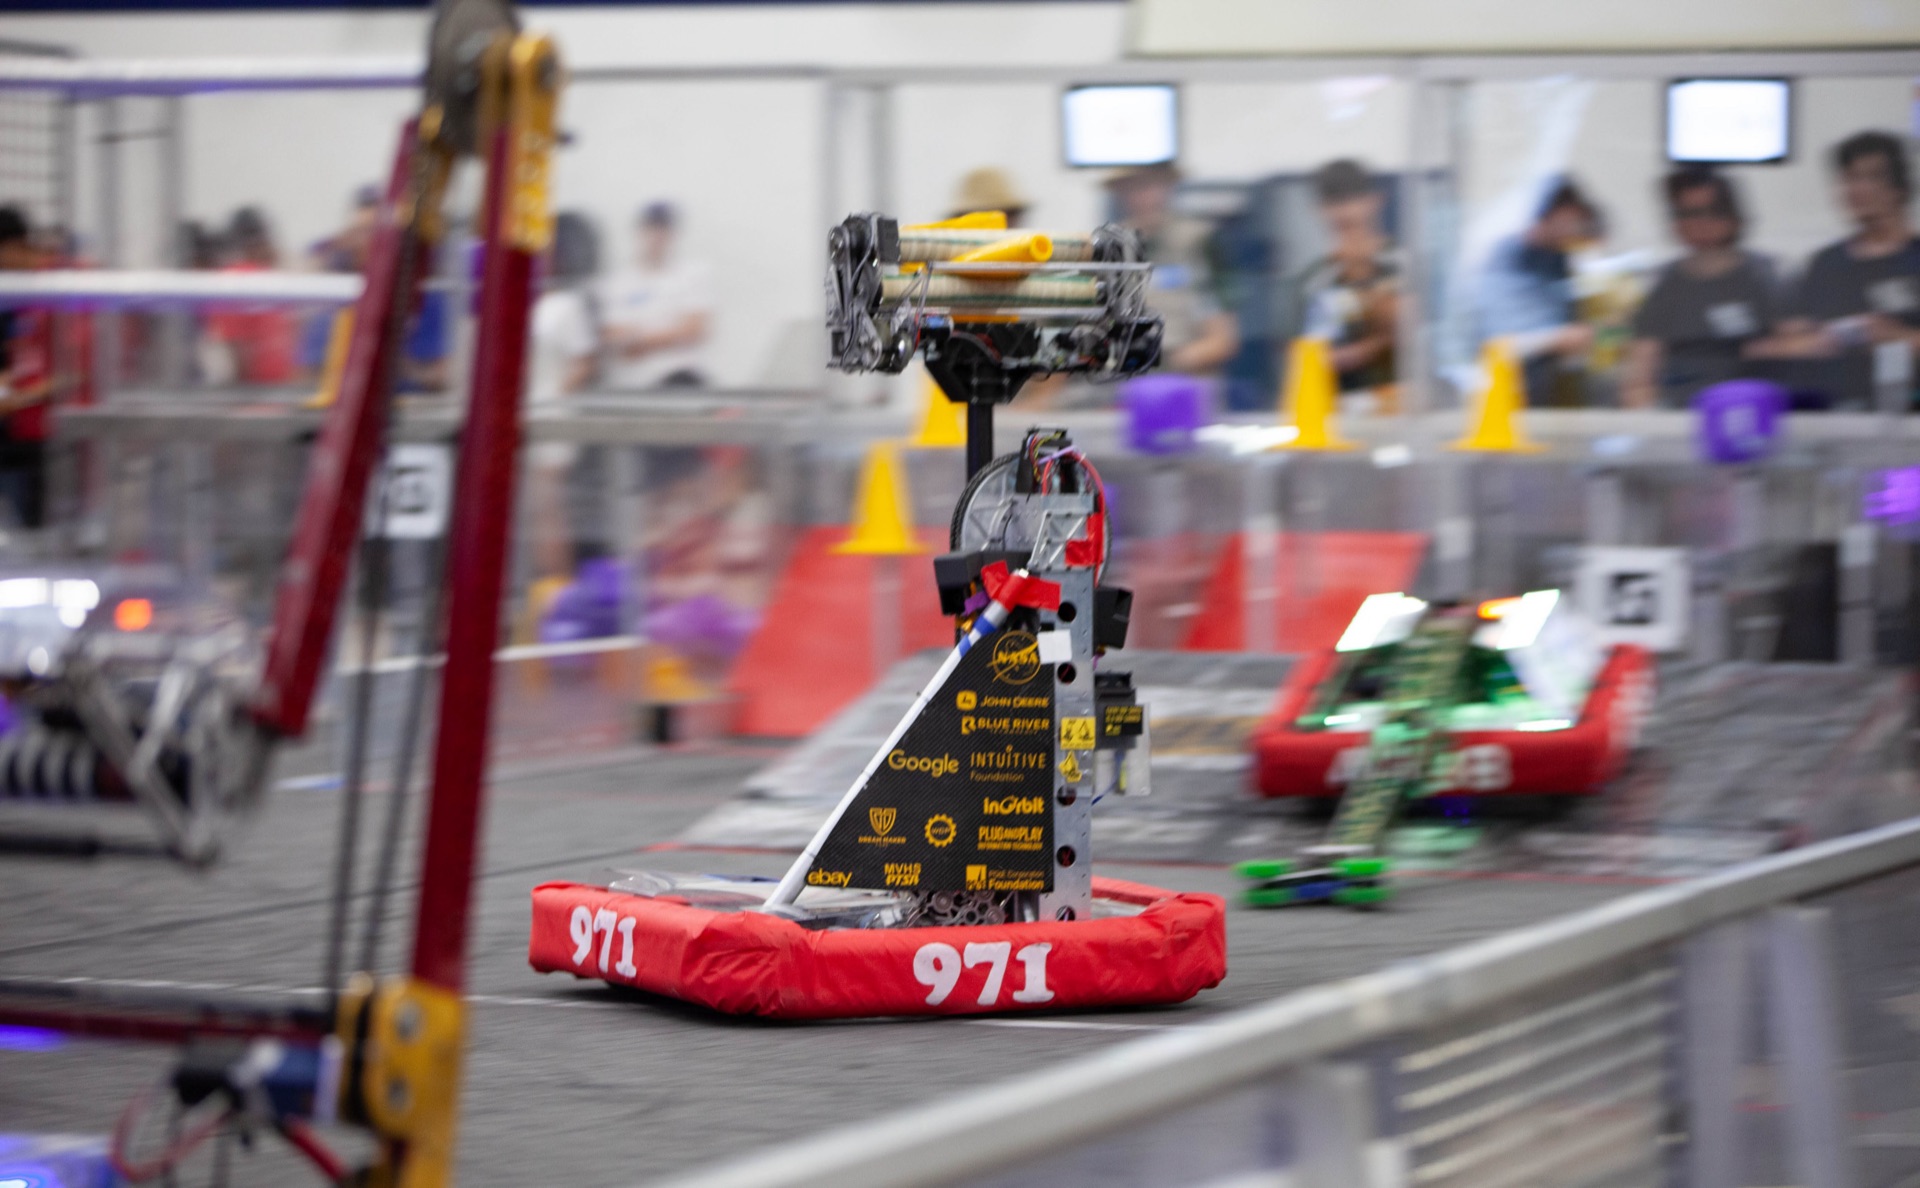
Hauling across the field with the arm up and a cone locked in.
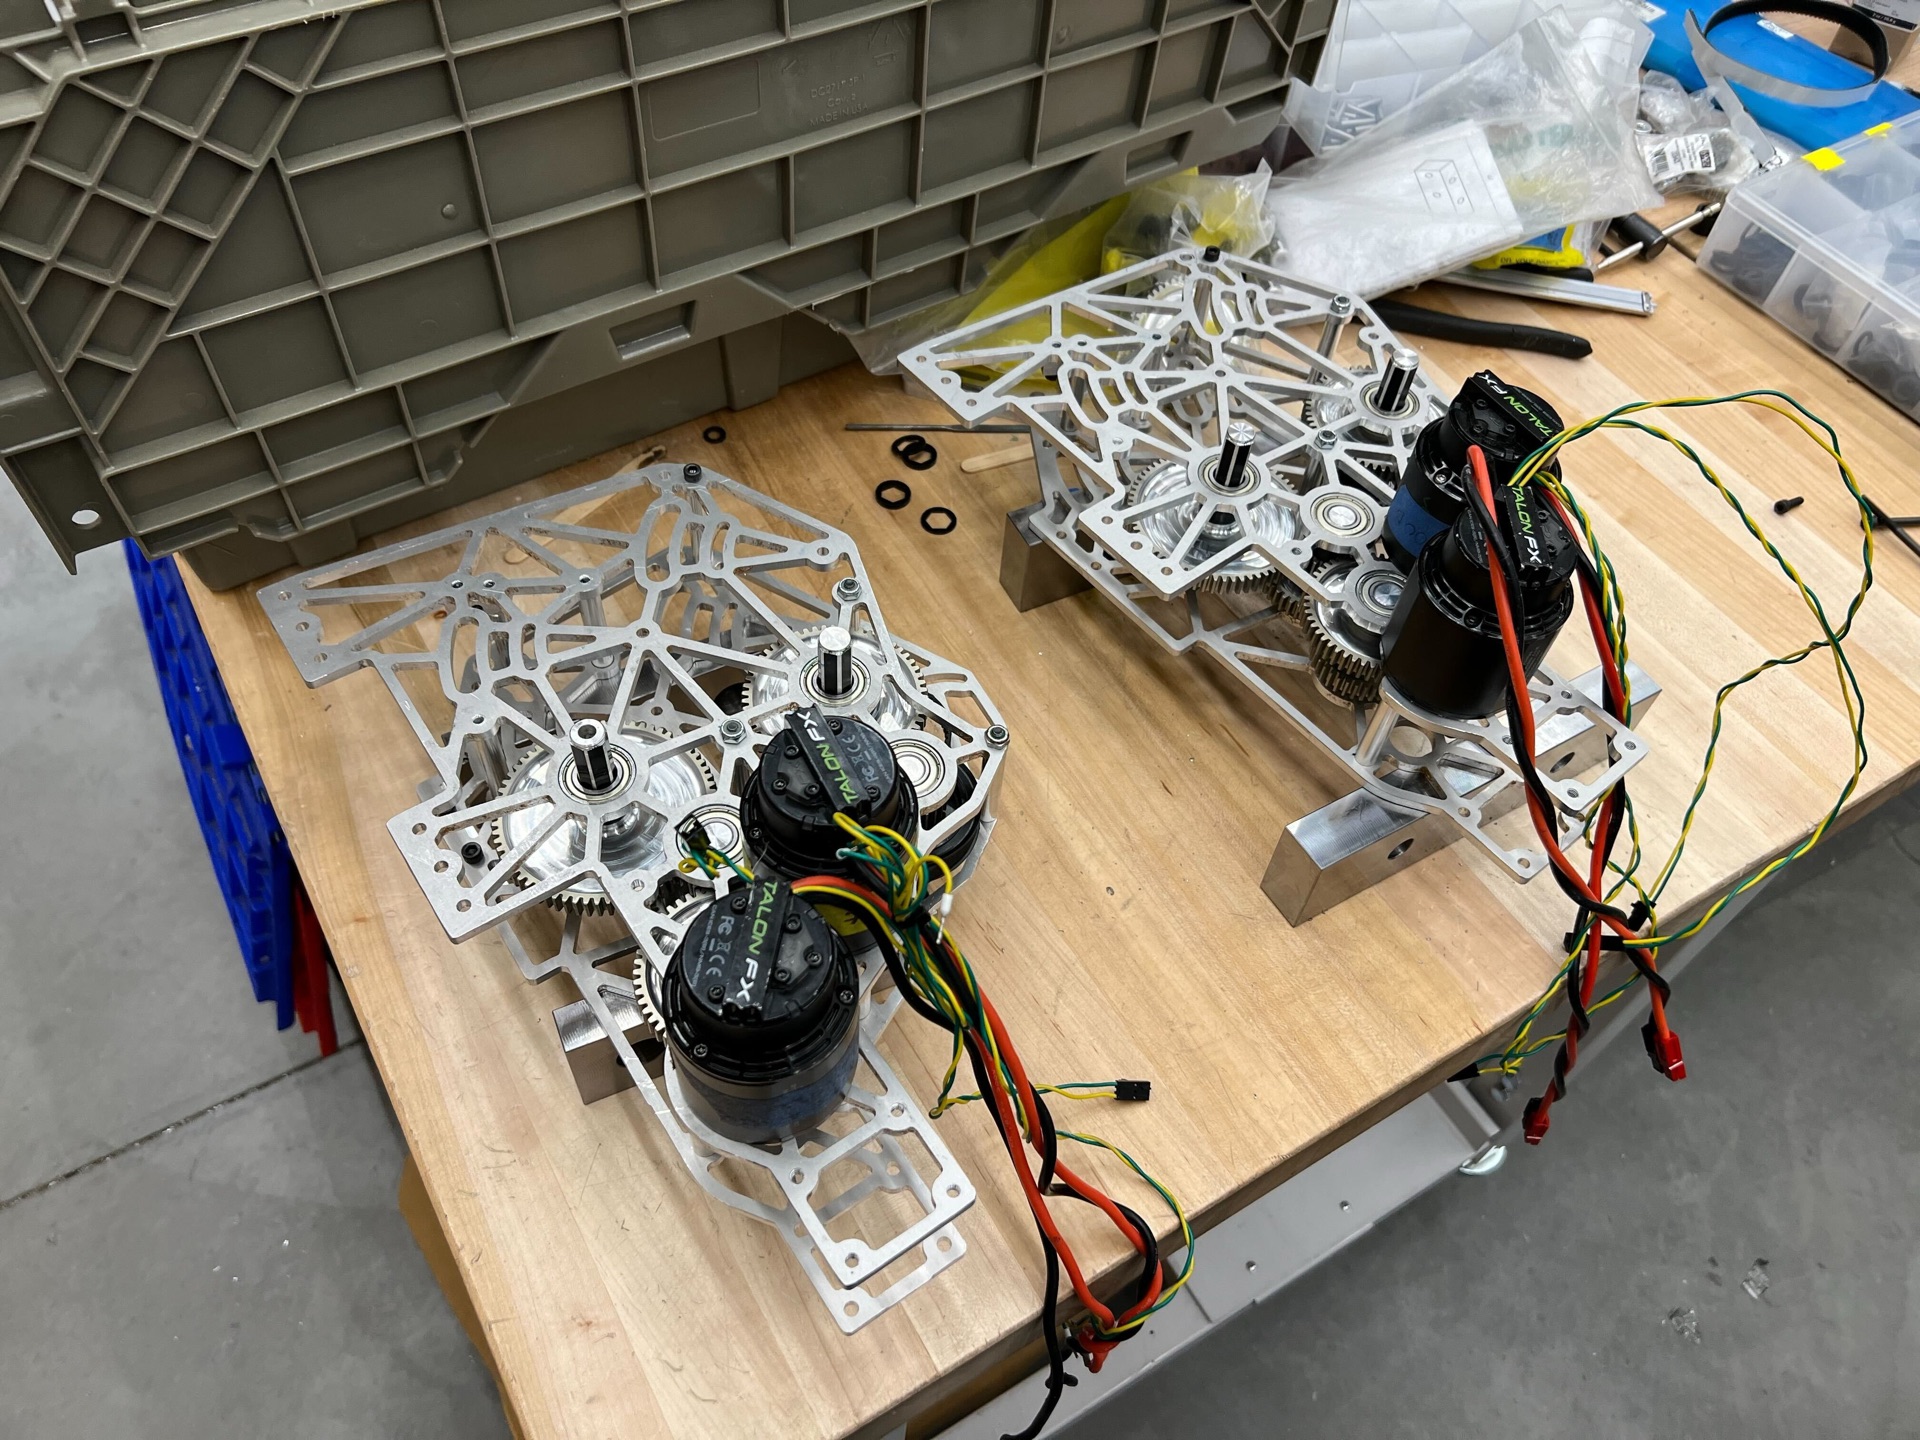
The comically large gearboxes for the 7 foot carbon fiber arm.
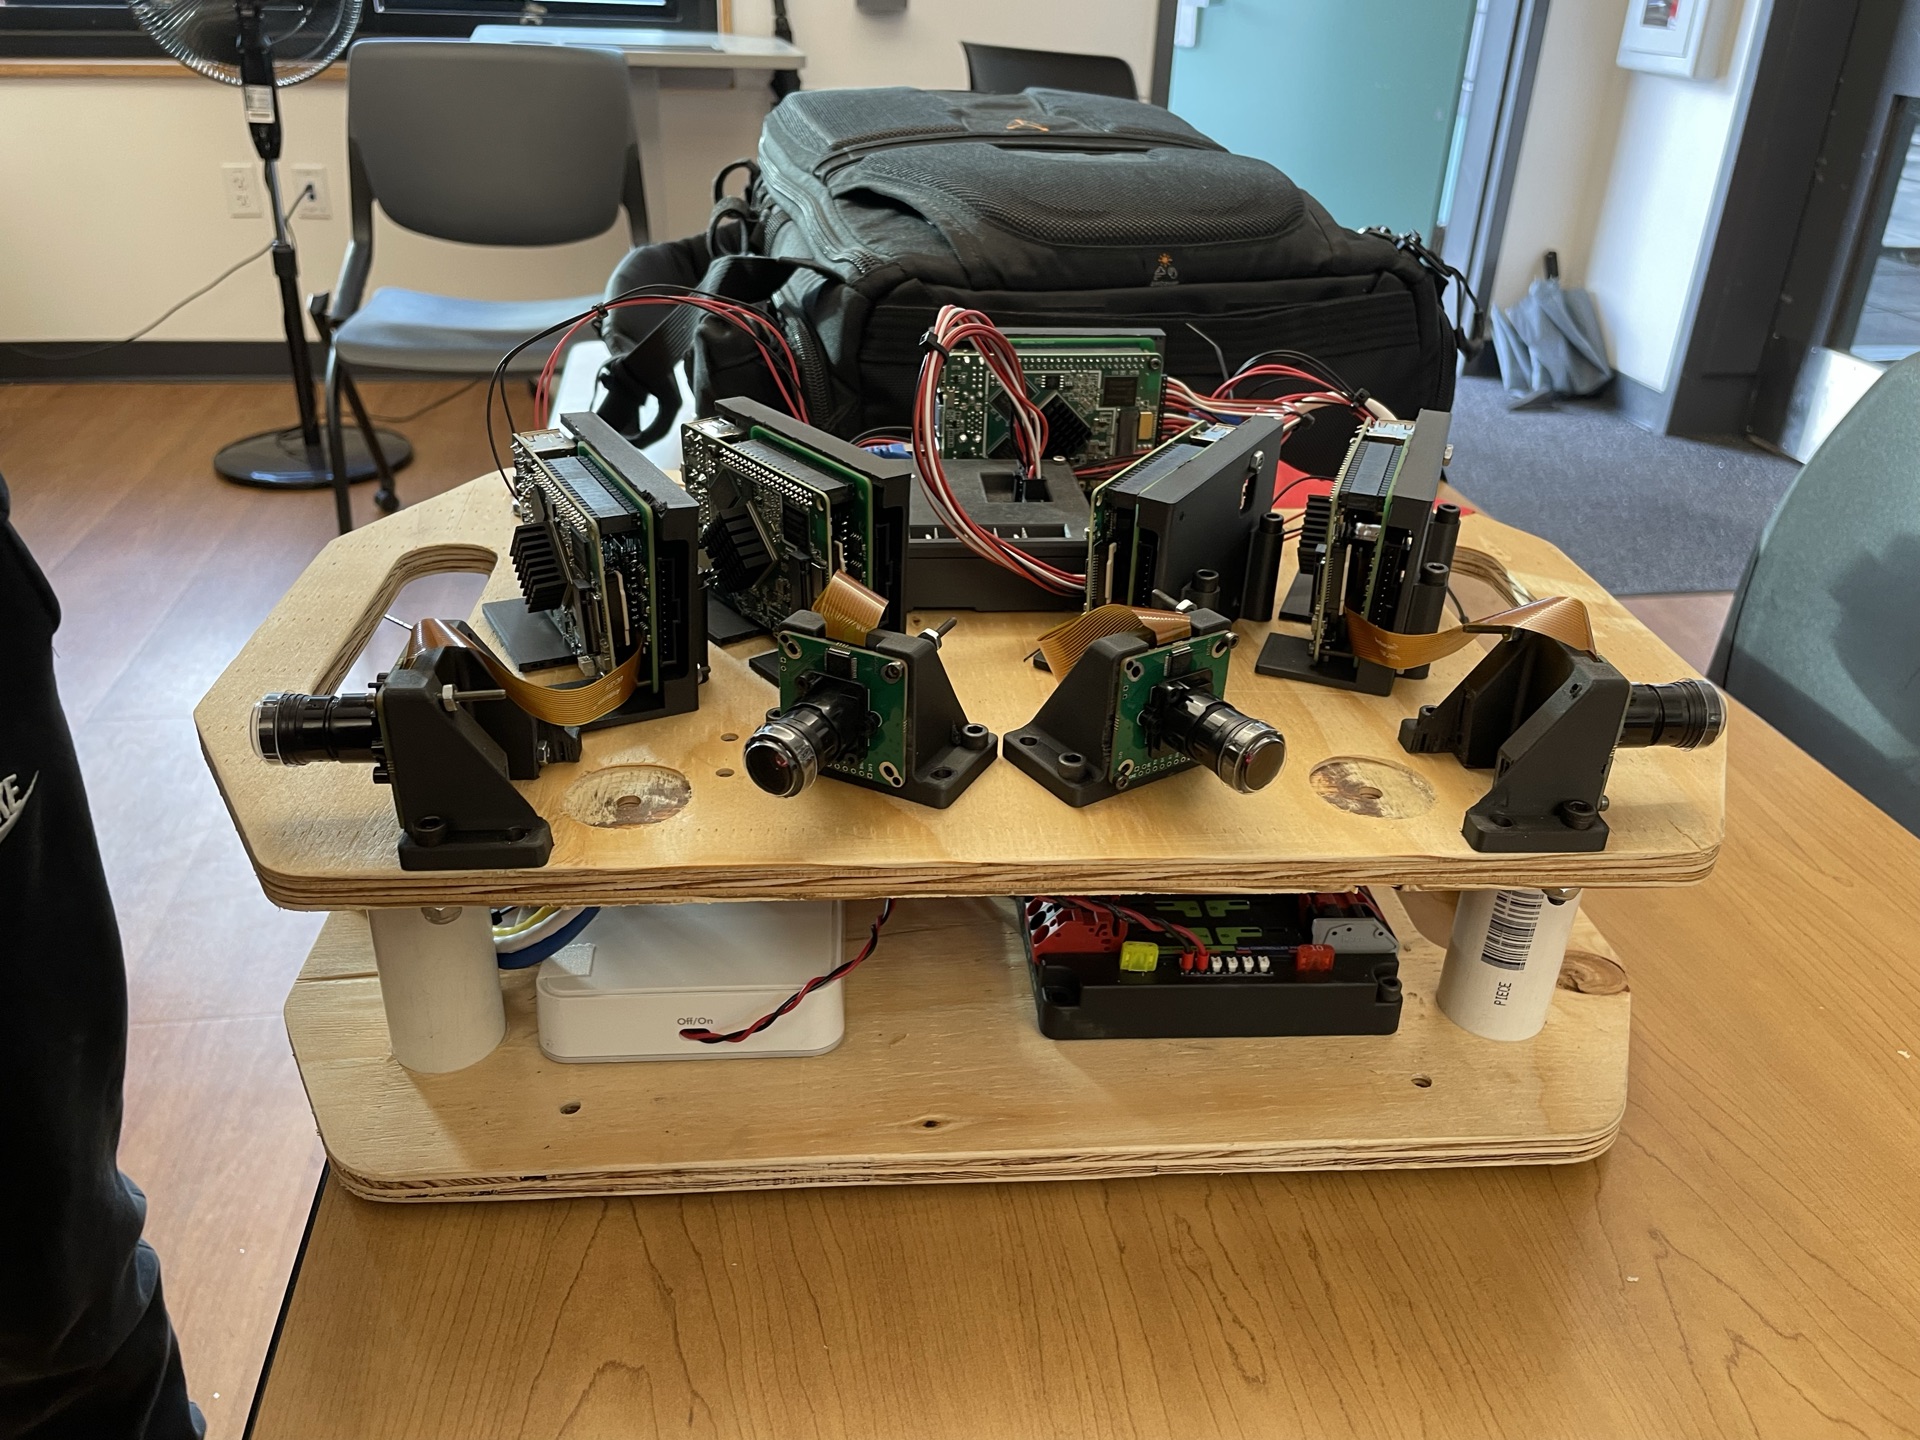
A box of Raspberry Pis and cameras I used to map every AprilTag on the field down to the millimeter, because no two fields are actually built the same.
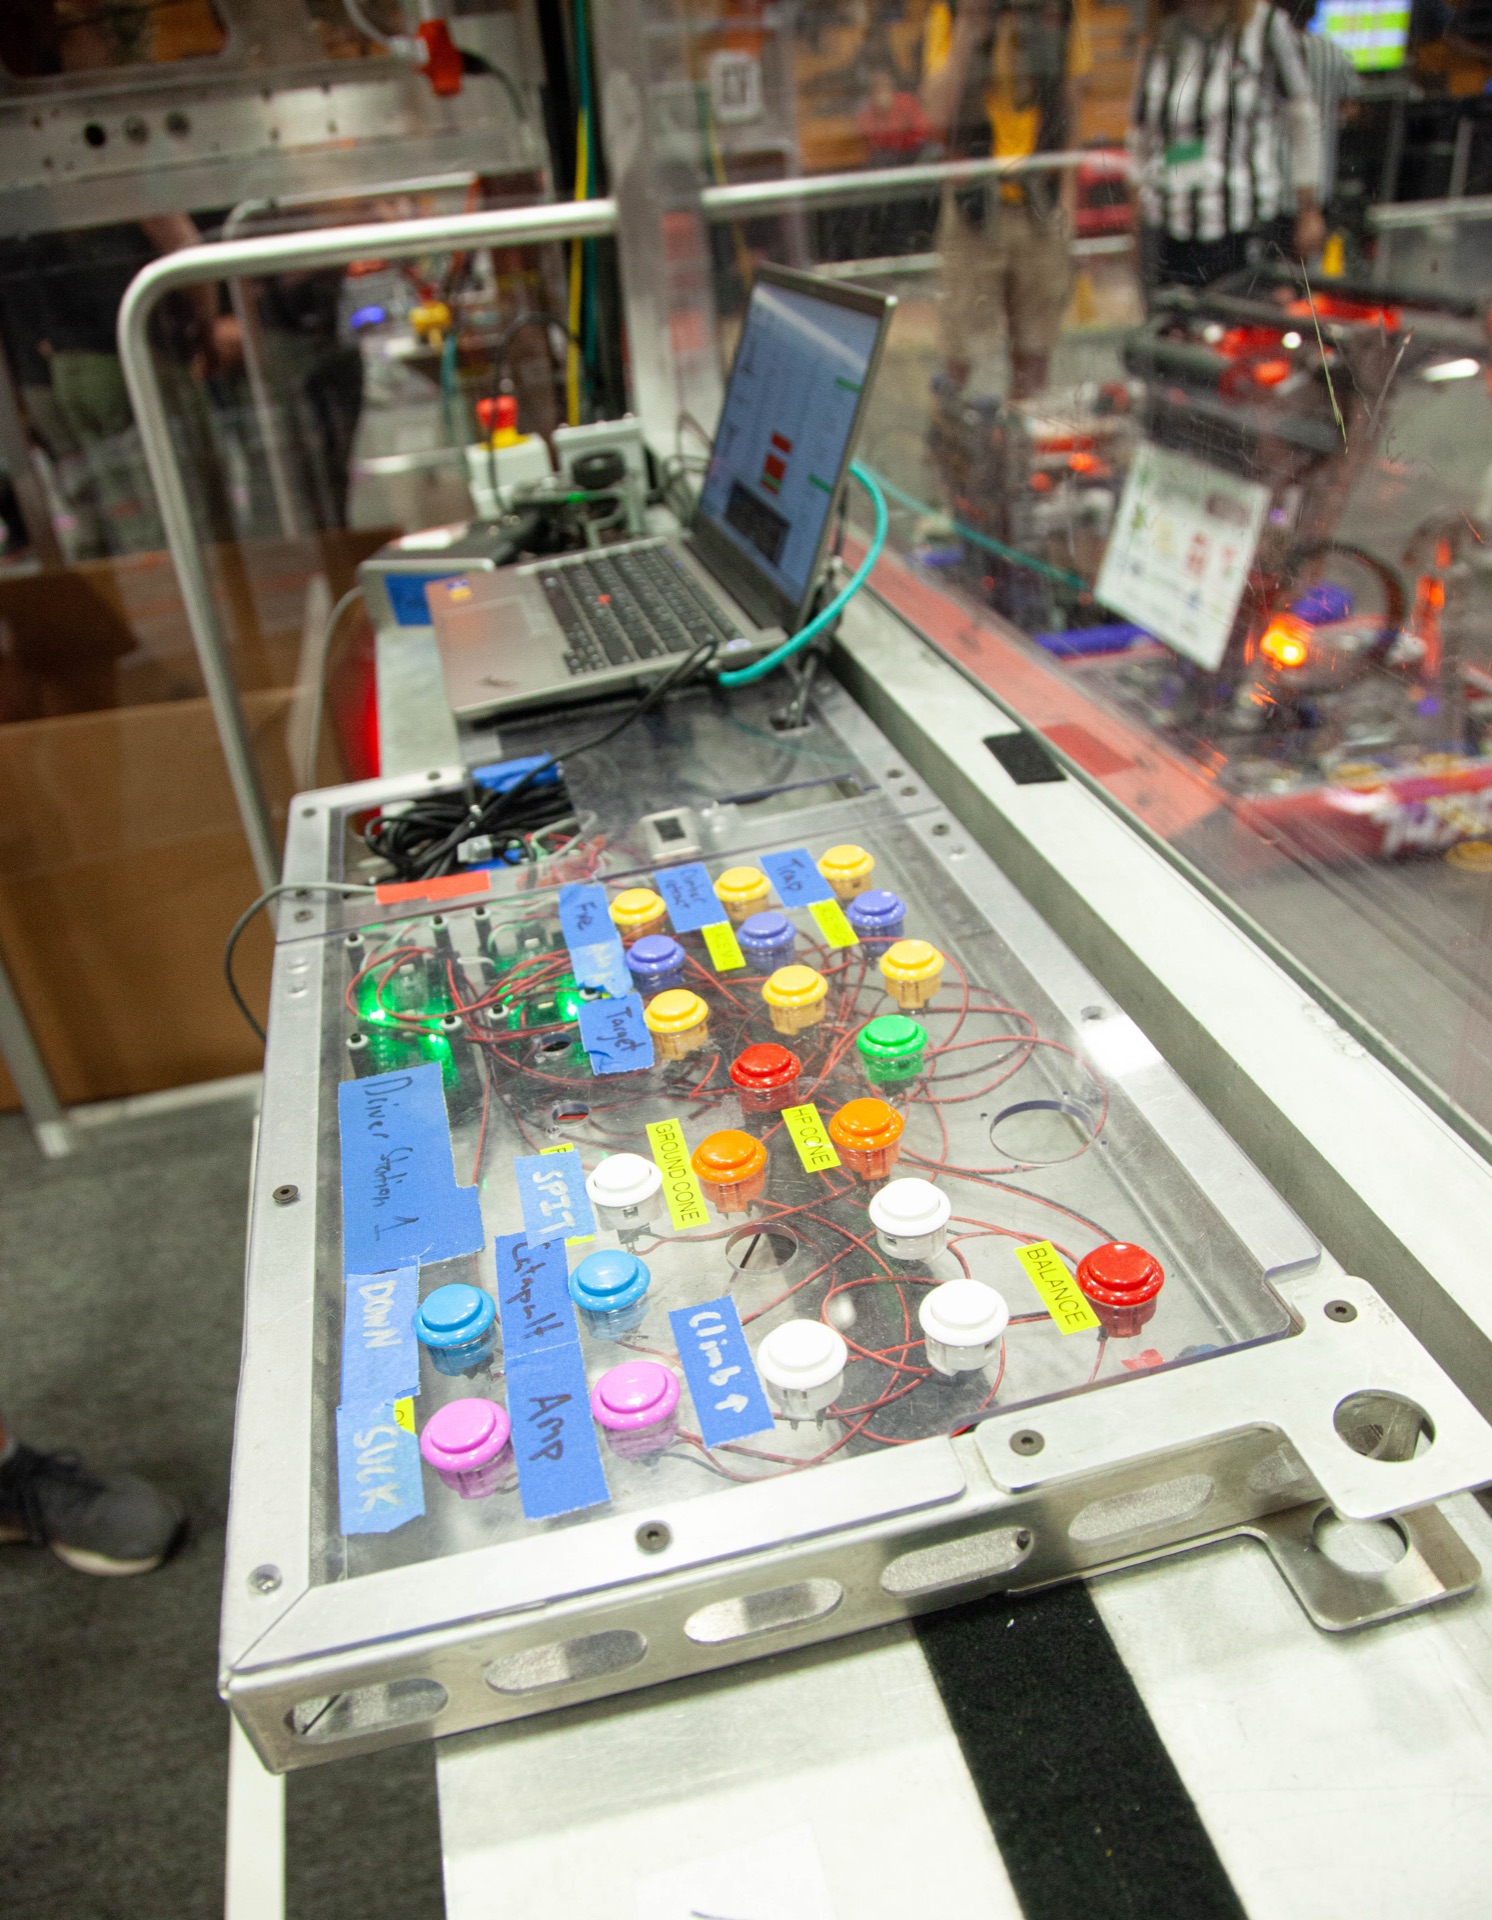
The button board from our driver station. One arcade button for everything the robot can do.
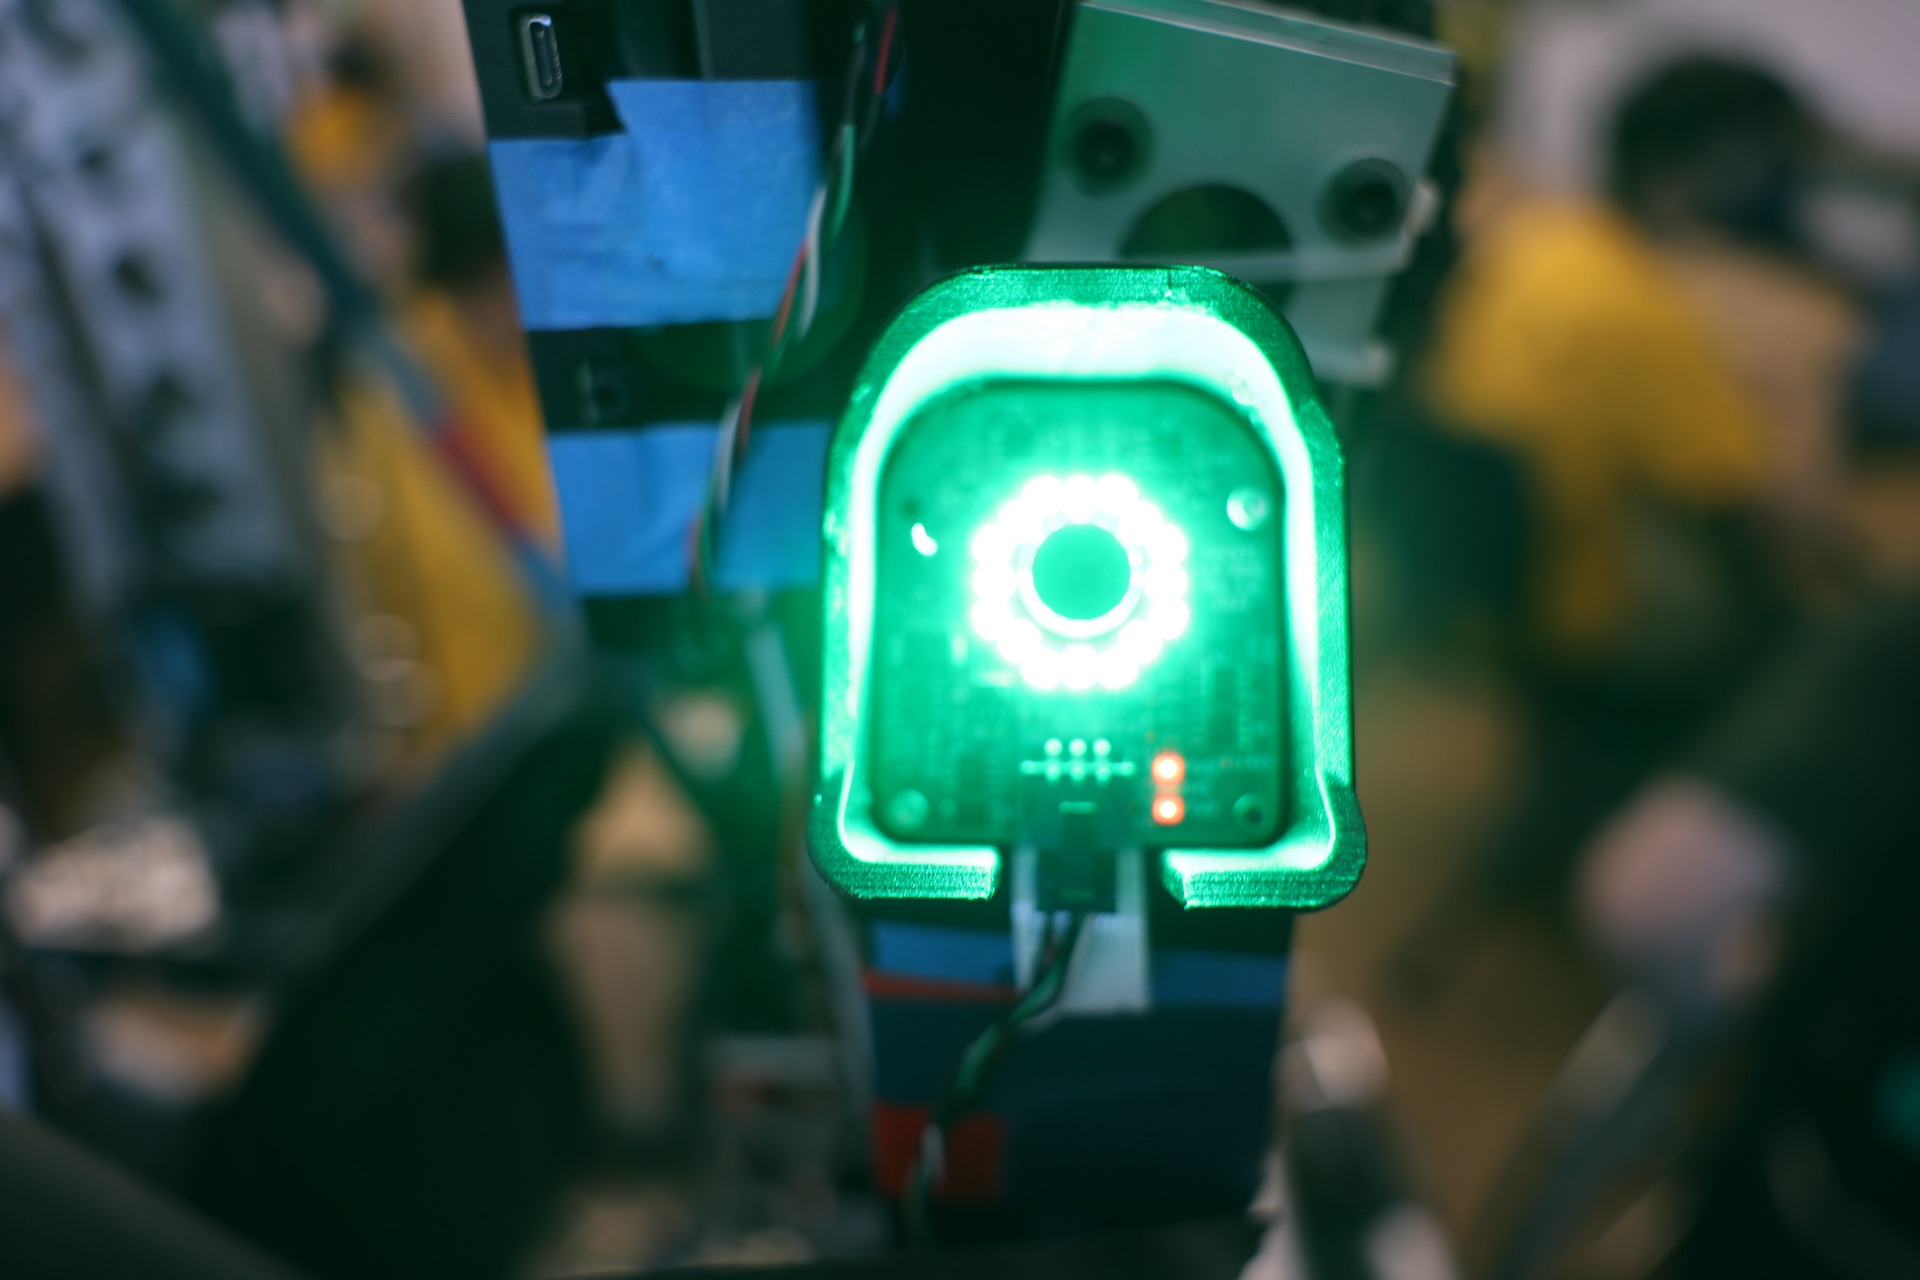
An LED ring board I designed so the cameras could actually see the targets.
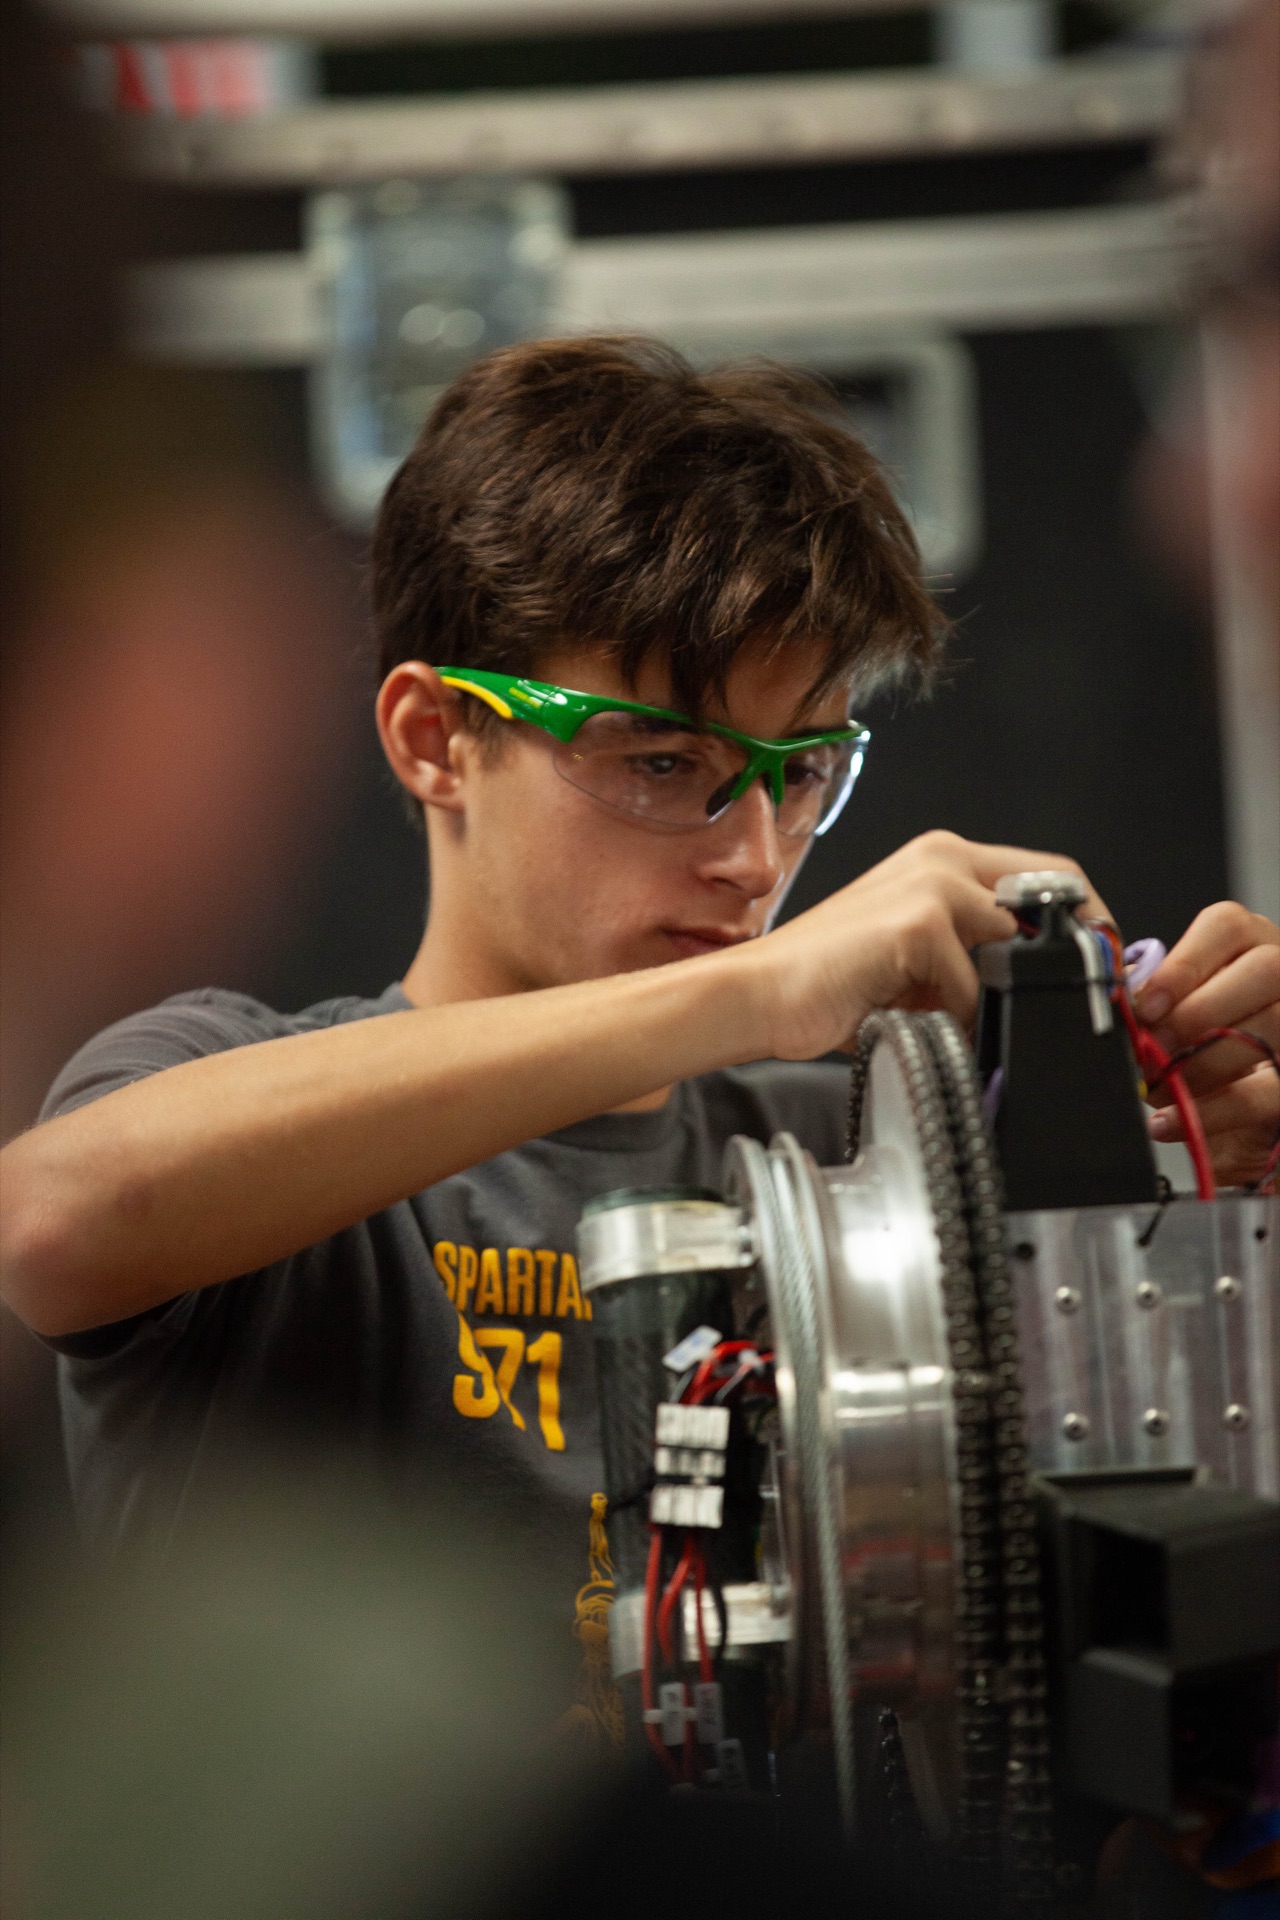
Fixing the arm chain between matches in 2023.
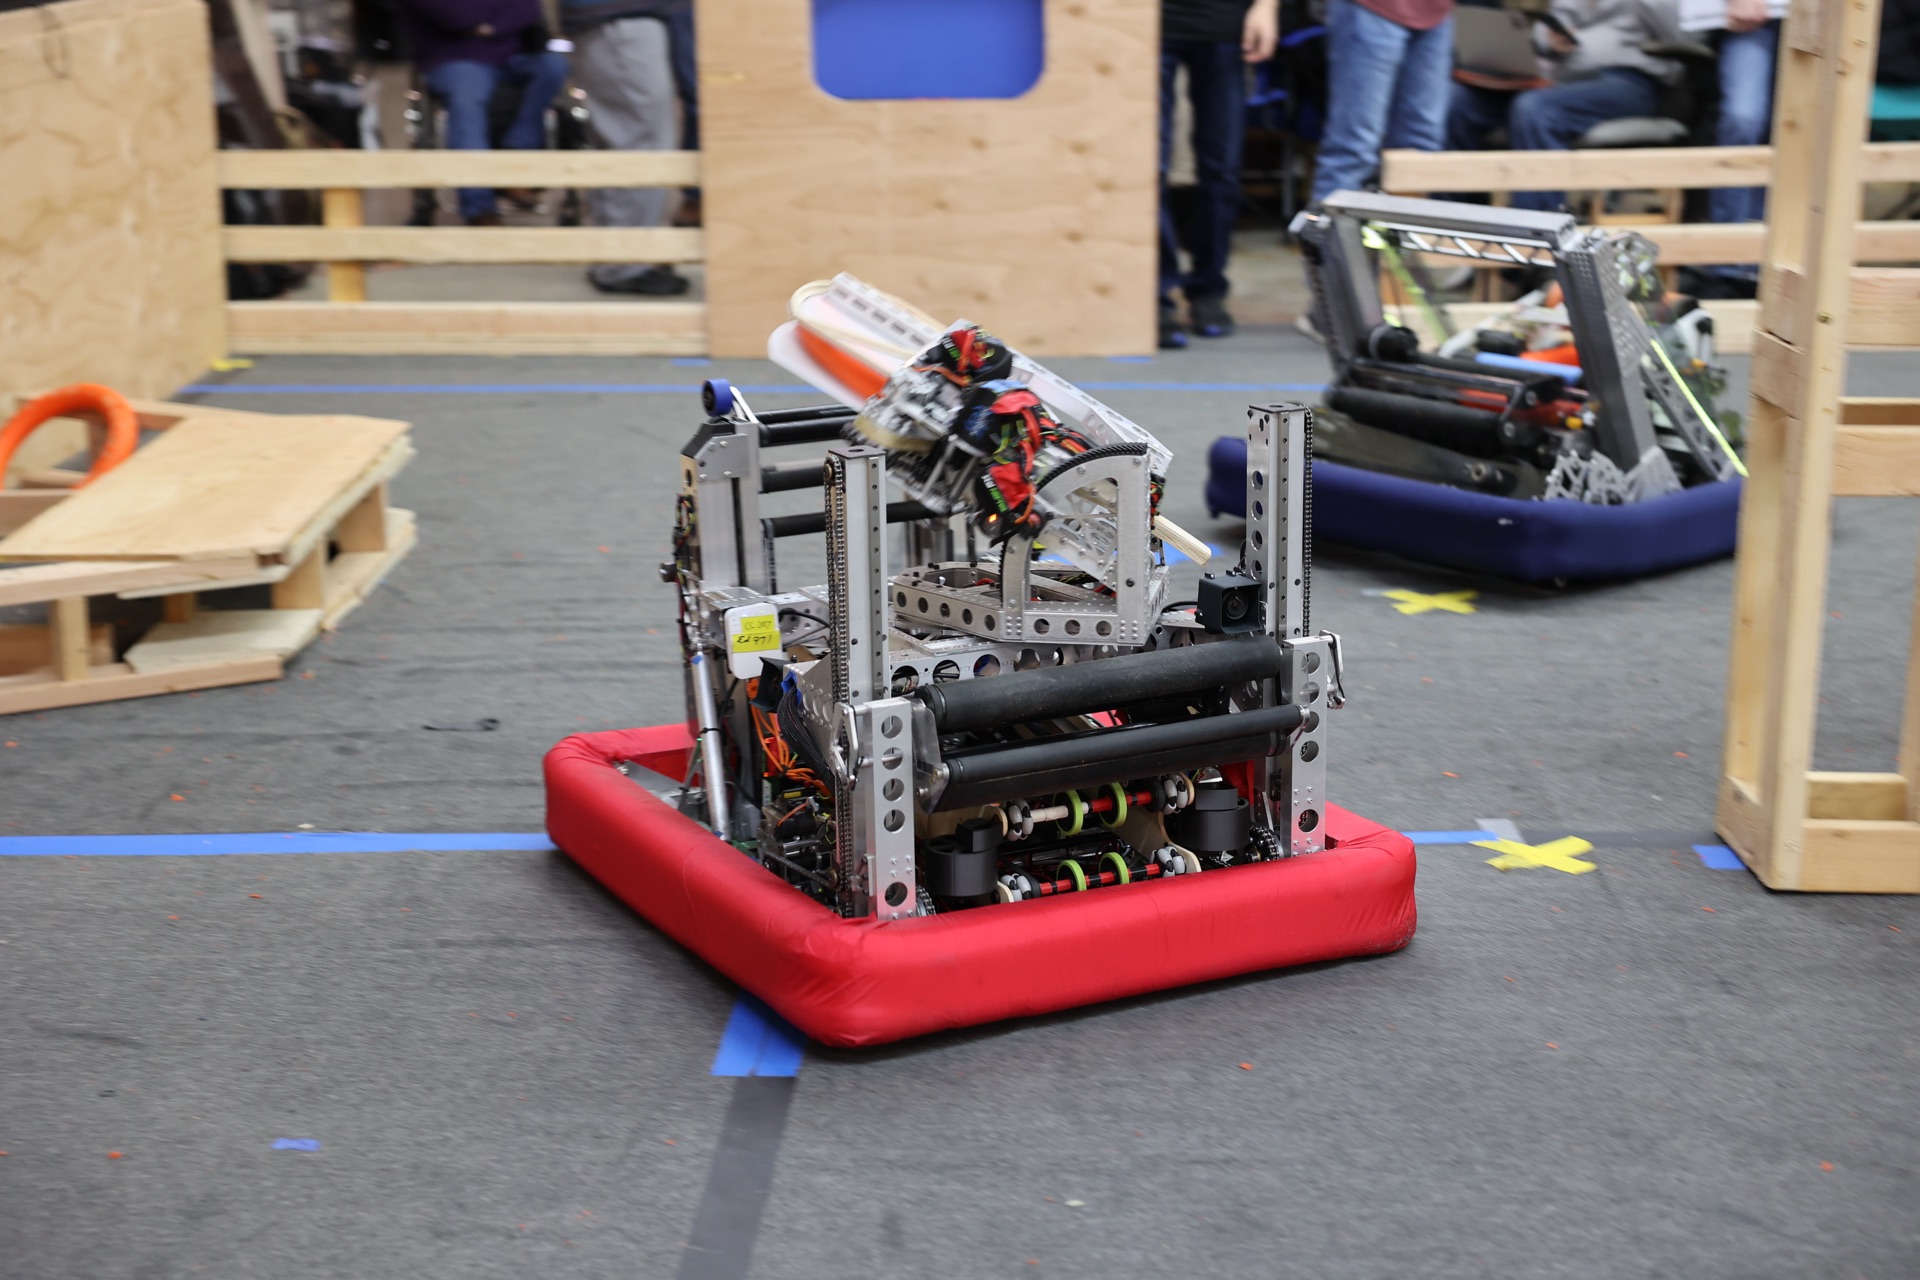
The 2024 robot launching a ring mid-match.
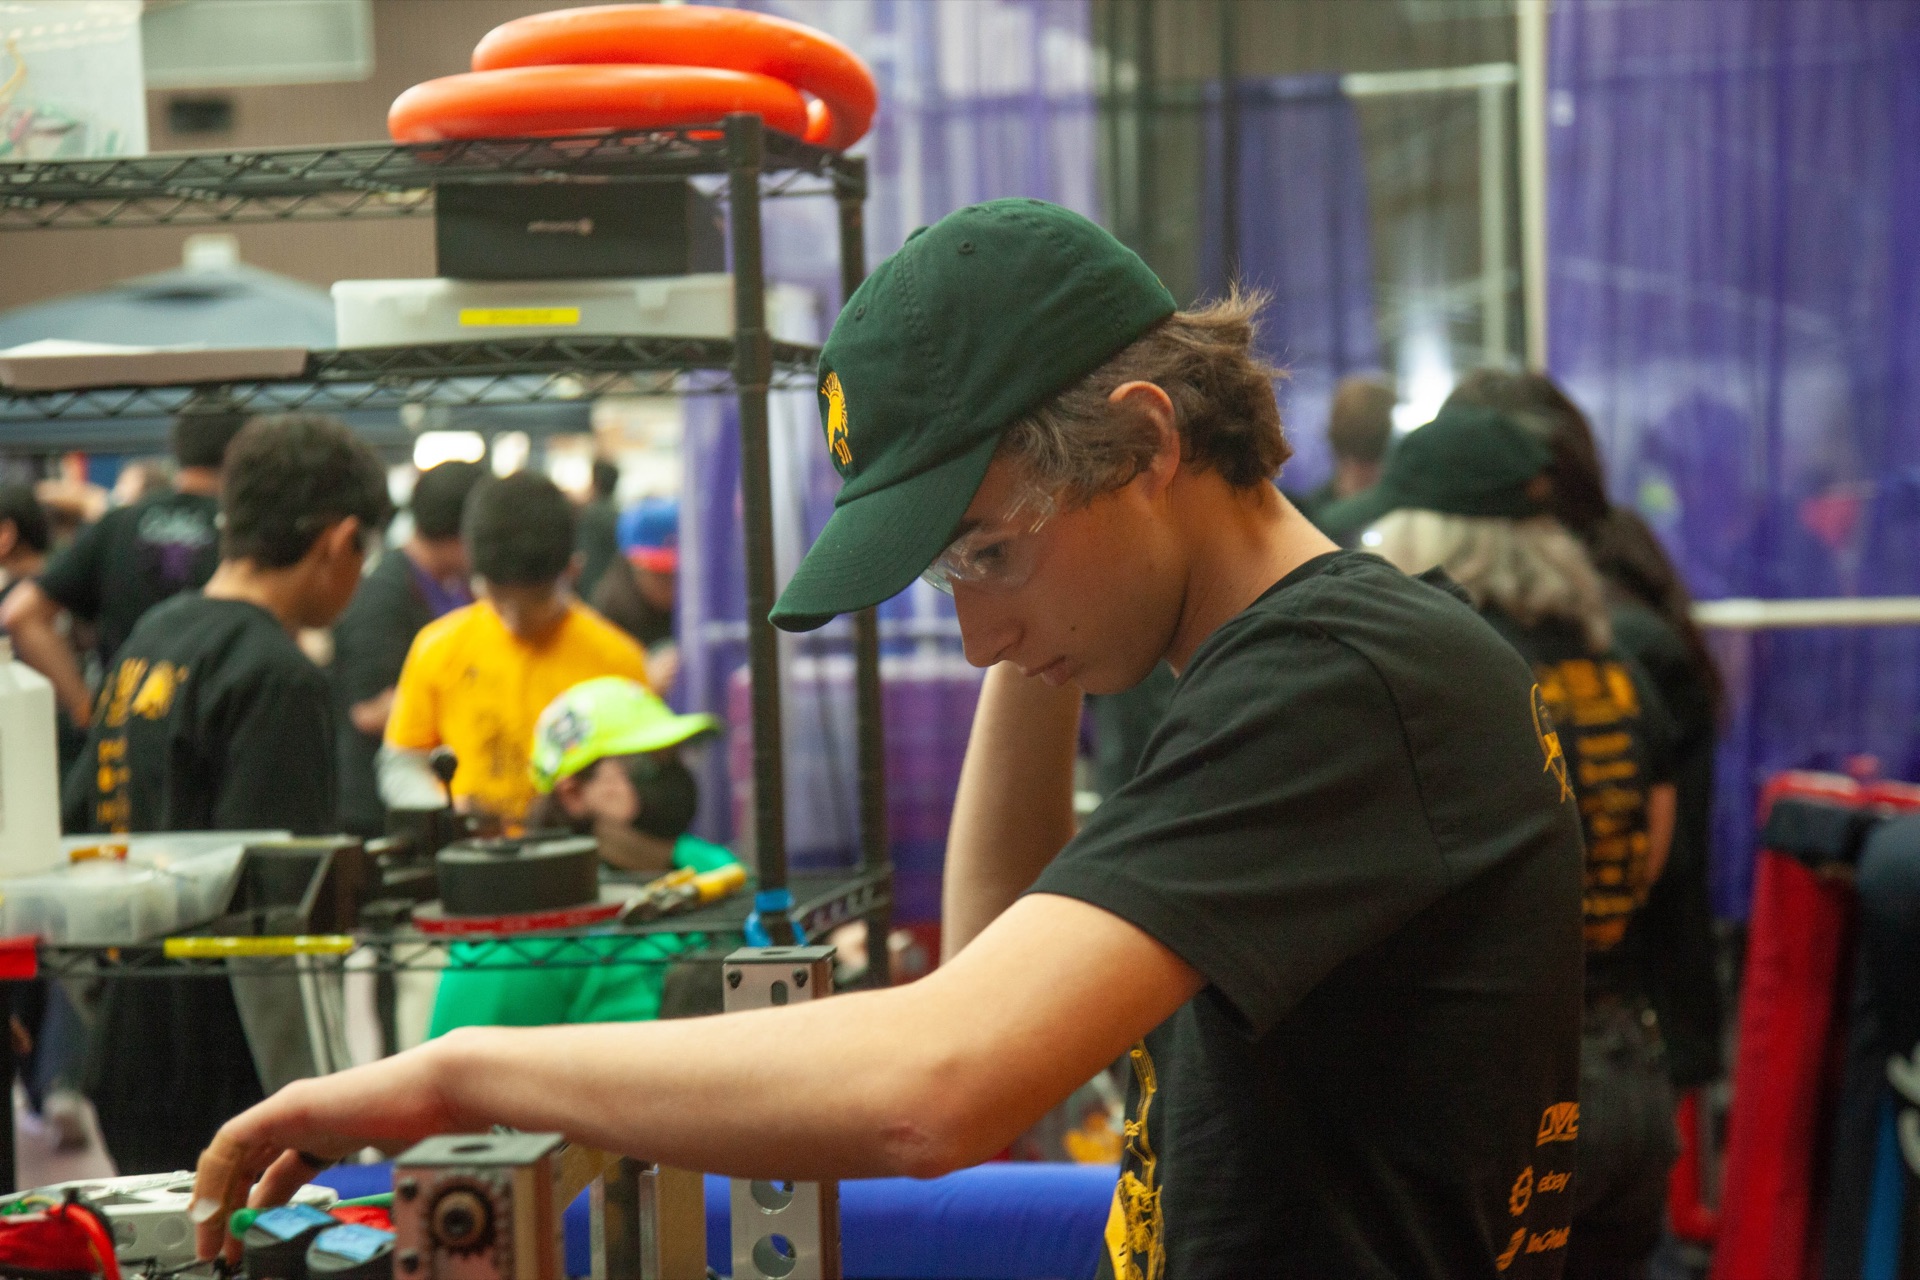
Running the pre match checklist in the pit and staring down something suspicious.
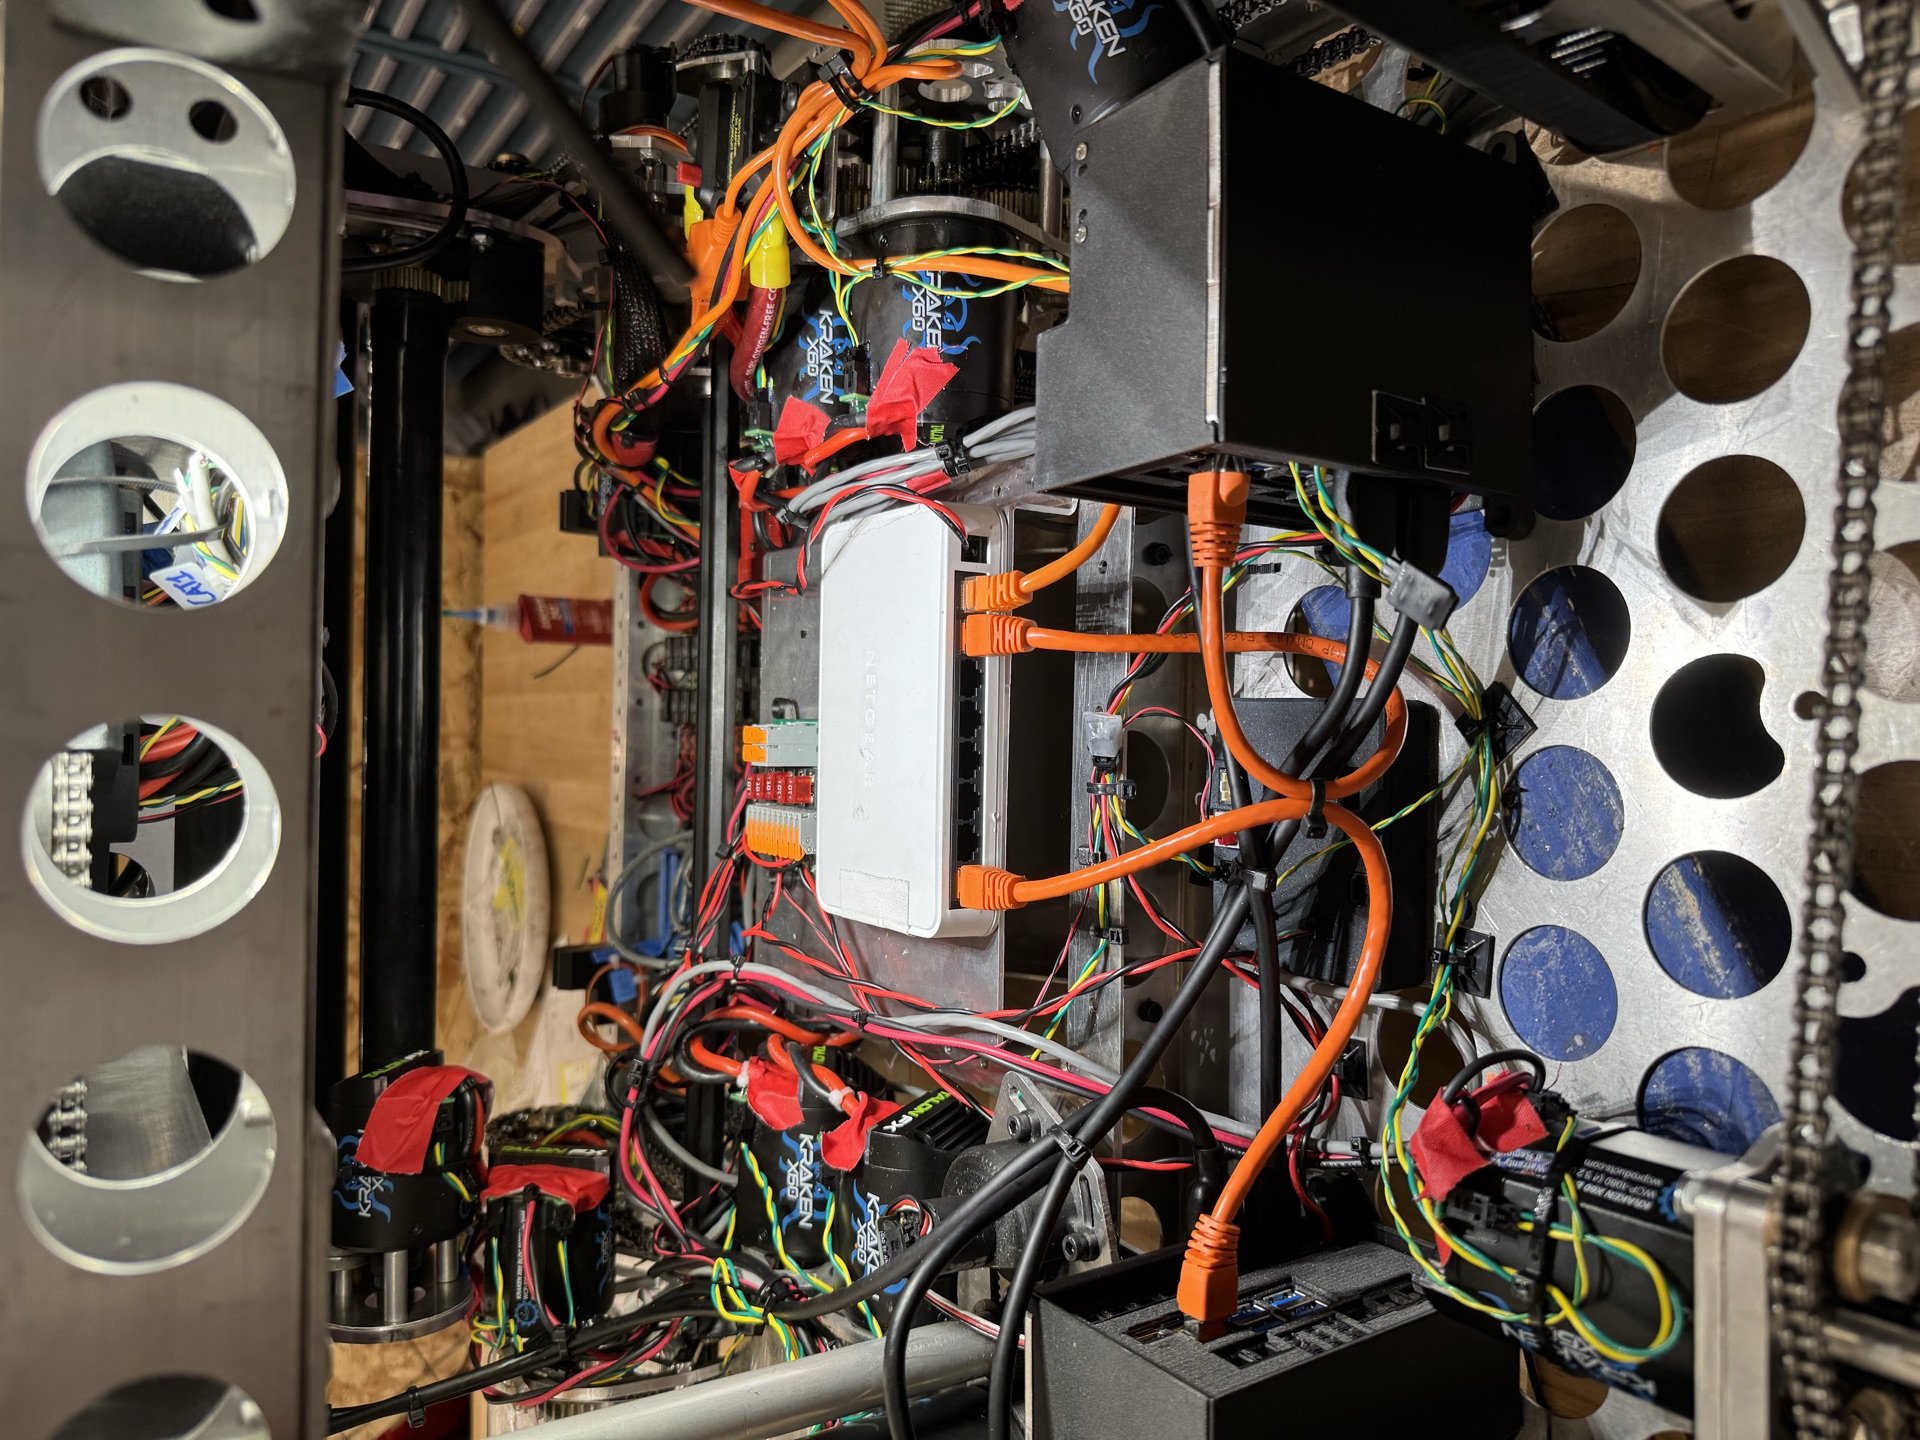
Inside the 2024 robot mid wiring. Organized chaos.
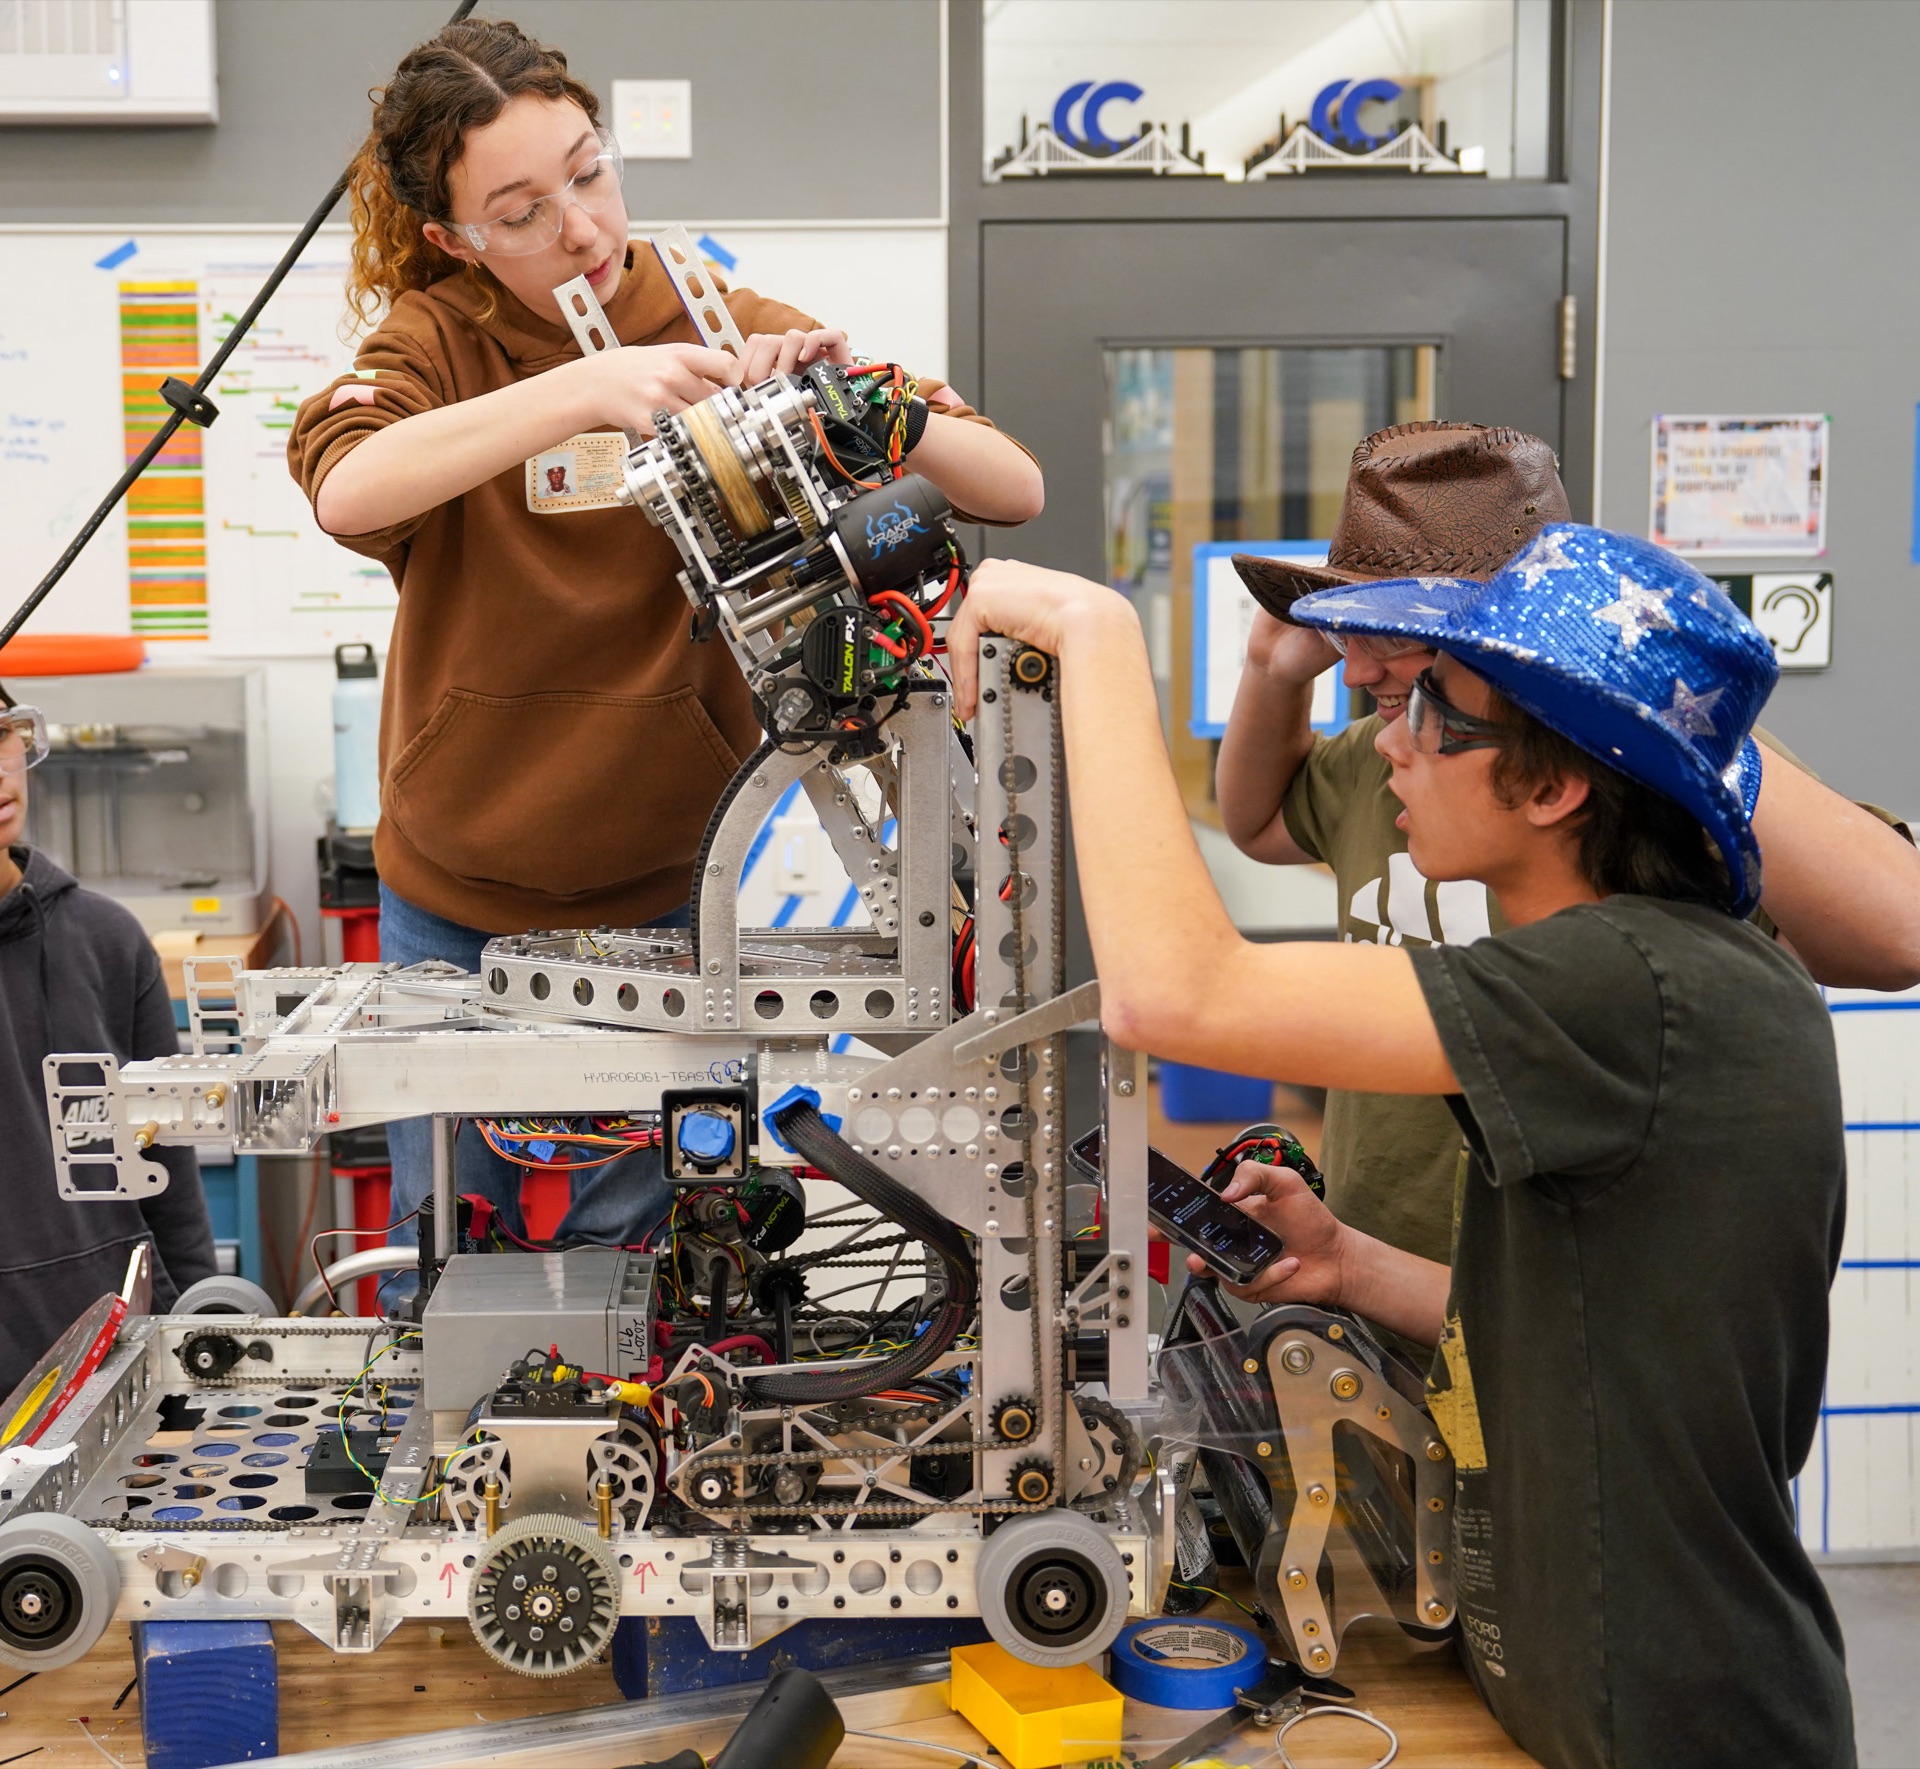
Building the 2024 shooter. Cowboy hats required.
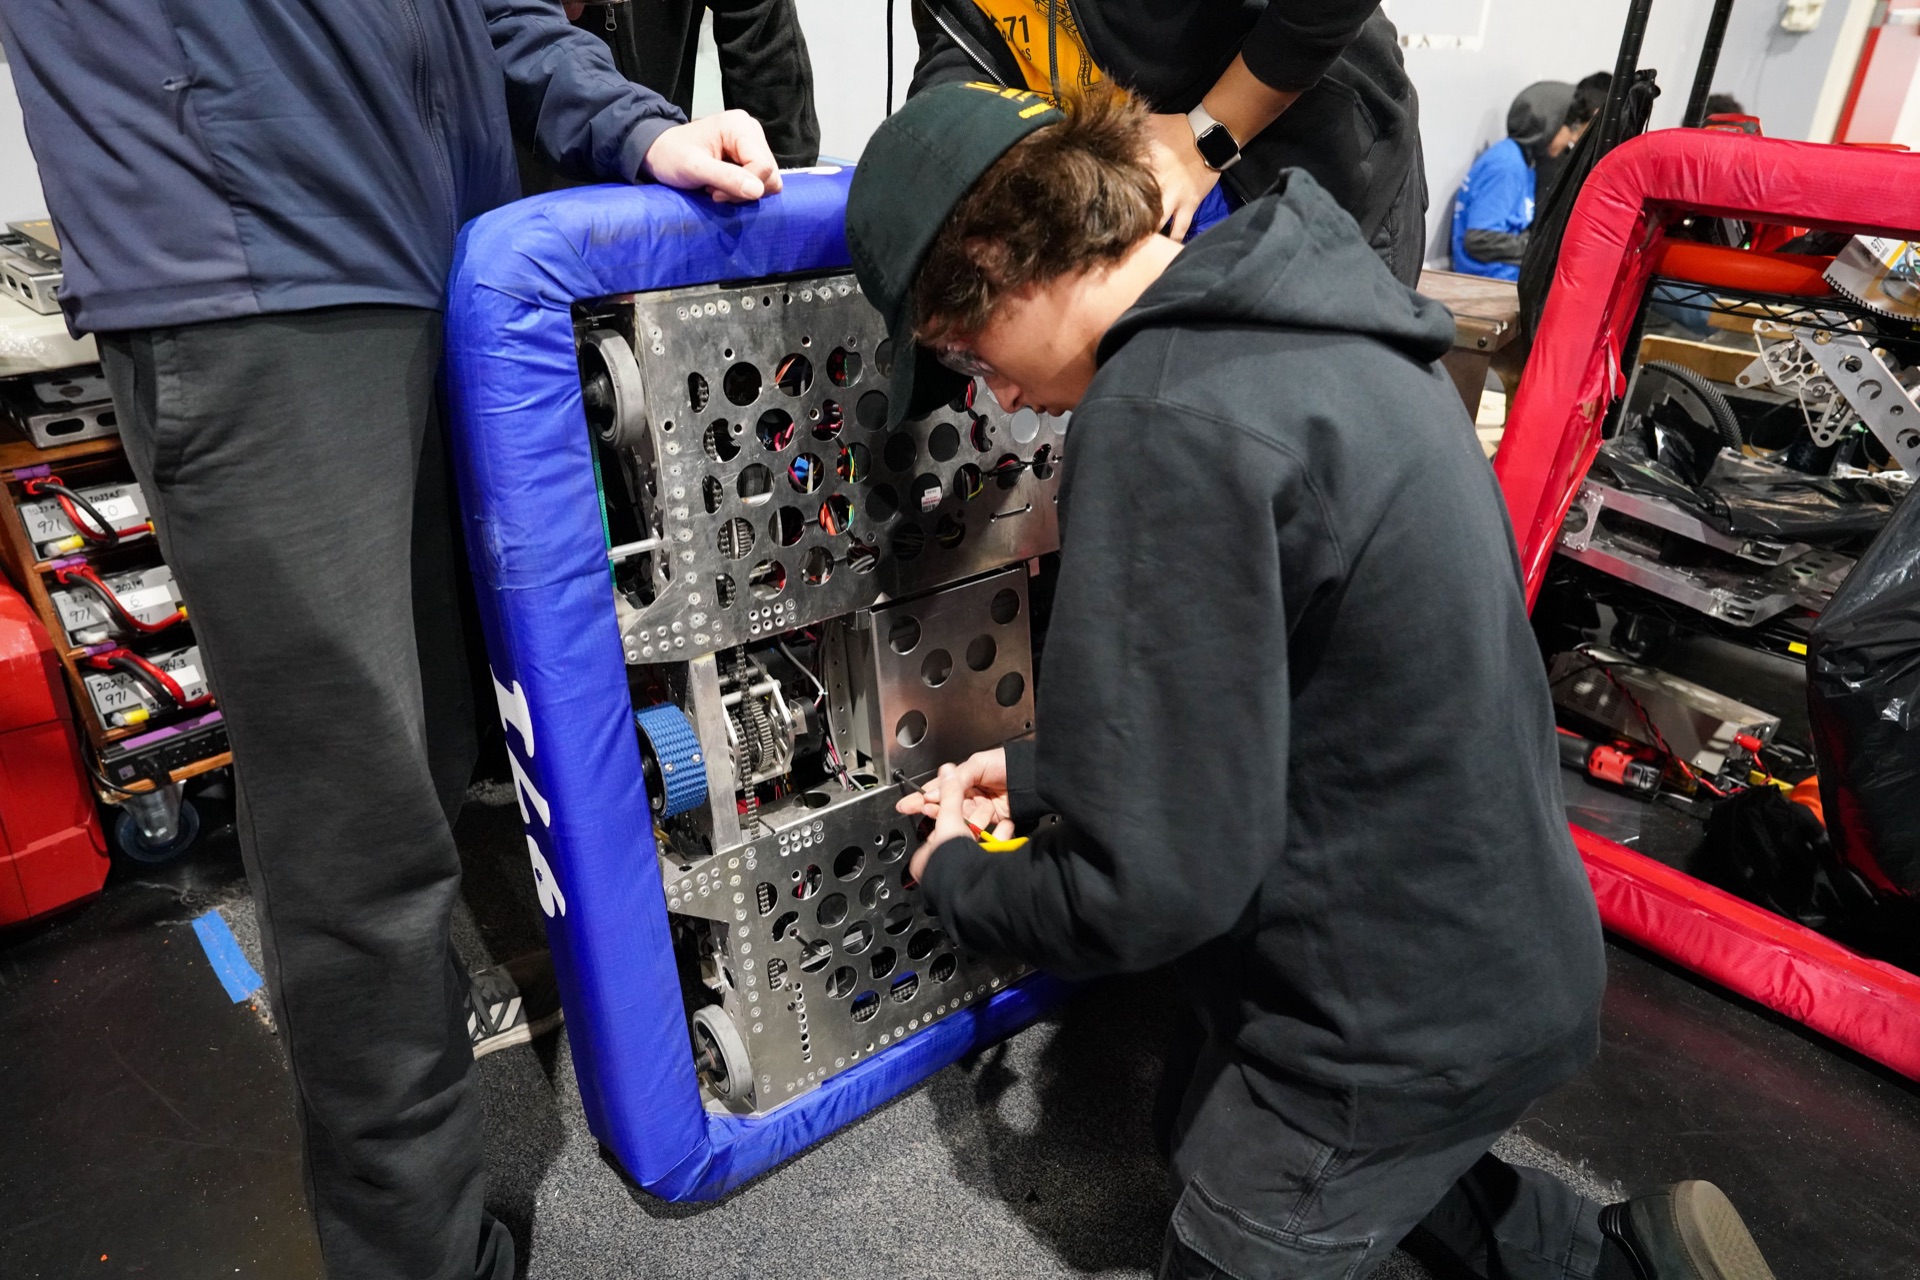
Swapping the battery between matches, pit crew style.
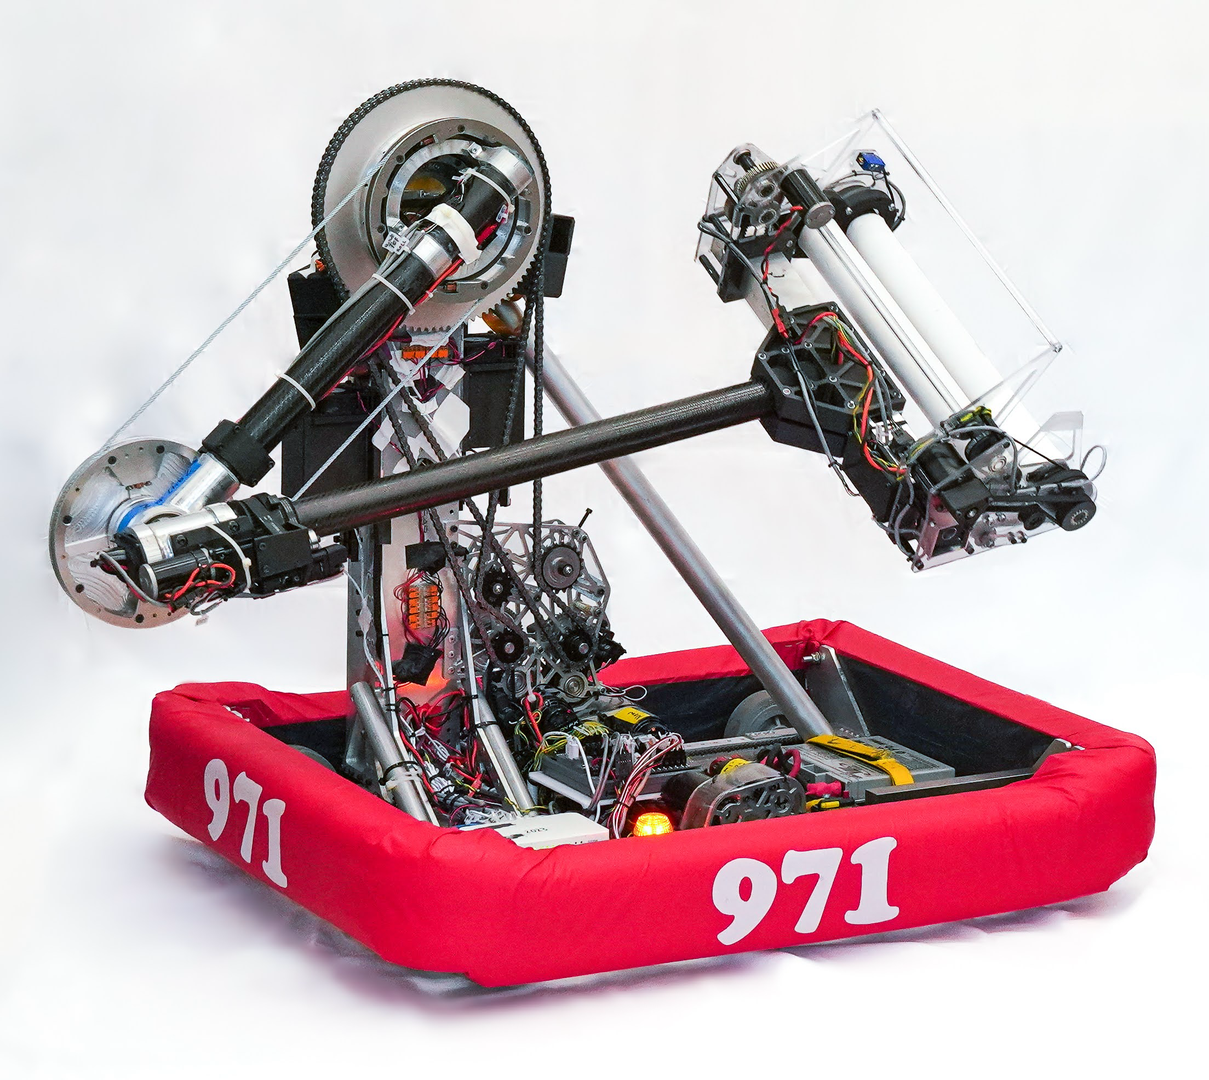
Final competition robot, equipped with all custom electronics.
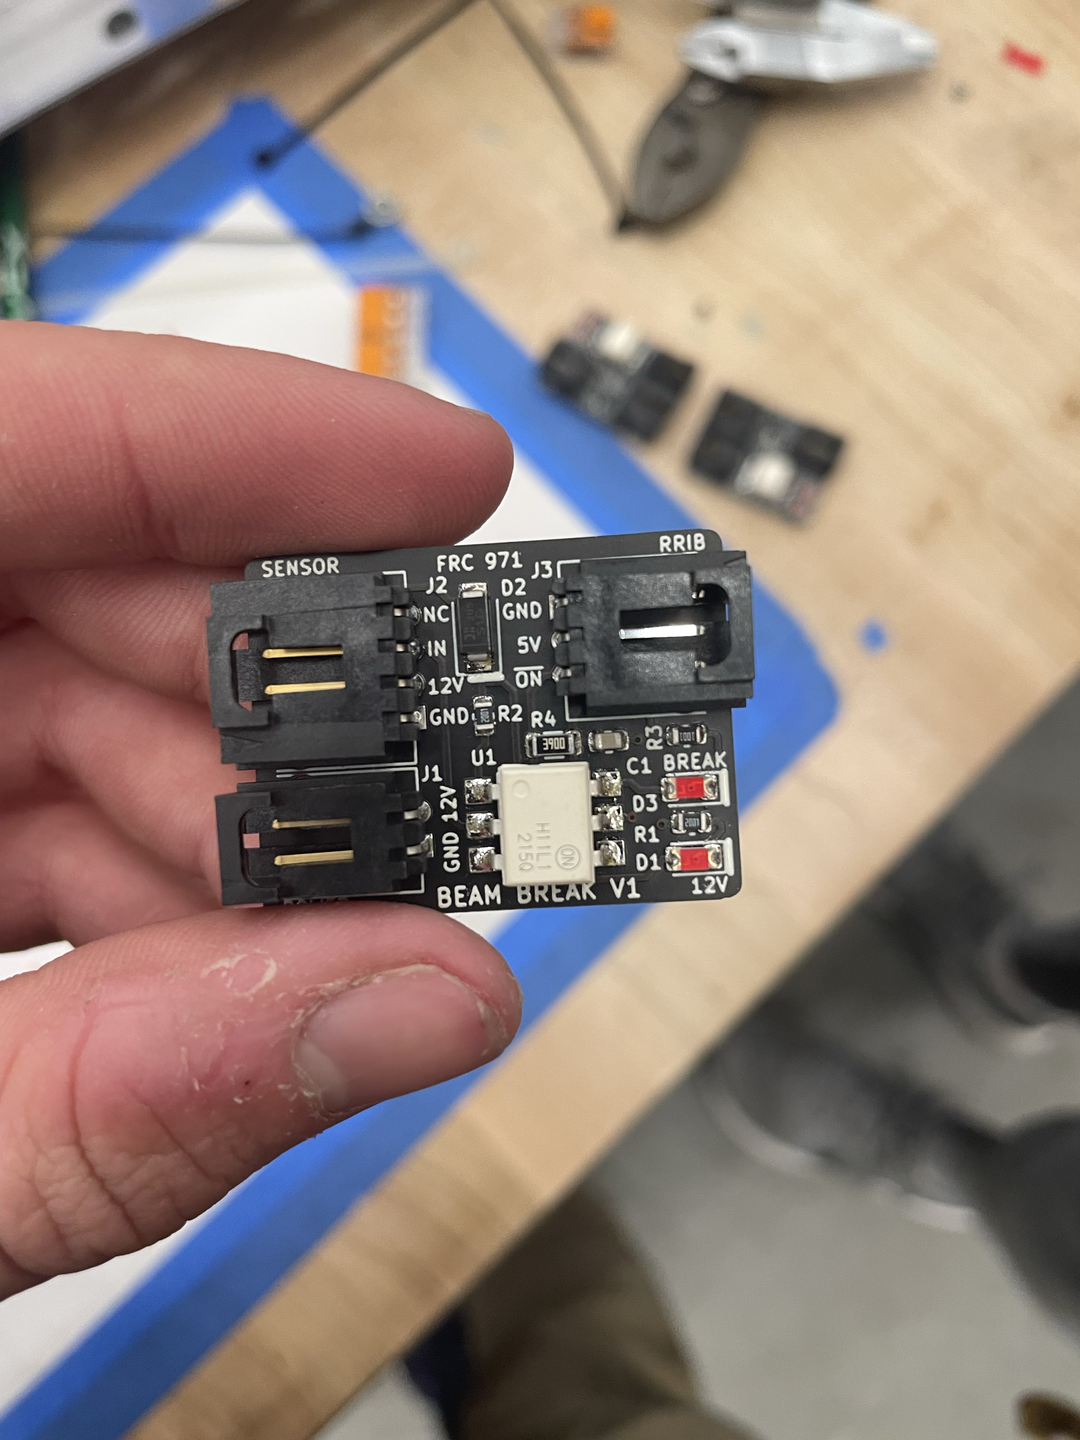
Beam break sensor circuit for object detection.
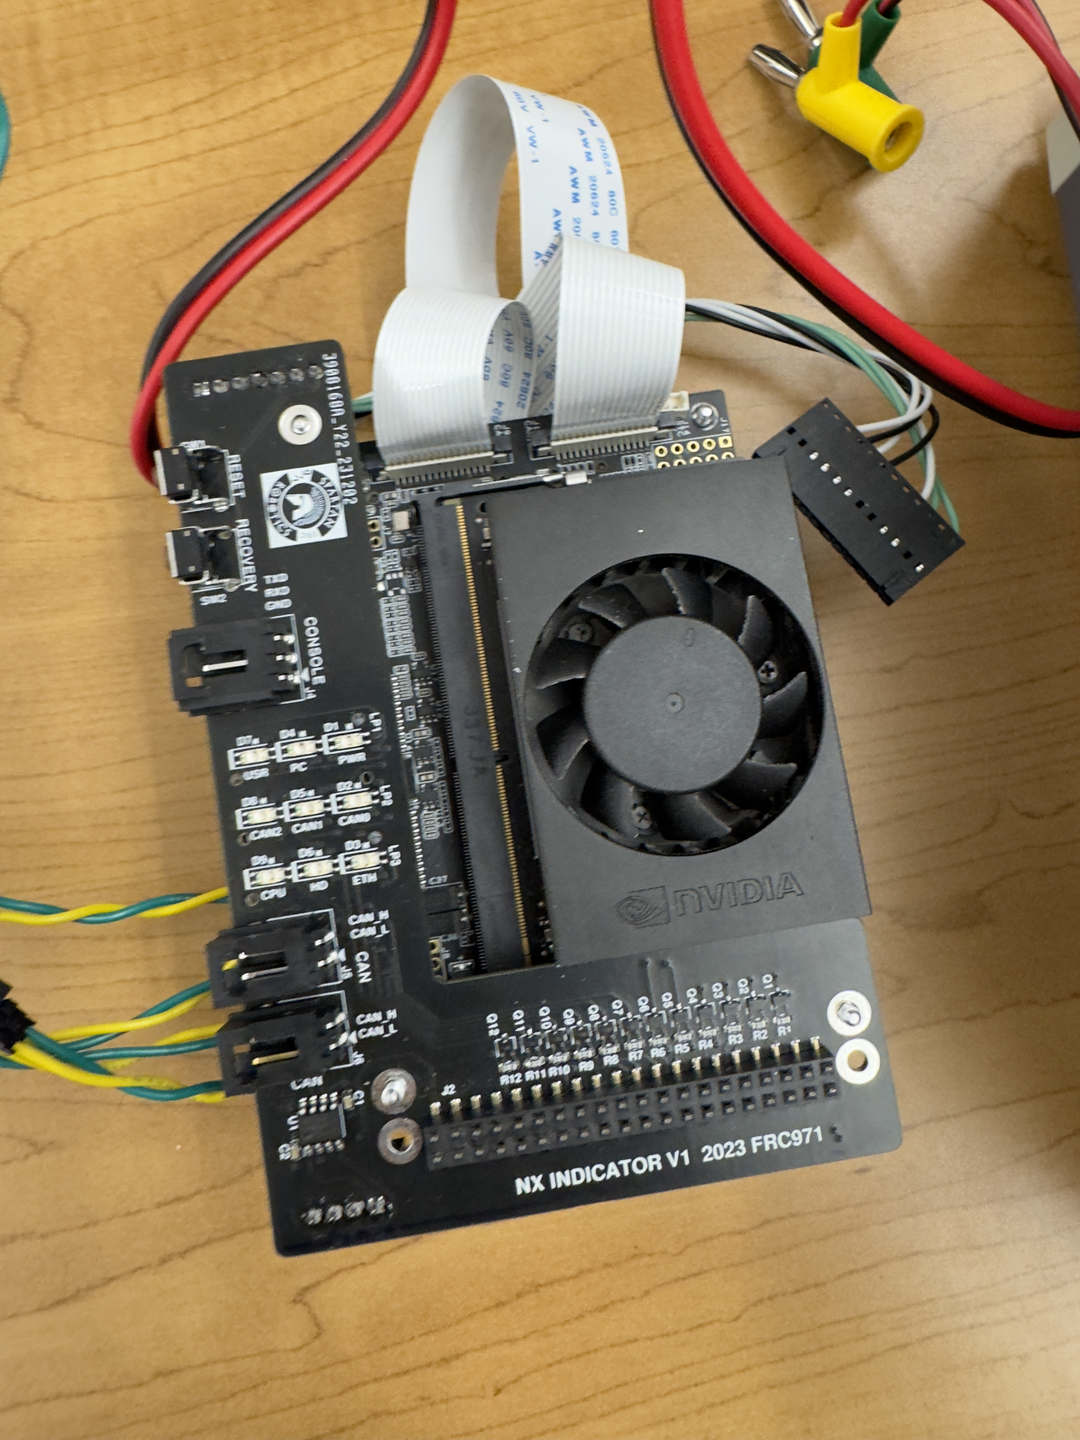
Jetson Orin NX computing module wired and assembled.
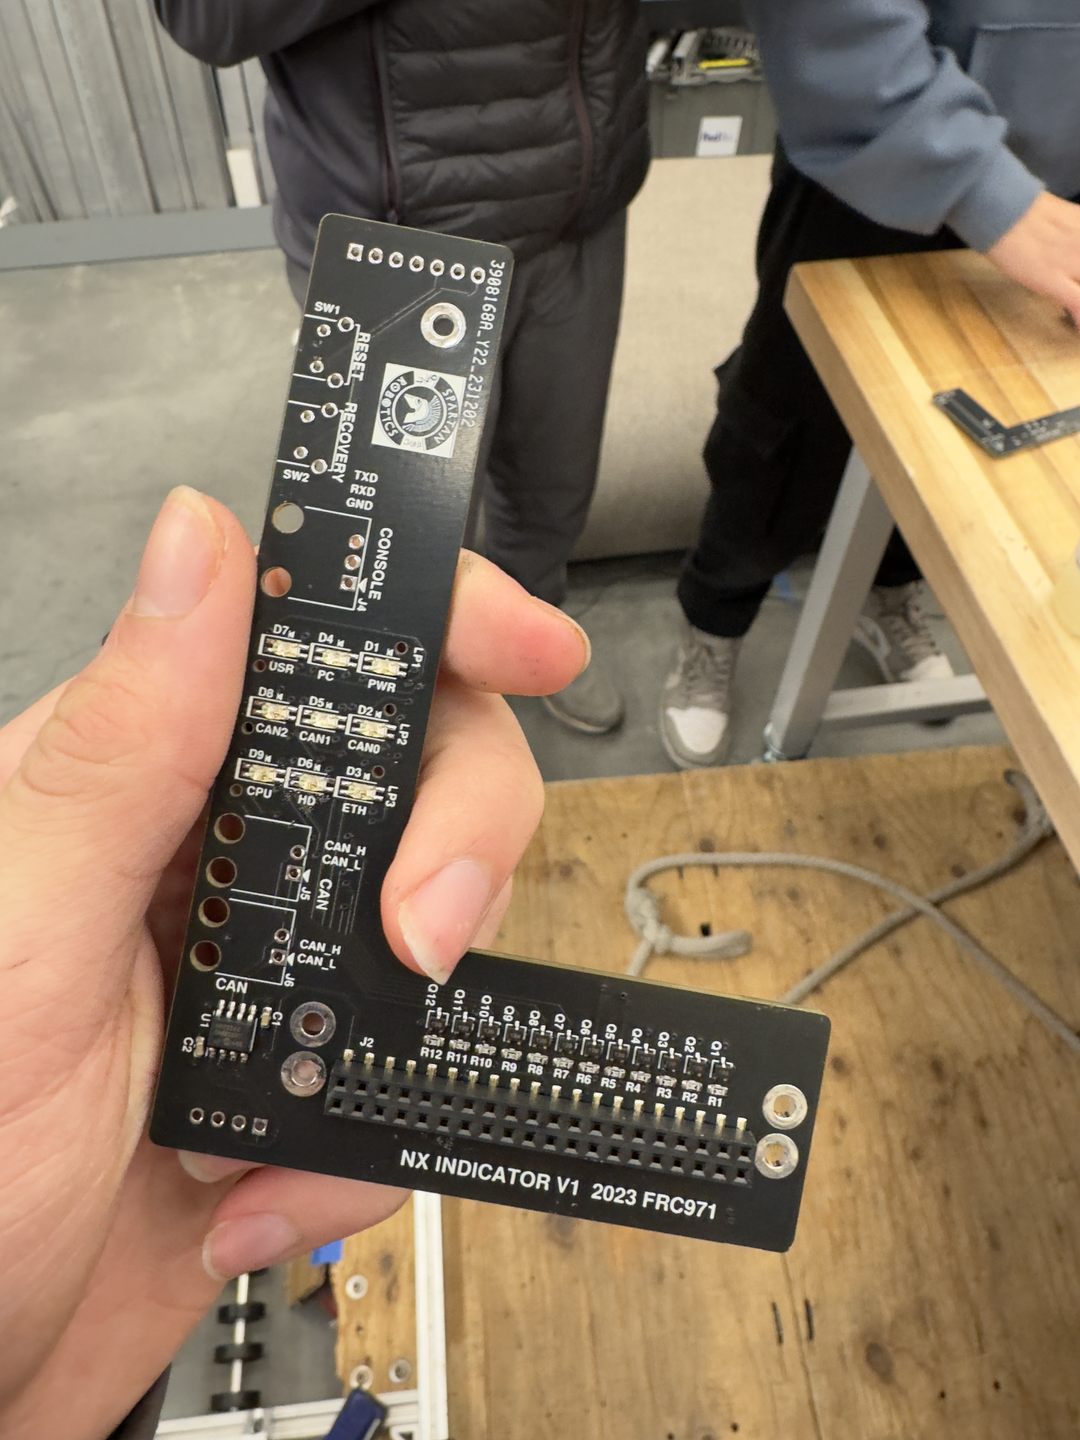
Adapter board for integrating the Jetson Orin NX with robot systems.
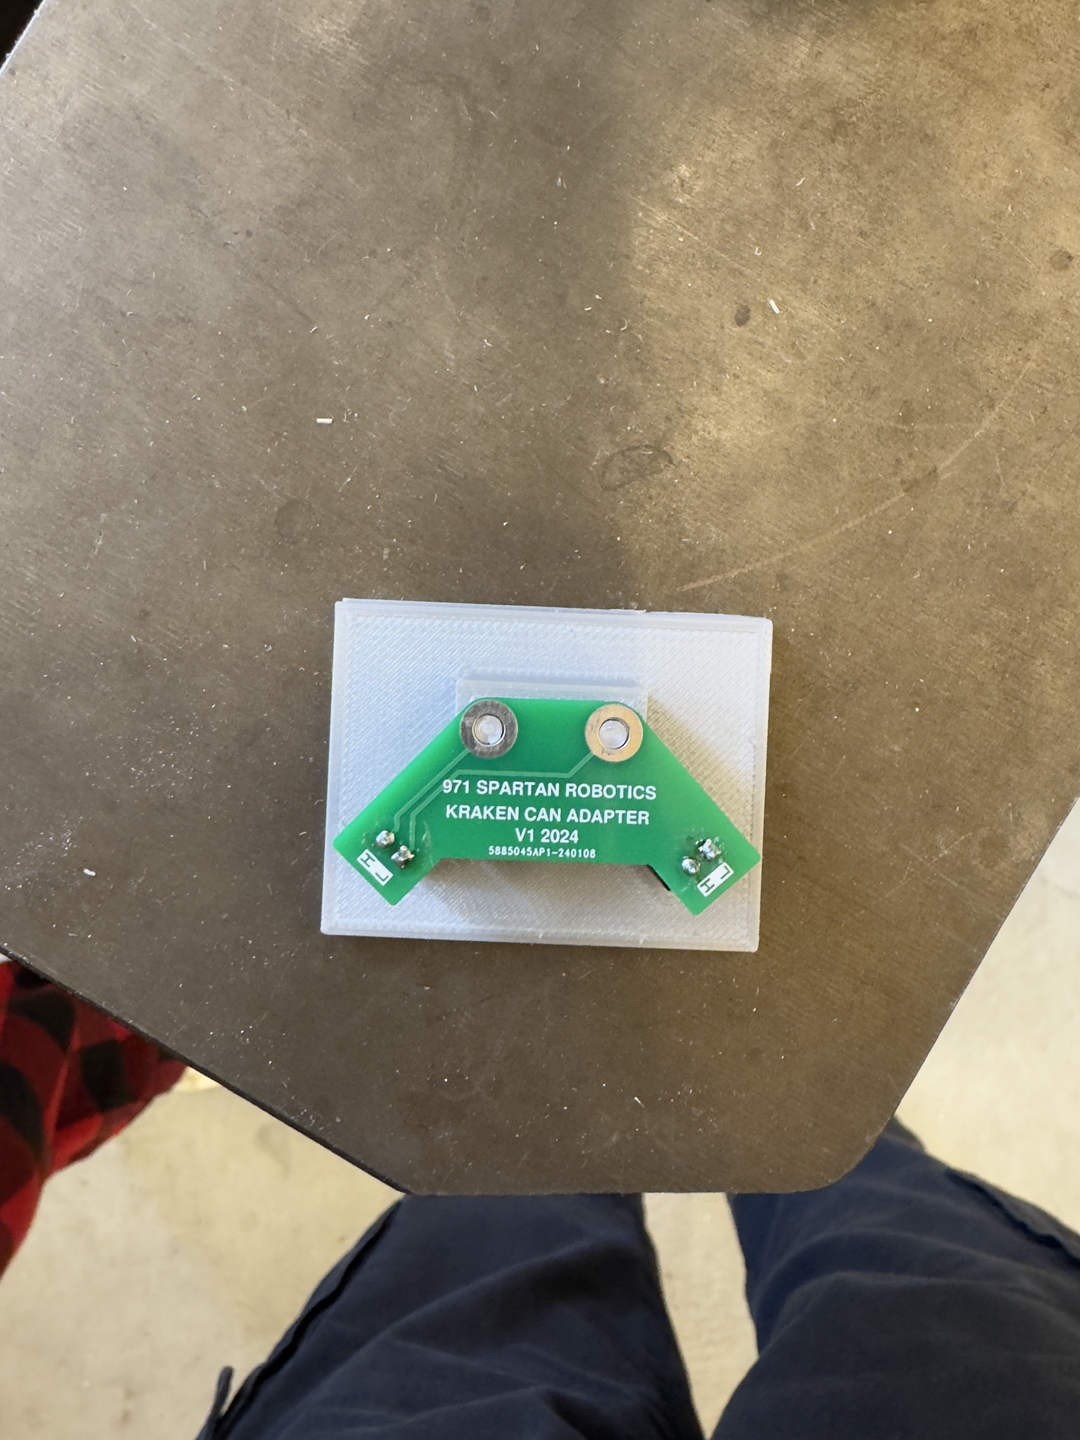
CAN motor controller adapter for improved signal integrity.
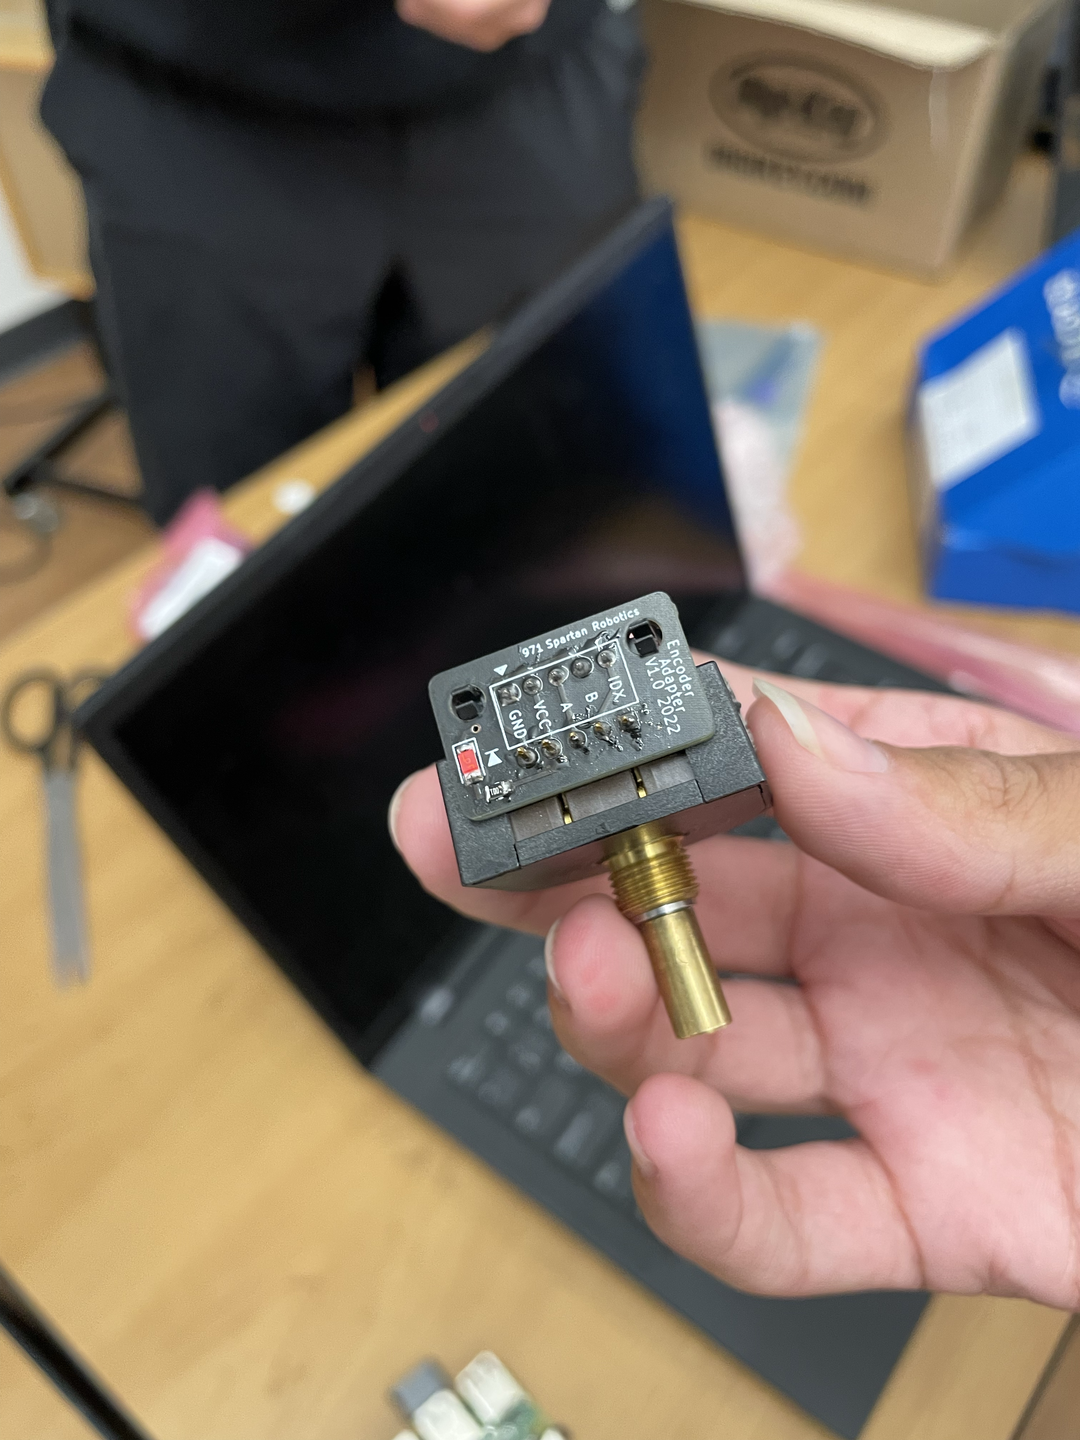
Optical encoder adapter for precision motor feedback.
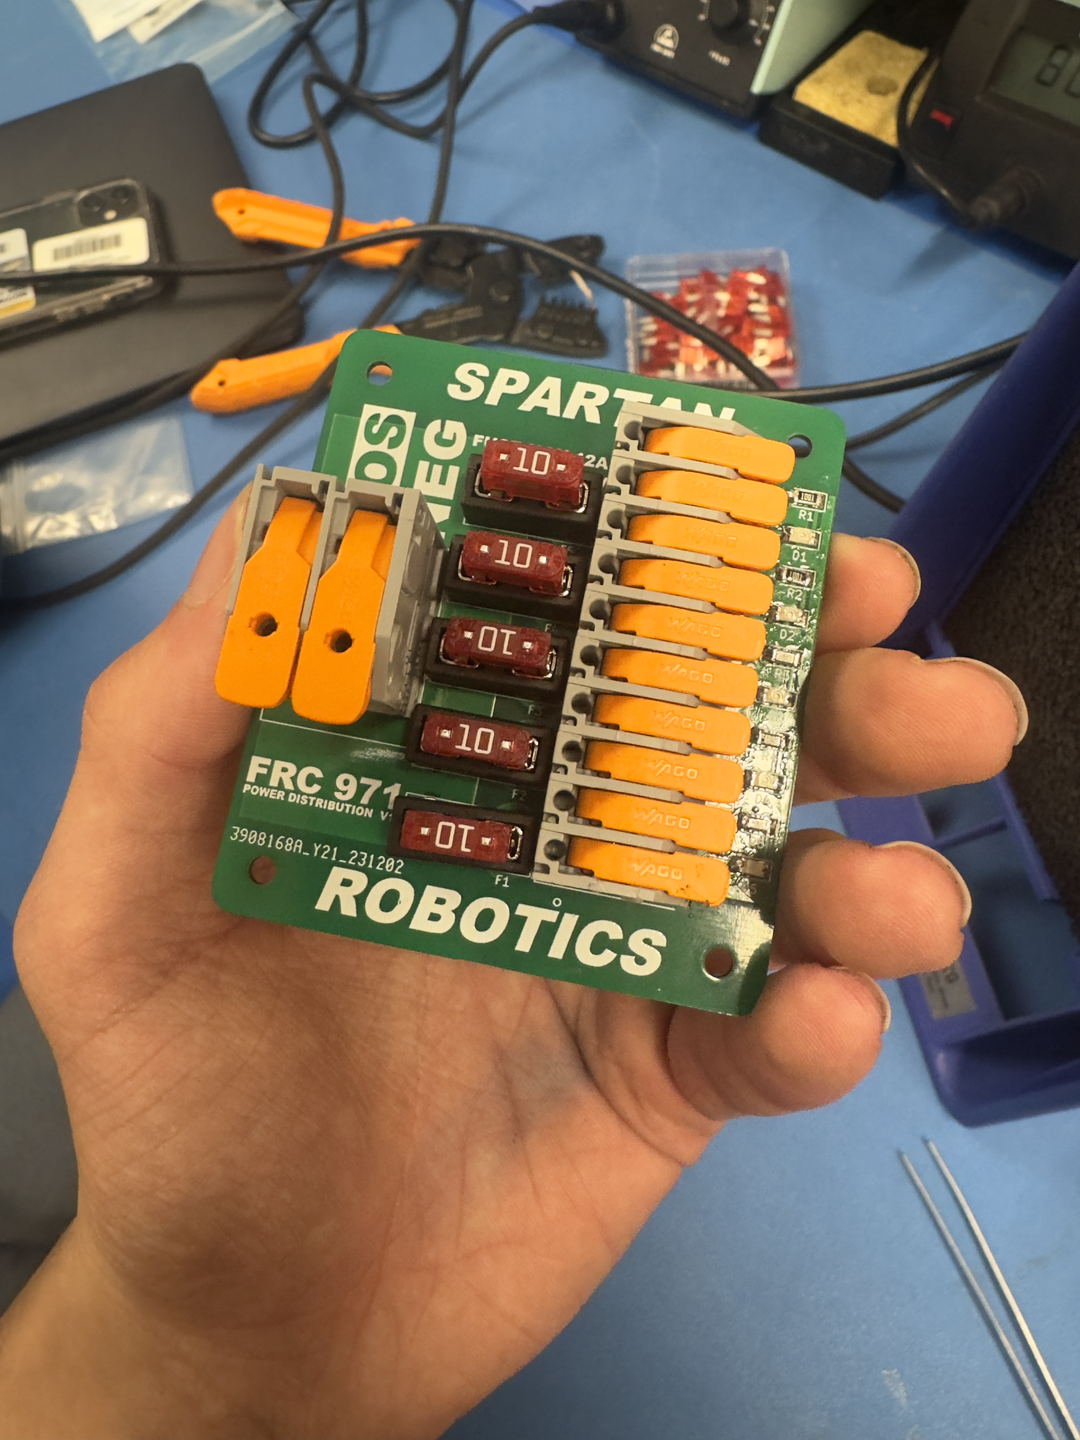
Custom power adapter for sensor and motor connections.
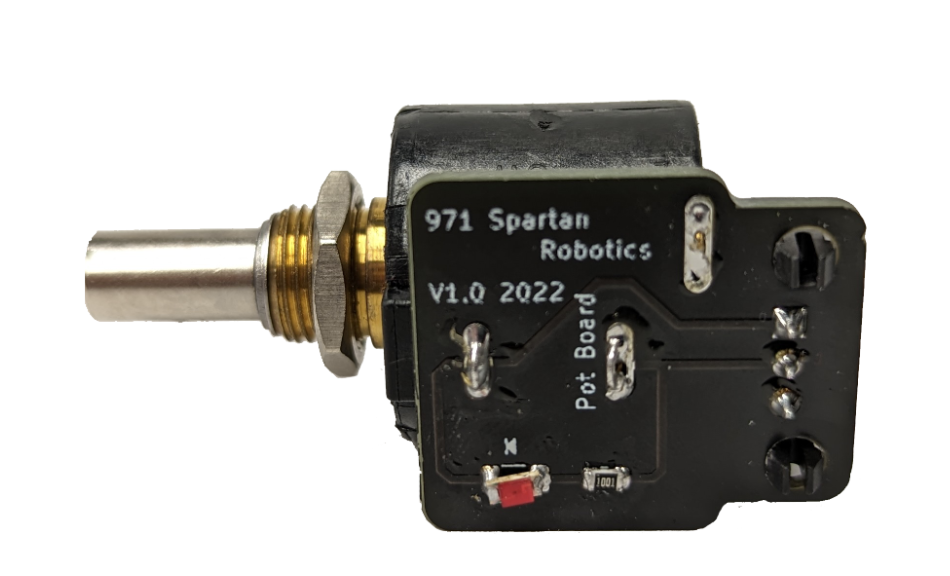
Potentiometer breakout board for analog feedback.
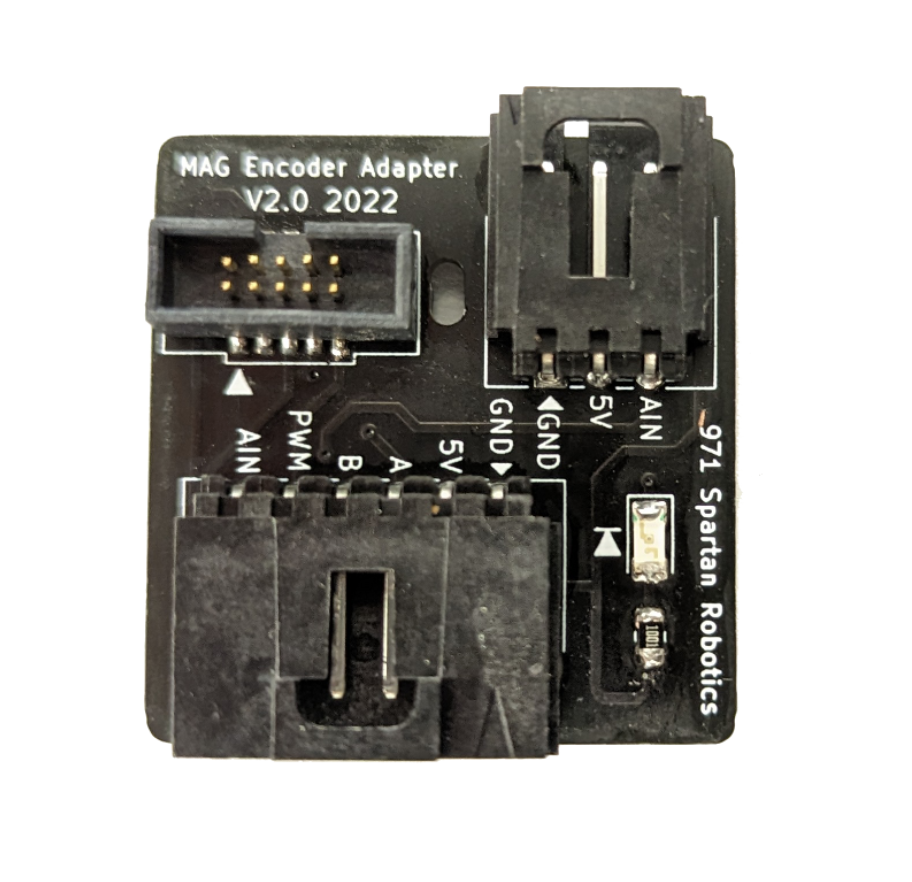
Magnetic encoder board for precise motor control.
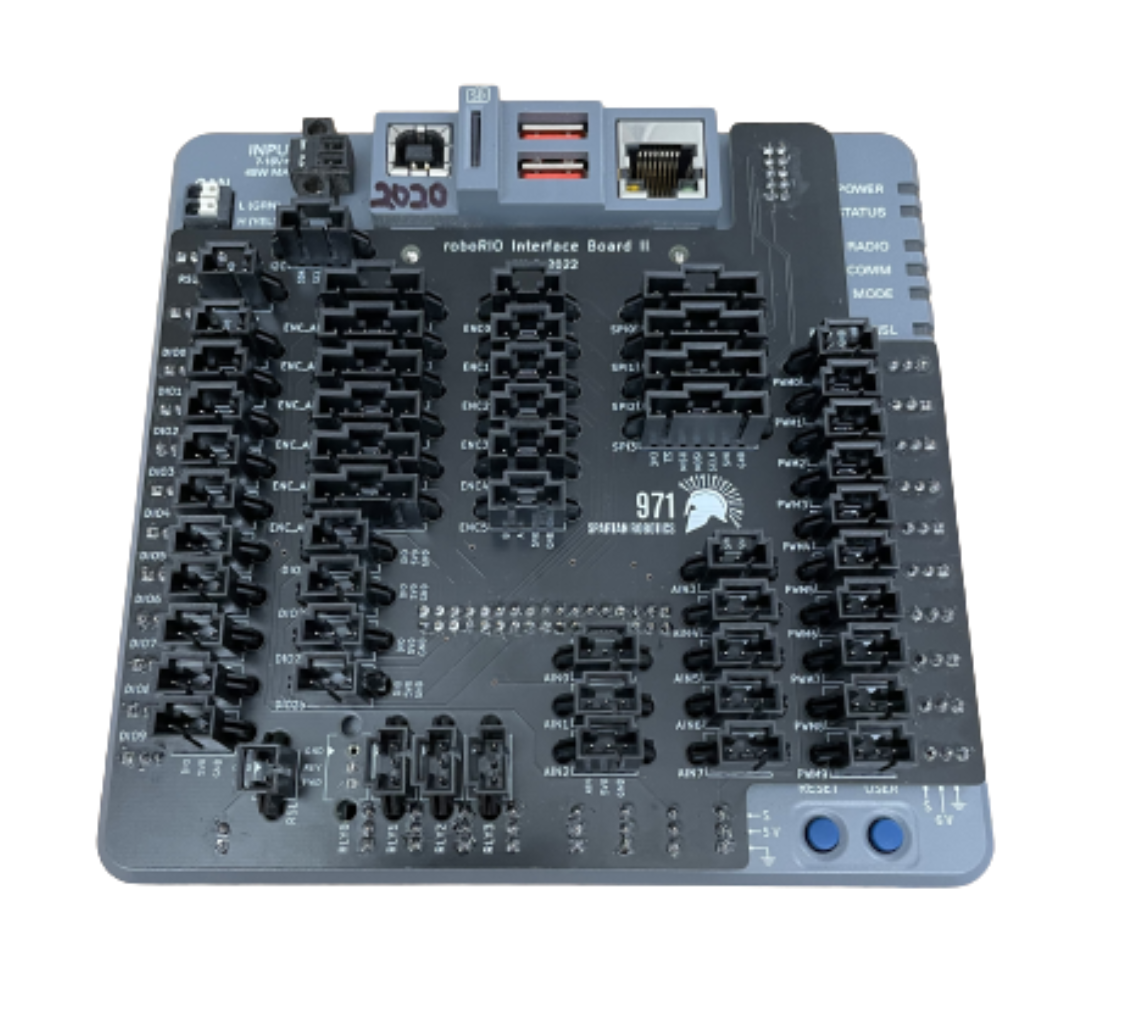
Main interface board for the RoboRIO control system.
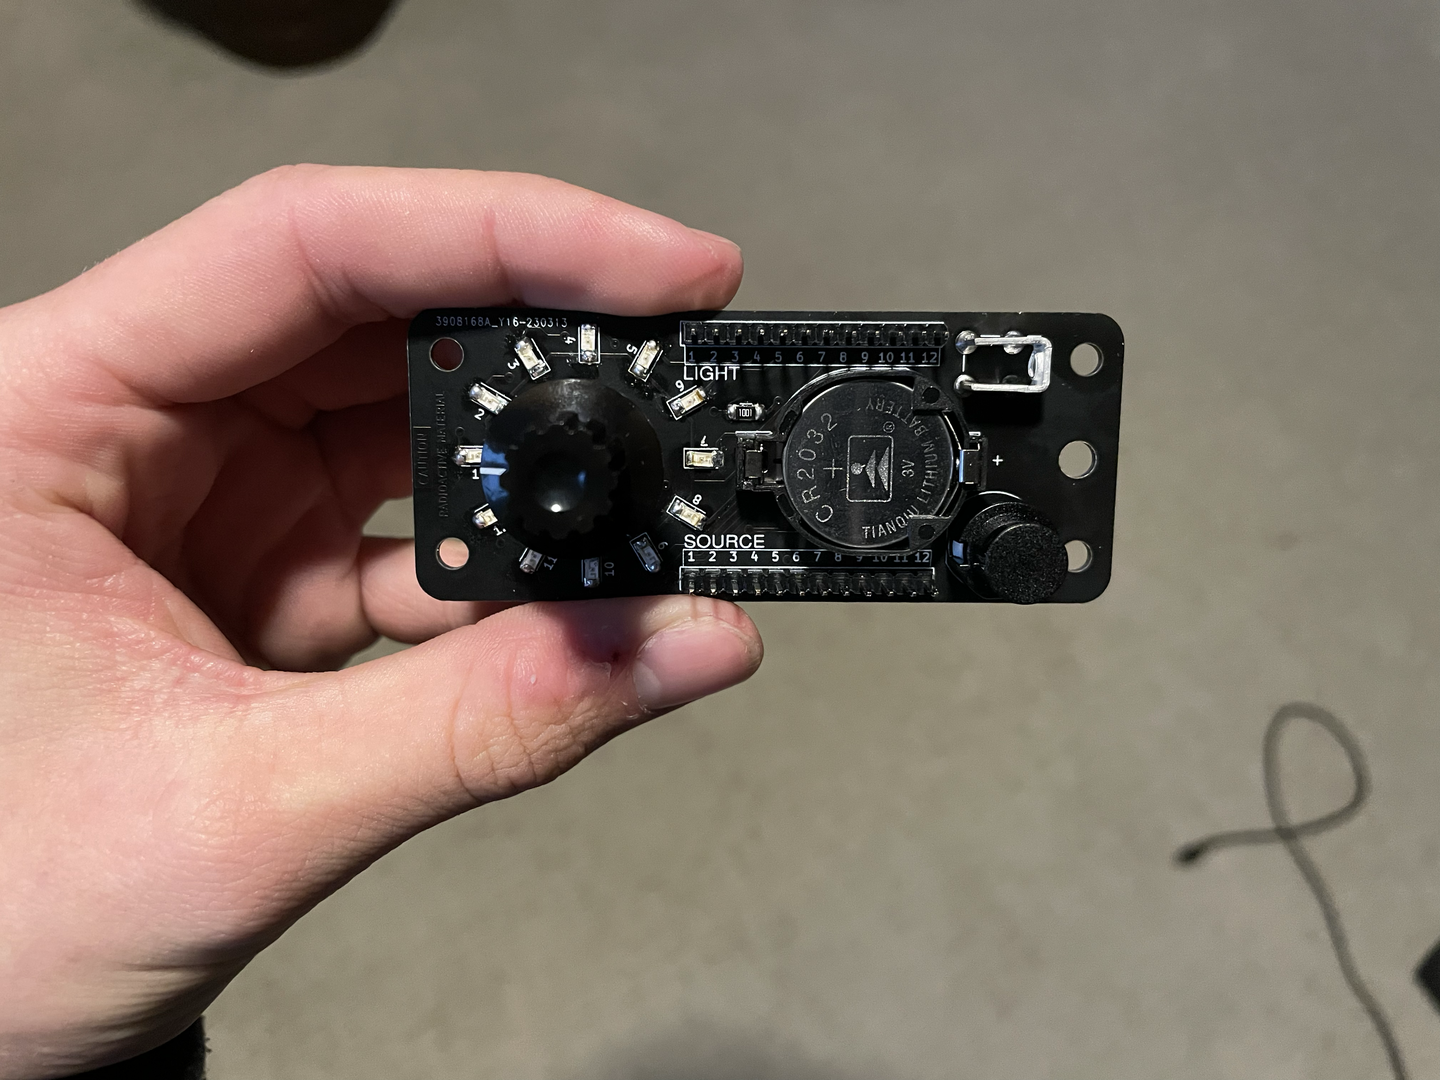
Custom wire tester for validating electrical connections.