6-DOF Robot Arm.
Custom-built 6-degree-of-freedom robot arm with inverse kinematics, path planning, and camera-based control.
The build
This is a current work-in-progress project. I'm experimenting with a lot of different ideas, but the first step was just building a robot to build on. I designed the arm in Onshape, then decided I wanted to write all of my own inverse kinematics from scratch instead of relying on black-box tooling.
I've been using the Placo library and messing around with different path-planning approaches to find valid, non-self-intersecting motions, basically making sure the robot doesn't hurt itself or smash into its own body. I've tried a mix of PRM, RRT, linear interpolation, and joint-space planning, and I'm still comparing how each one behaves in practice.
On top of that, I'm exploring different control ideas using cameras, depth cameras, and wrist-mounted IMUs to make arm control more intuitive and to collect better data from human motion. All of this is very much a work in progress, and I'll keep updating this page as things evolve.
I've been working on this for a bit now and I've learned a ton about robotic control. It's been a genuinely fun project, especially the part where you finally plug it in and it immediately tomahawks across the desk, smashes your computer, and breaks something. That part's definitely my favorite.
P.S The videos are the coolest part!
Evidence
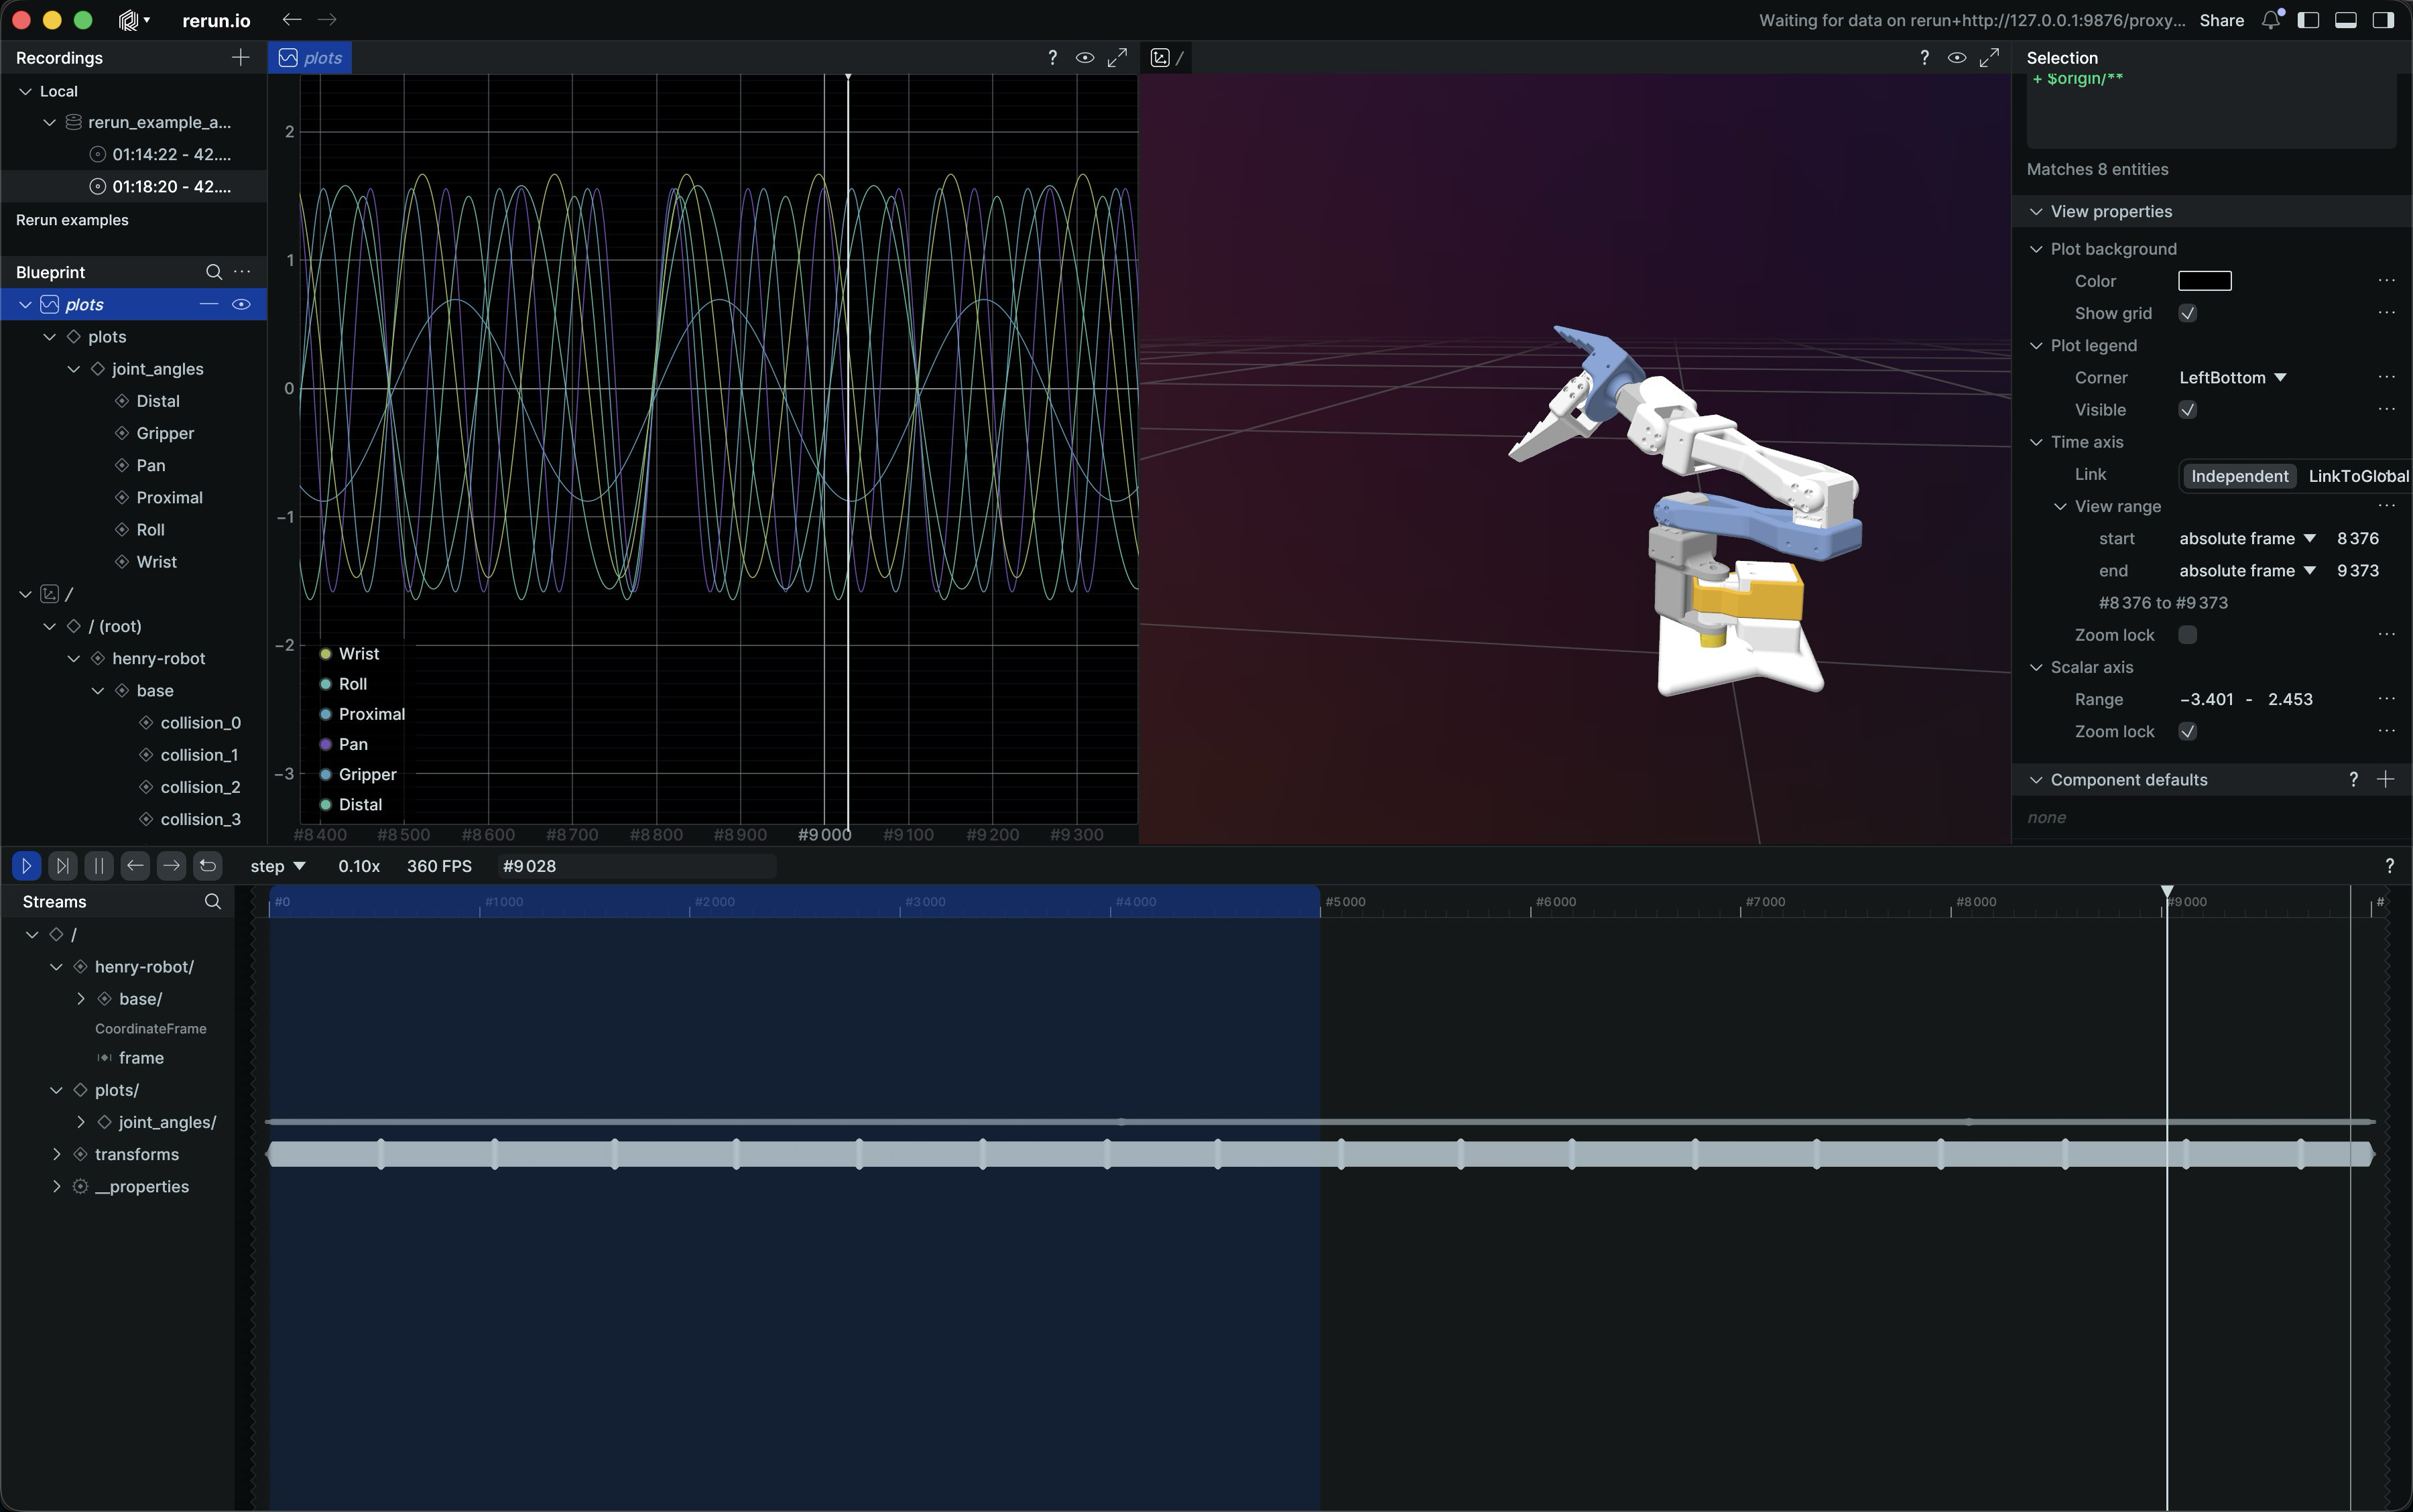
Real-time visualization in Rerun showing the robot arm's joint positions, movement trajectories, and control plots during live operation.
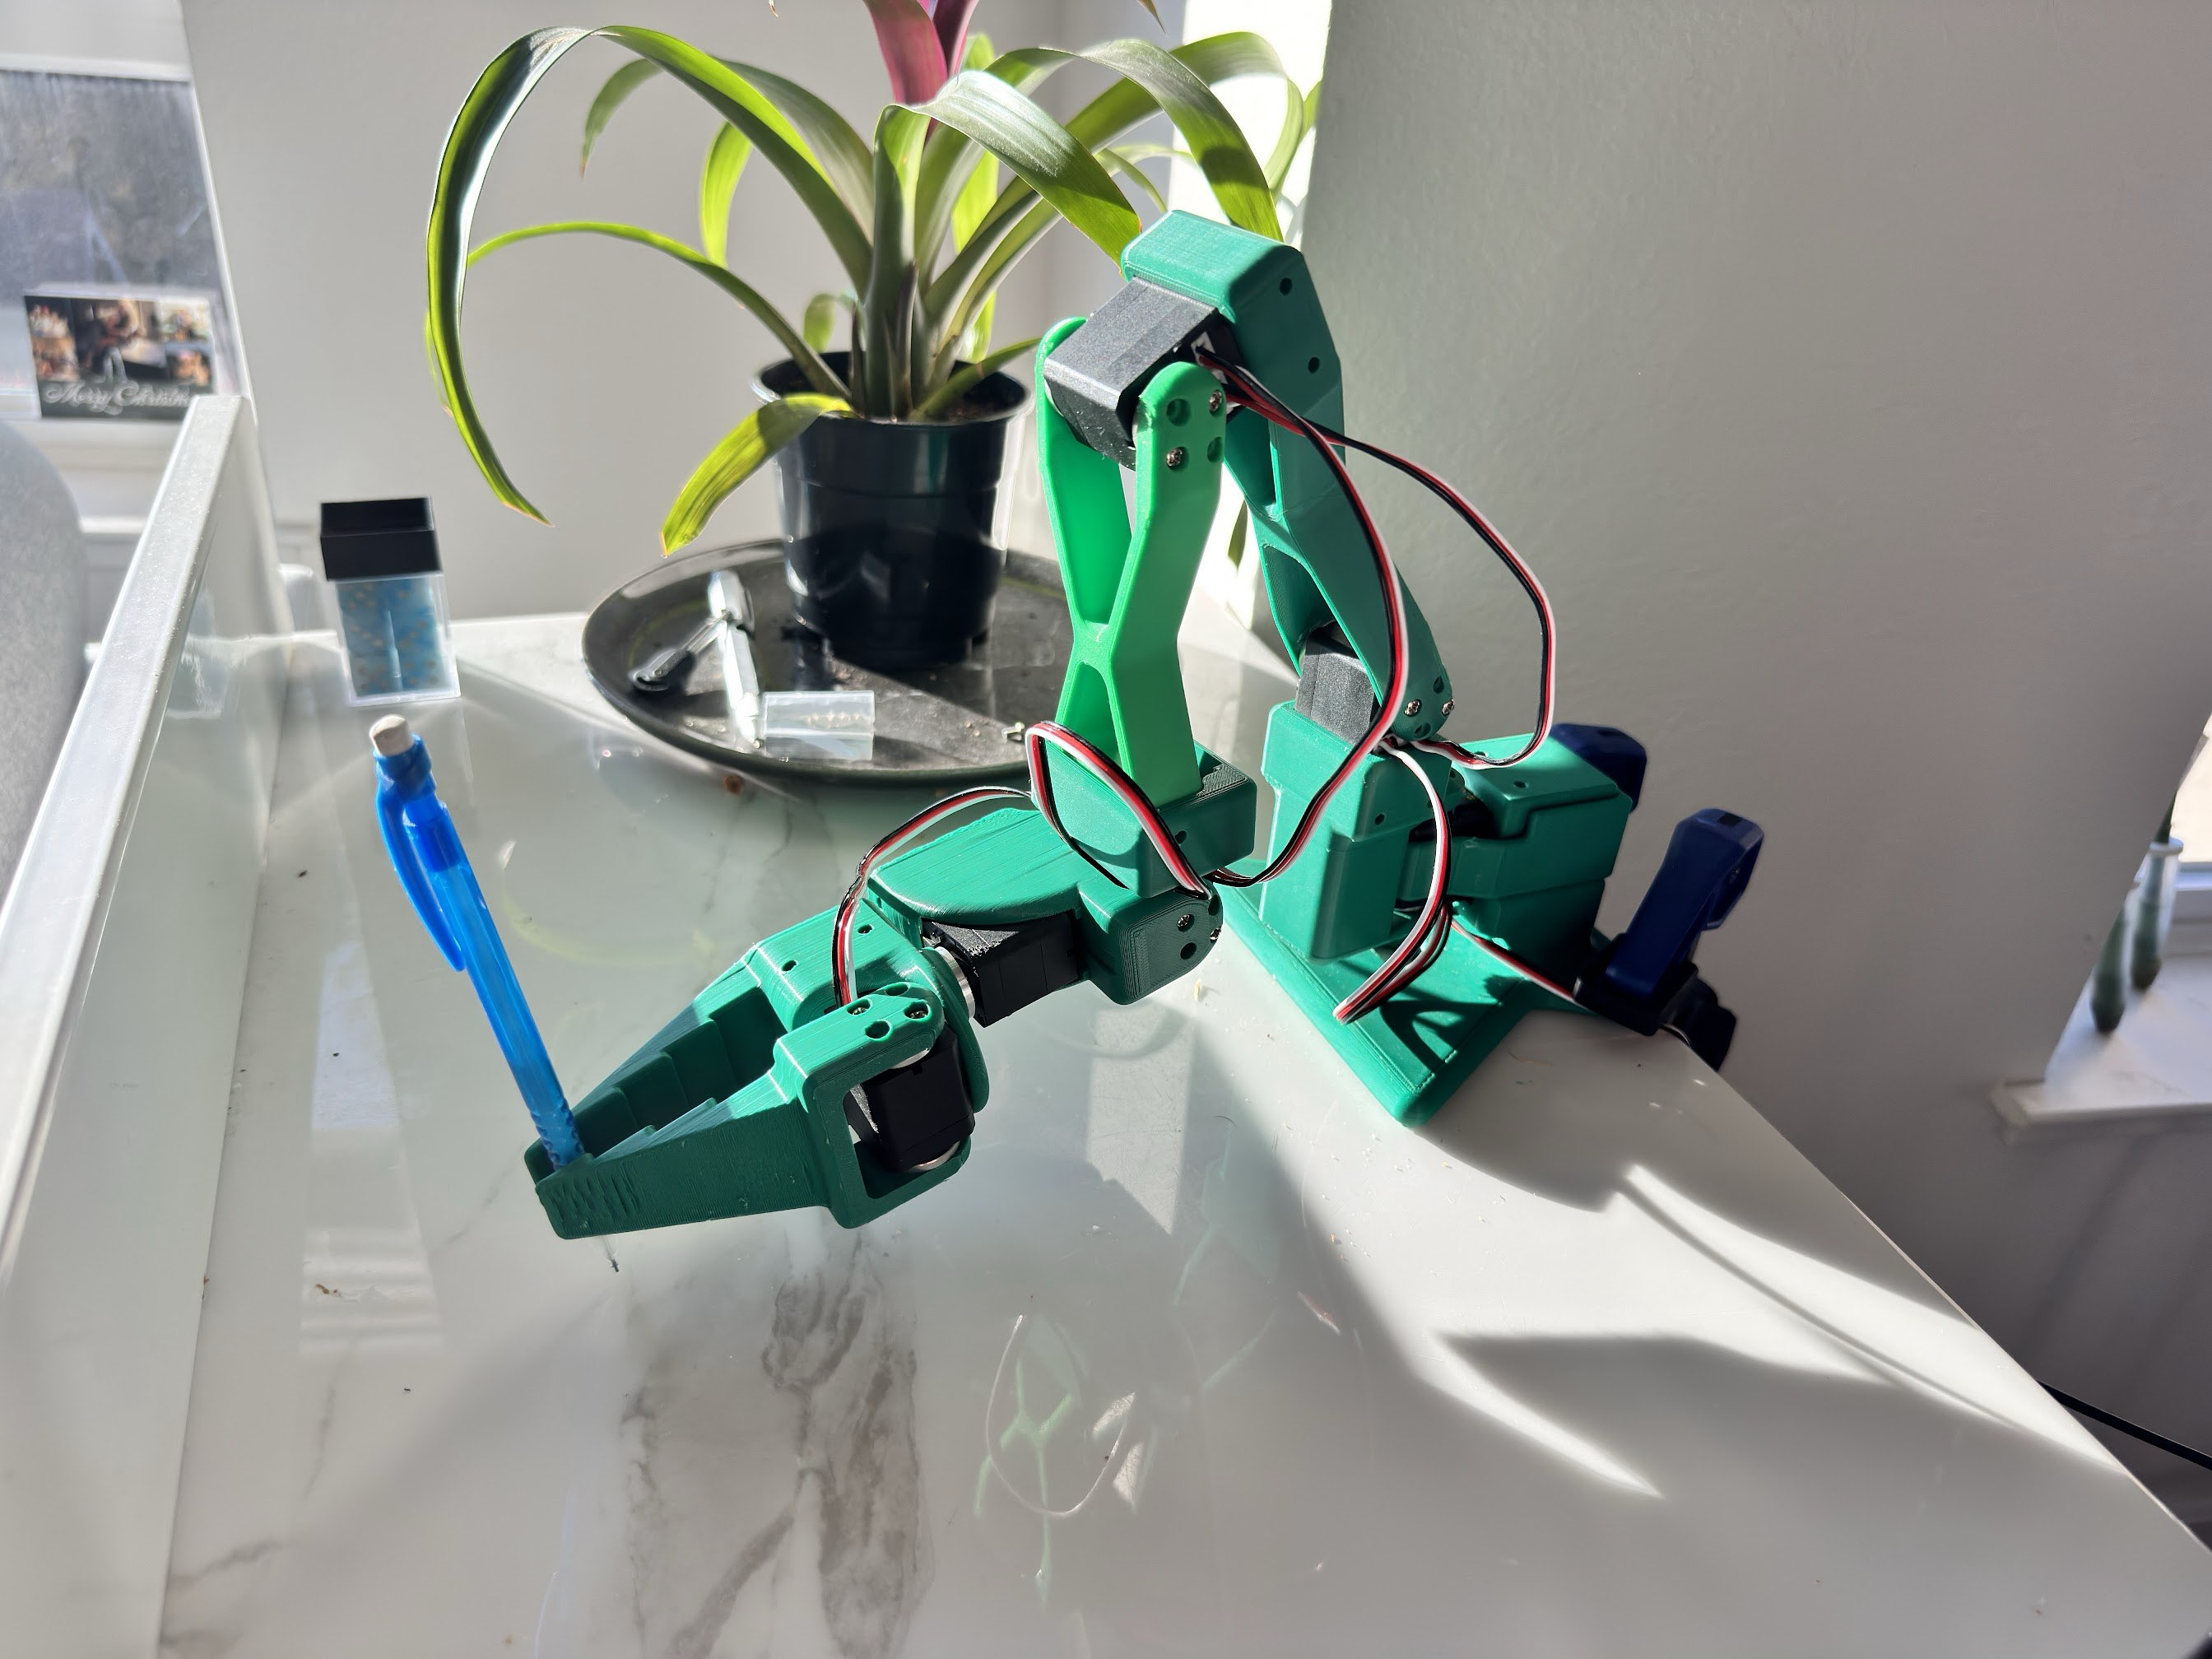
Fully assembled 6-DOF robot arm holding a pen, demonstrating precision control and end-effector positioning accuracy.
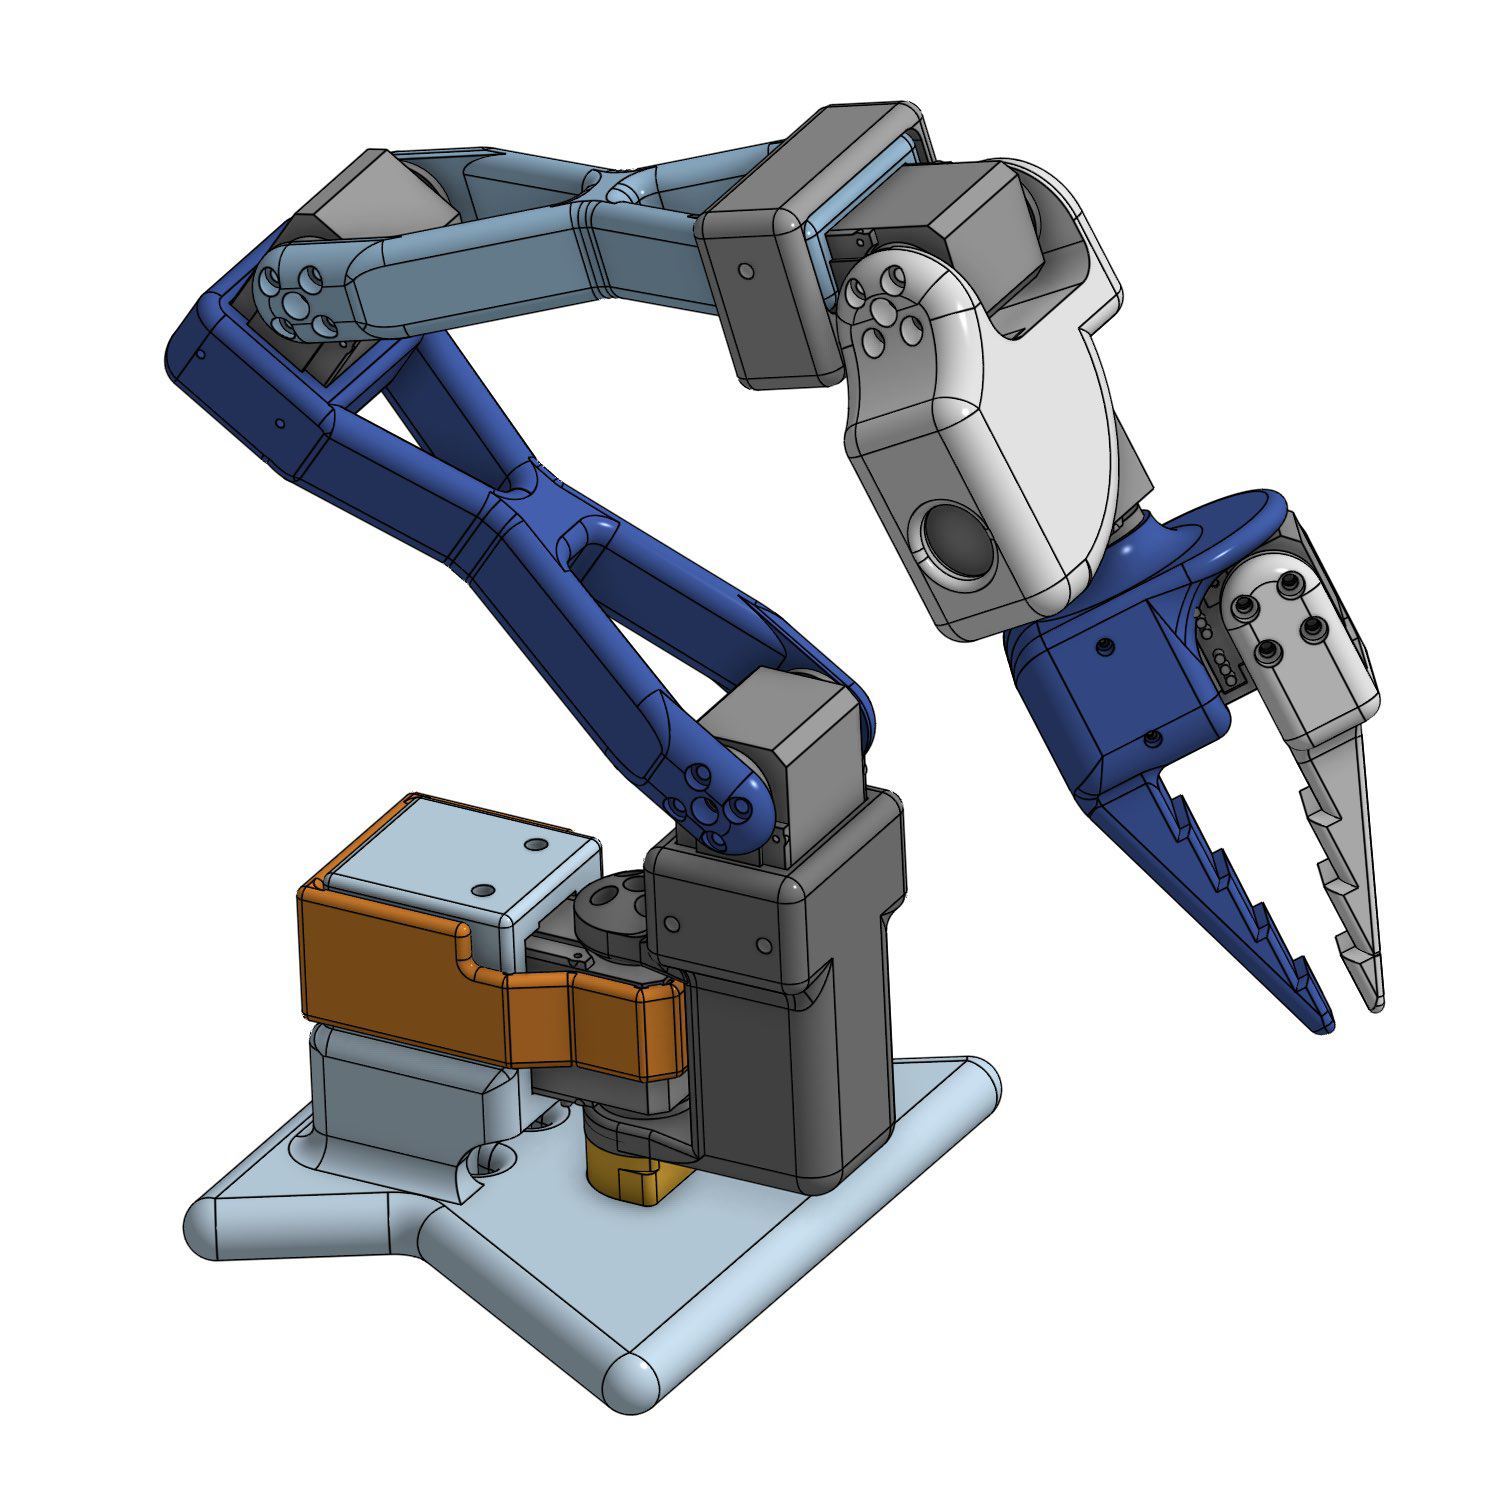
Complete CAD model designed in Onshape showing all mechanical components, joint assemblies, and structural elements.
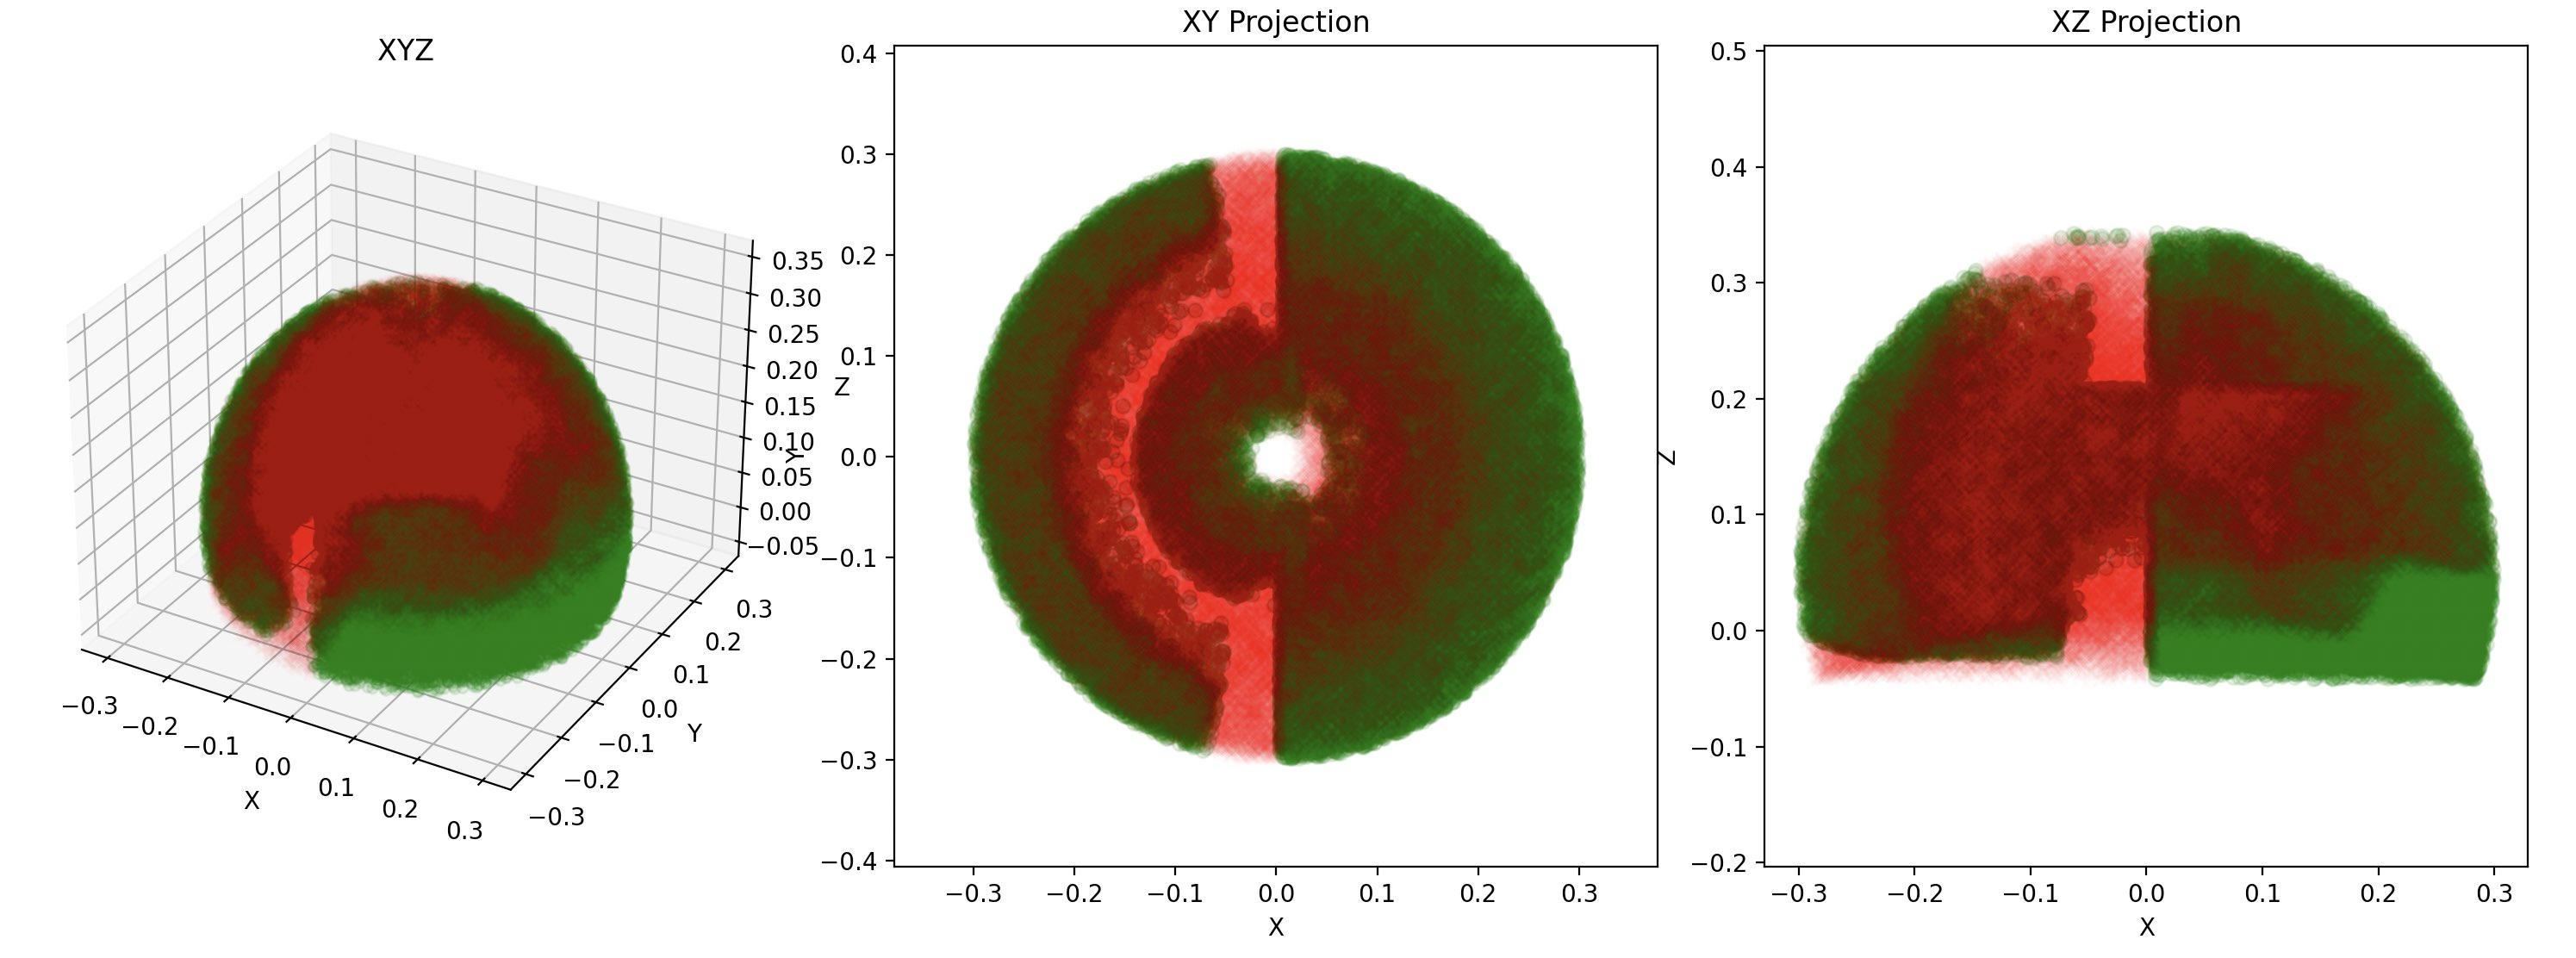
3D visualization mapping the complete workspace volume and all possible end-effector positions the robot can reach.

MediaPipe integration showing live hand tracking converted to joint positions for intuitive human-guided robot control.
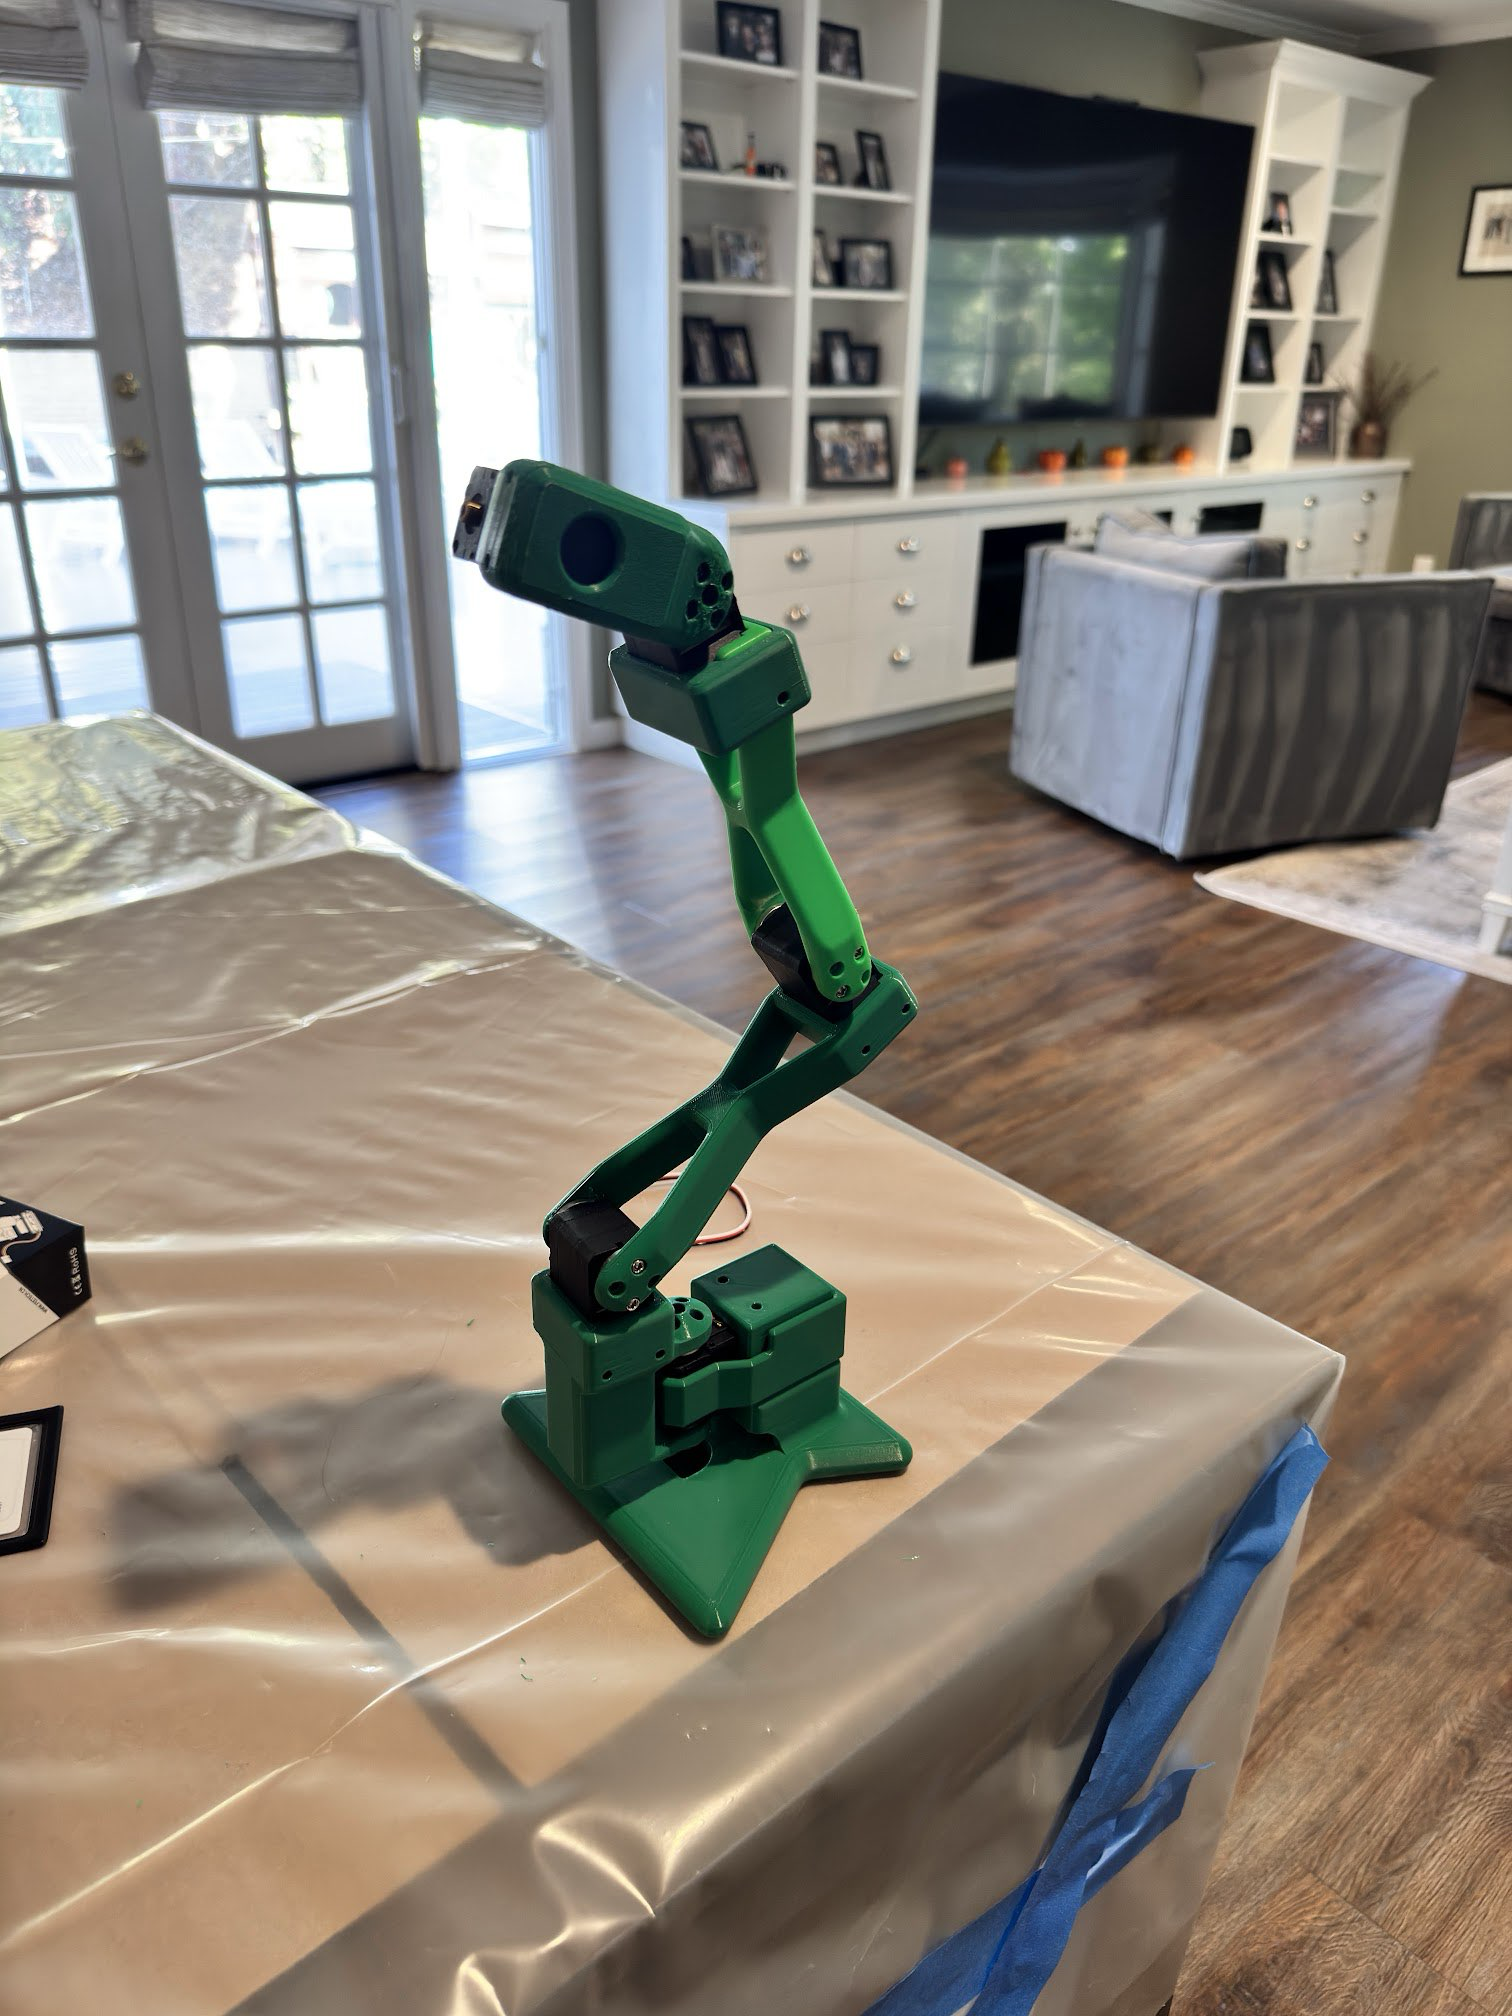
Near-complete mechanical assembly showing the robot structure without the final wrist roll joint and gripper attachment.
Detailed view of the bottom half assembly including the base, first joints, and primary structural components.
First version of the pan assembly showing the initial rotating base mechanism design and implementation.
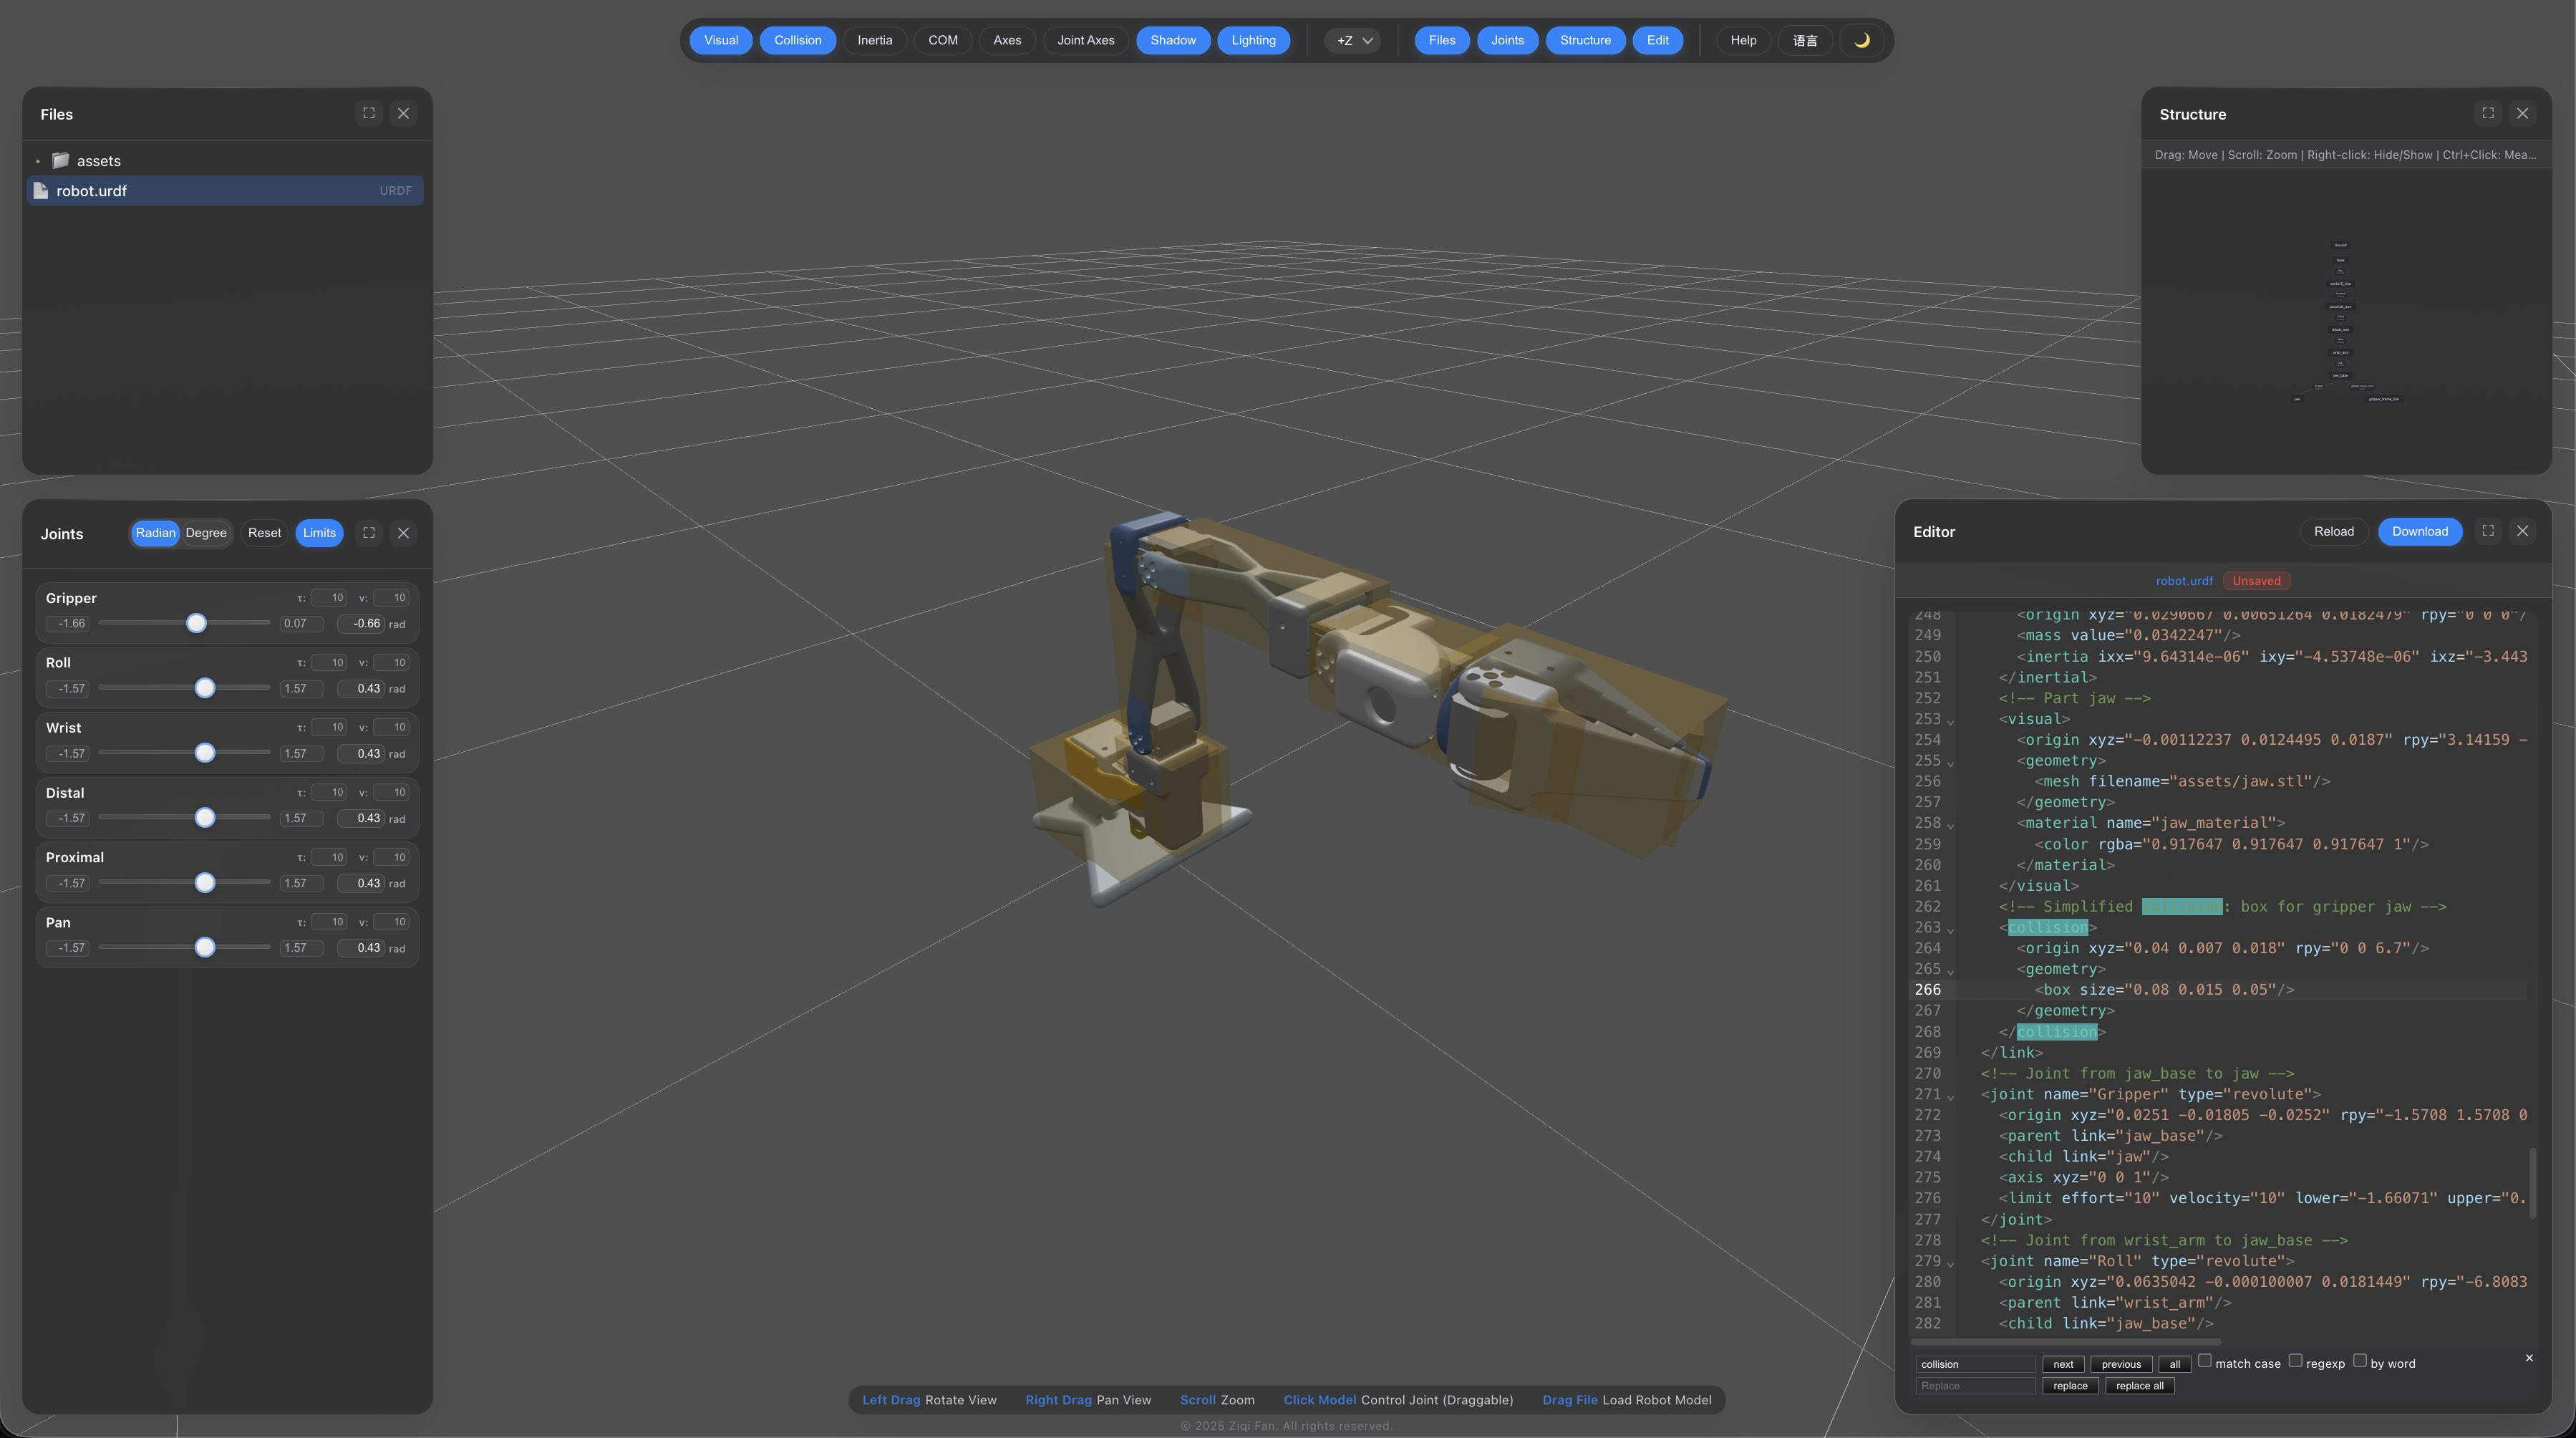
Collision bounding box visualization used for self-intersection detection and safety during path planning operations.